All Projects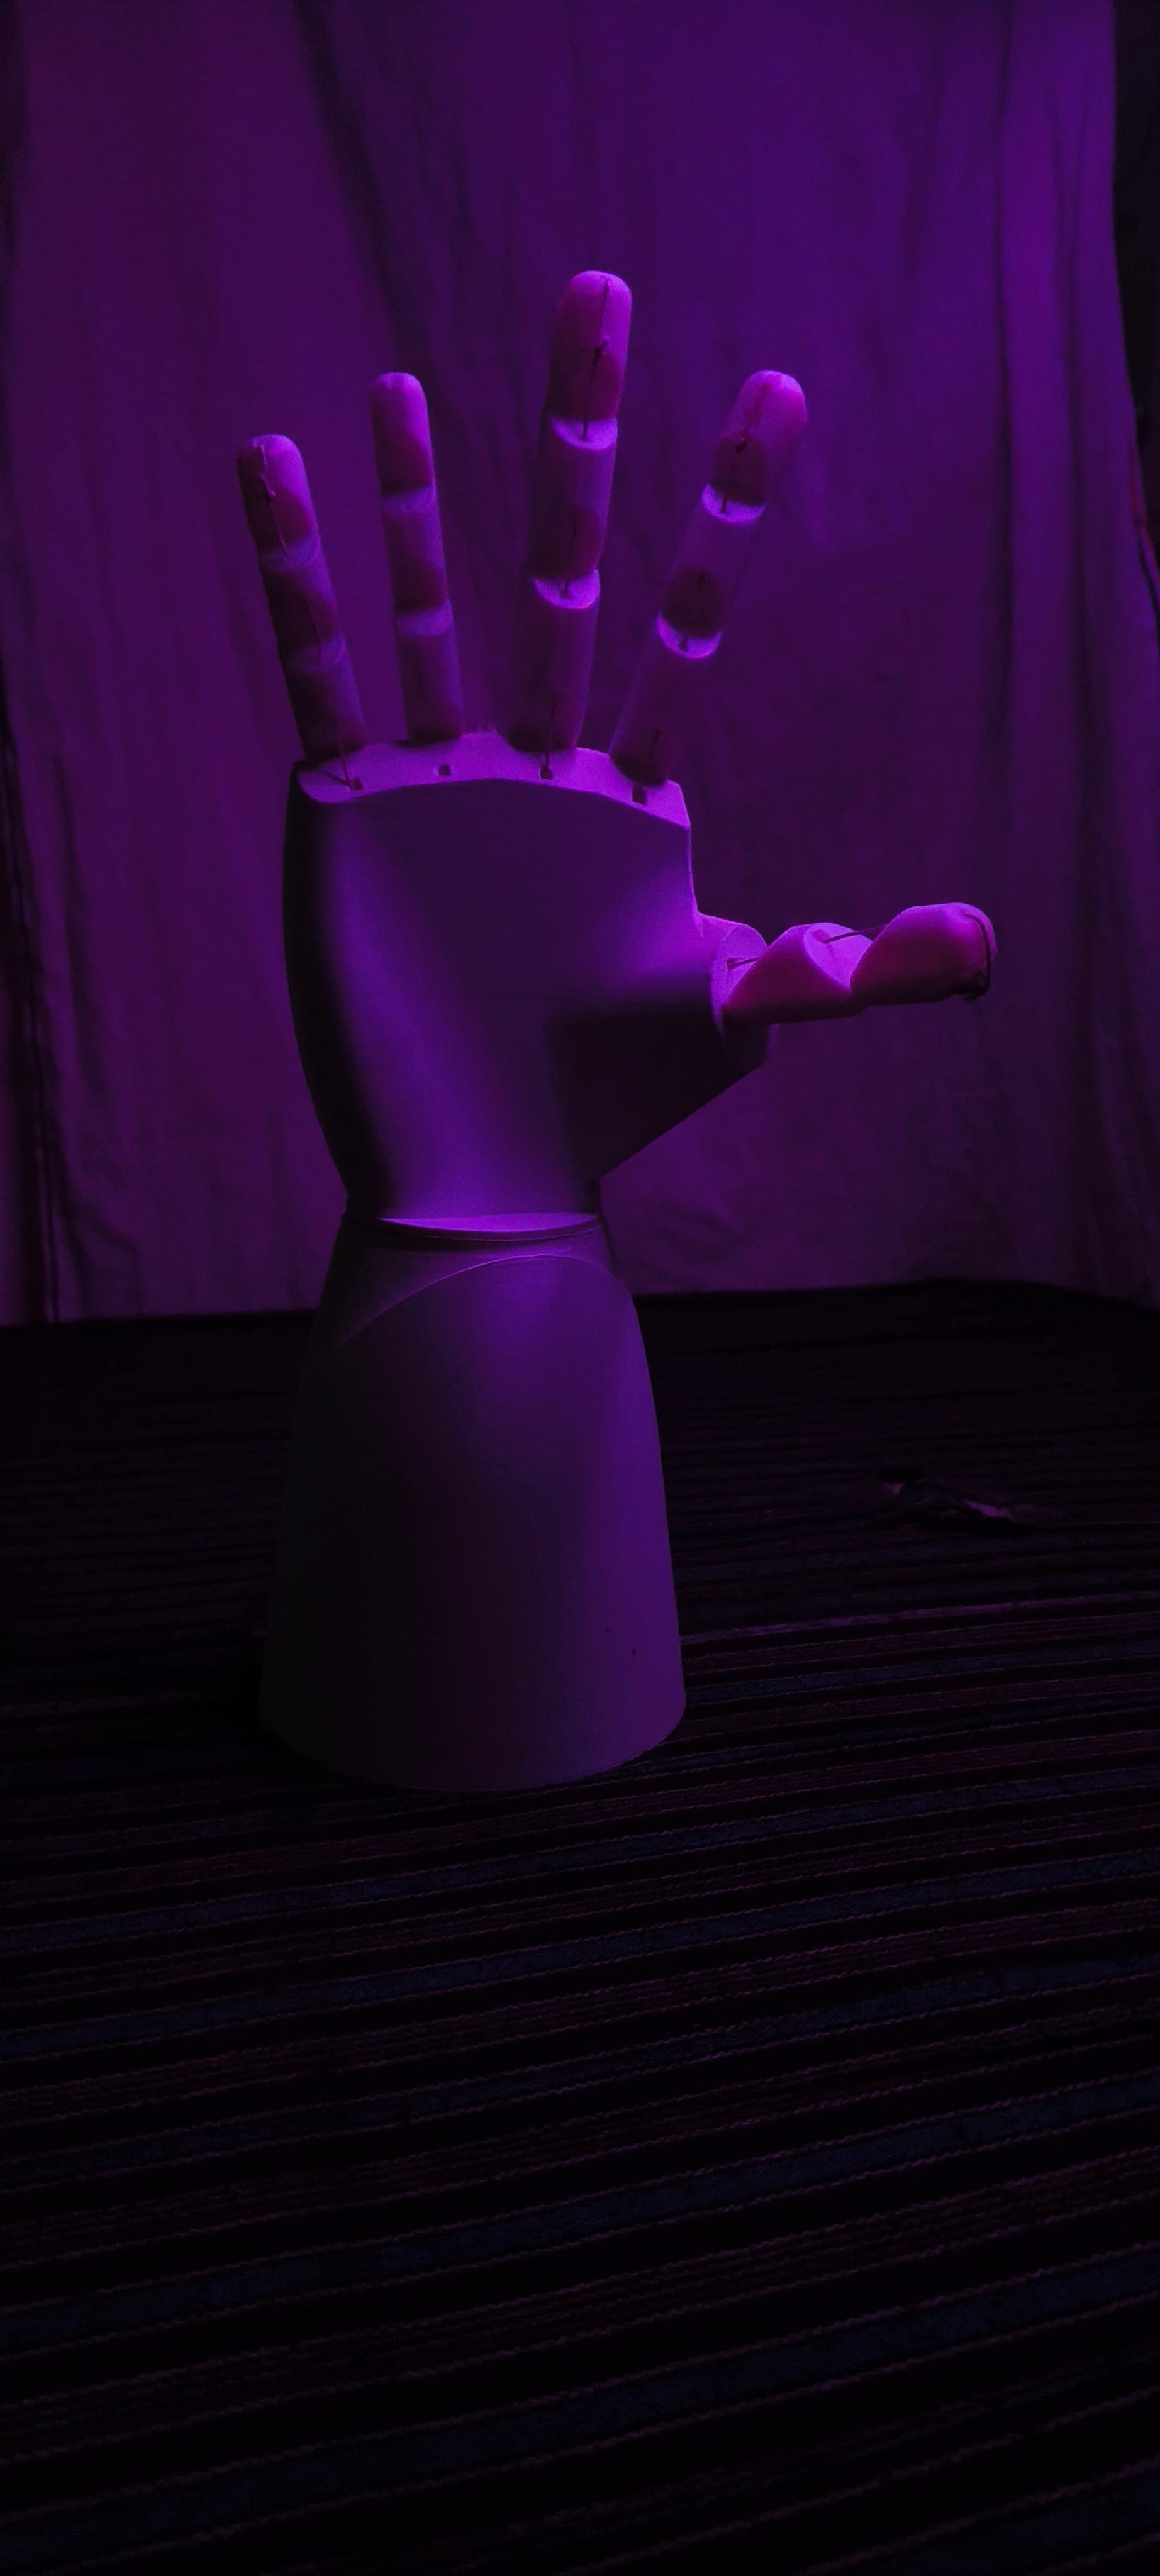
Bionic RoboticsYear 2026
Articulated Bionic Robotic Hand
A 5-finger bio-inspired articulated robotic hand driven by tendon cable lines and micro servos for dexterous grasping and tactile sensor experimentation.
Bionic RoboticsTendon MechanicsServo Control3D Printing
5-finger tendon-driven prosthetic hand assembly
Overview
Featuring 5 independently articulated fingers controlled by high-tensile tendon lines and dedicated micro servos, this bionic hand mimics natural human hand kinematics. Integrated flex sensors allow the controller to execute delicate grasping routines.
Highlights
- 5-Finger independent tendon-driven articulation
- Bio-inspired flexible finger joint mechanics
- Haptic force & pressure sensor integration
- Palm-integrated compact servo actuator array
The Challenge
Eliminating tendon binding and friction during multi-finger flexion required designing custom 3D-printed internal cable guide channels.
The Outcome
Successfully grips complex objects from fragile items to soft spheres.
Project Media & Build Gallery
[6 PHOTOS]5-finger tendon-driven prosthetic hand assembly
More Projects
 Power Electronics
2026
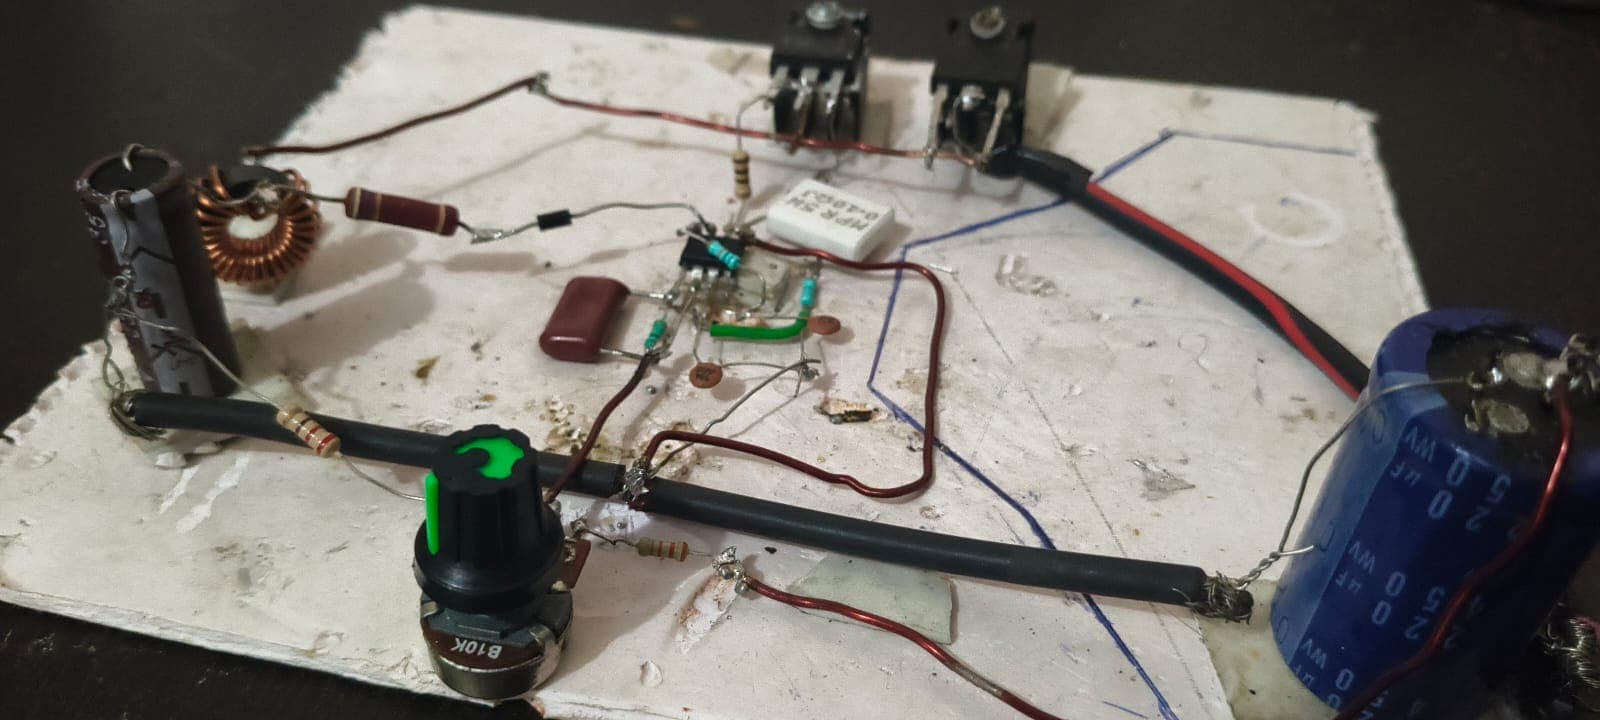
DC to DC Booster Converter
A high-efficiency DC-DC step-up boost converter engineered for stable voltage stepping, closed-loop PWM regulation, and reliable power delivery in mobile robotic systems.
Why we built this
Voltage sag and brownouts frequently reset student microcontrollers during heavy motor loads; we engineered an affordable, robust DC boost converter module.
Free technical report & Drive guide available
 Competitive Robotics
2026
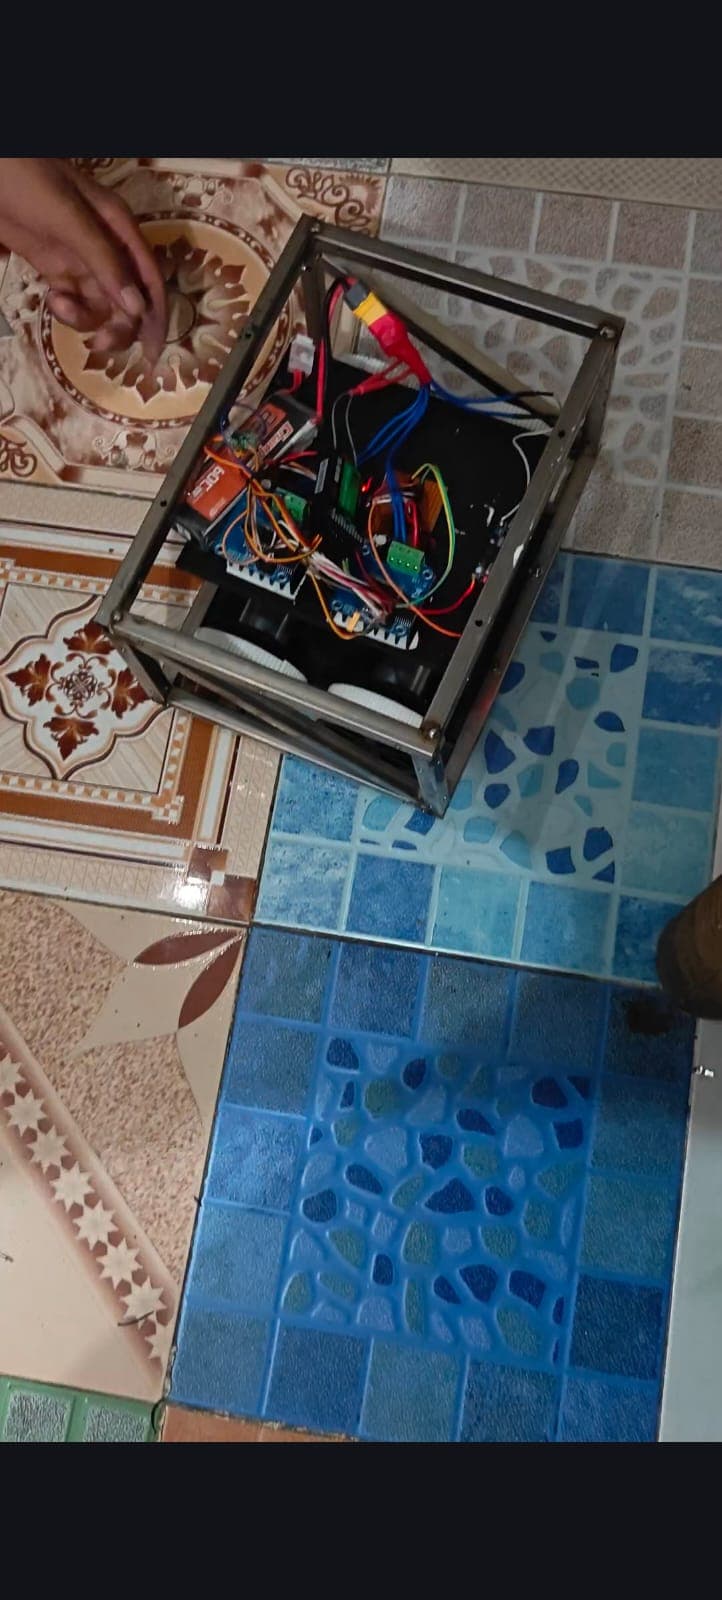
RoboSoccer Bot
A fast, agile wireless robot built for robot-soccer matches — designed to push, dribble, and score.
Why we built this
Competition robots often cost thousands — we designed this bot with common parts so any student club can afford to compete.
Free technical report & Drive guide available
 Legged Robotics
2026
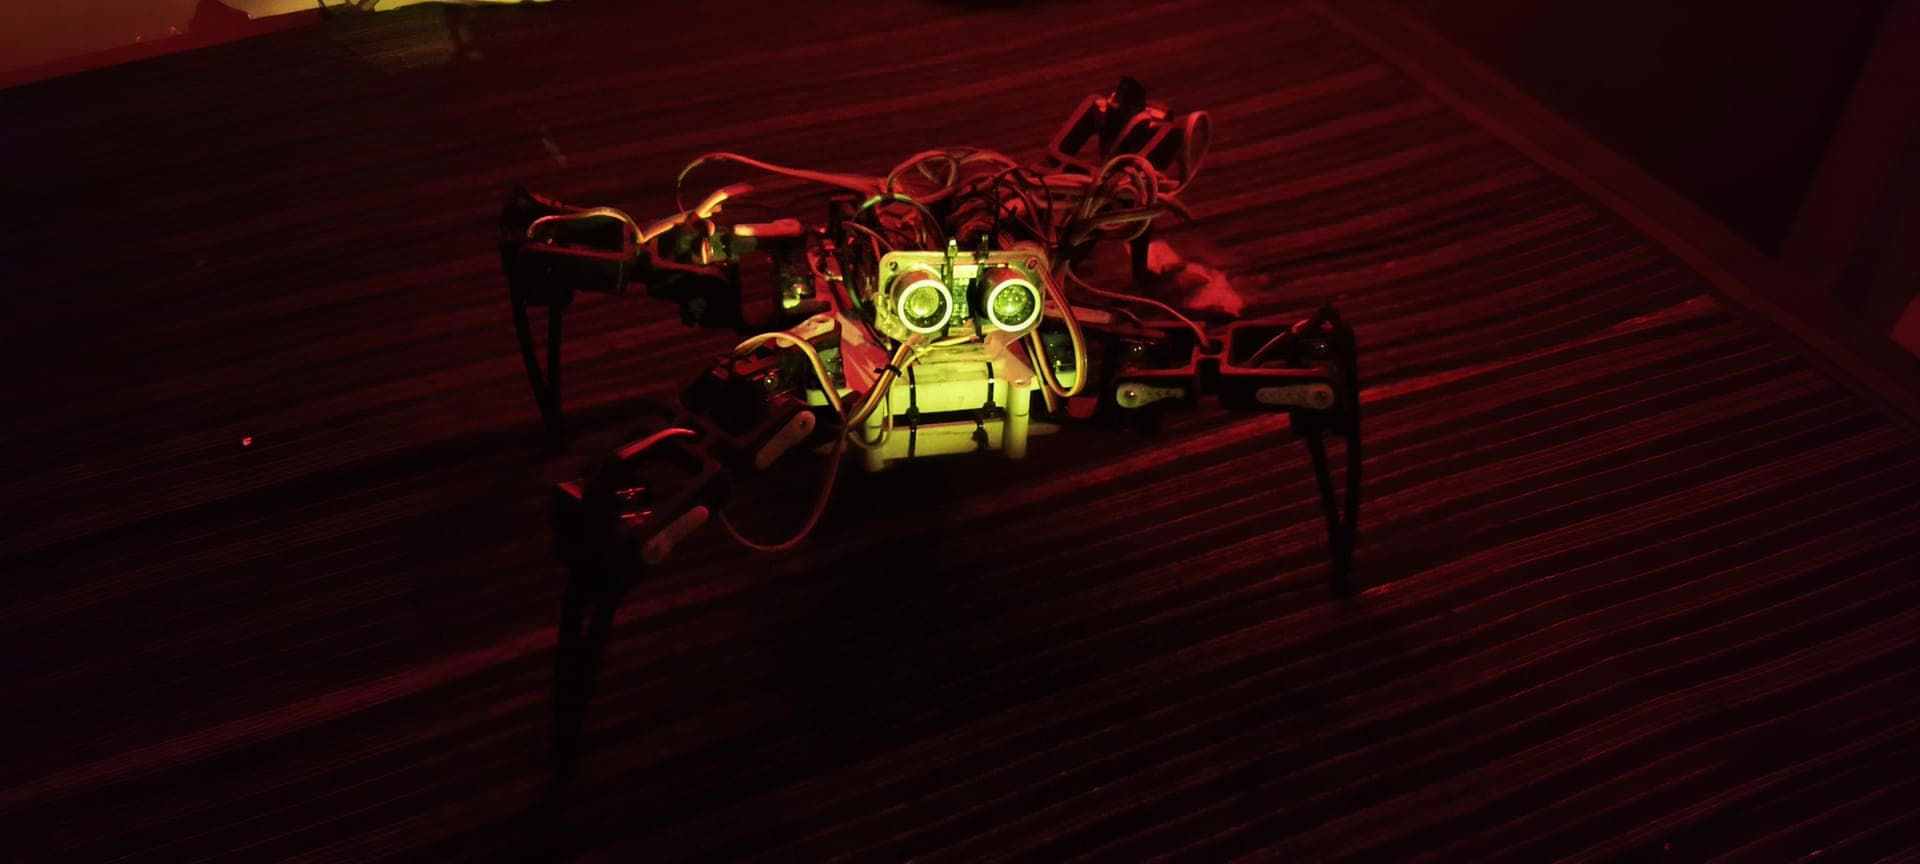
Hexapod Spider Robot
A hexapod-style walking robot with articulated legs that crawls, turns, and adapts its gait over uneven ground.
Why we built this
We built this with low-cost 3D-printed parts and affordable servos so local schools could replicate multi-legged robotics without expensive machinery.
Free technical report & Drive guide available