All Projects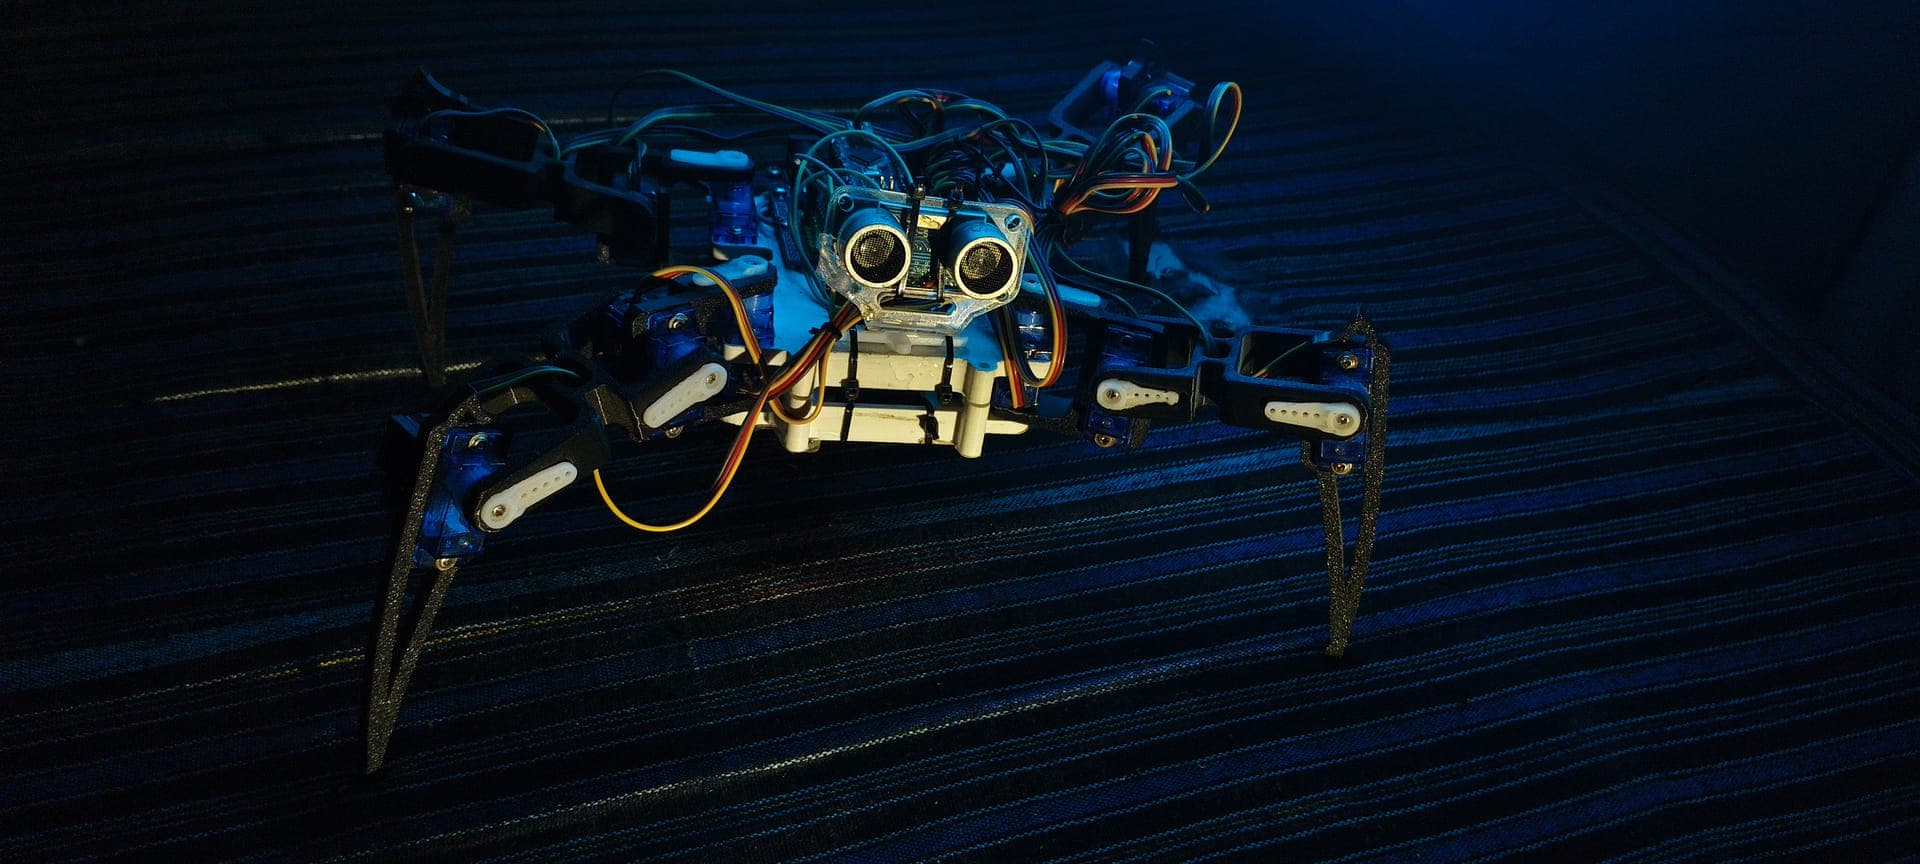
Legged RoboticsYear 2026
Hexapod Spider Robot
A hexapod-style walking robot with articulated legs that crawls, turns, and adapts its gait over uneven ground.
ArduinoServo ControlInverse Kinematics3D Printing
12-DOF hexapod spider robot 3D printed frame
Overview
Our spider robot uses multiple servo-driven legs coordinated by an inverse-kinematics gait engine. Each leg has multiple degrees of freedom, letting the robot walk, strafe, and rotate in place.
Highlights
- Multi-legged gait with coordinated servo control
- Walks, turns, and strafes in any direction
- Wireless control from a custom remote
- Fully 3D-printed, student-designed chassis
The Challenge
Synchronising many servos into a smooth, stable gait without the robot toppling took careful timing and leg-sequence tuning.
The Outcome
The finished spider walks reliably across flat and mildly uneven surfaces and is a crowd favourite at demos.
Project Media & Build Gallery
[4 PHOTOS]12-DOF hexapod spider robot 3D printed frame
More Projects
 Aerial Robotics
2026
RC Plane
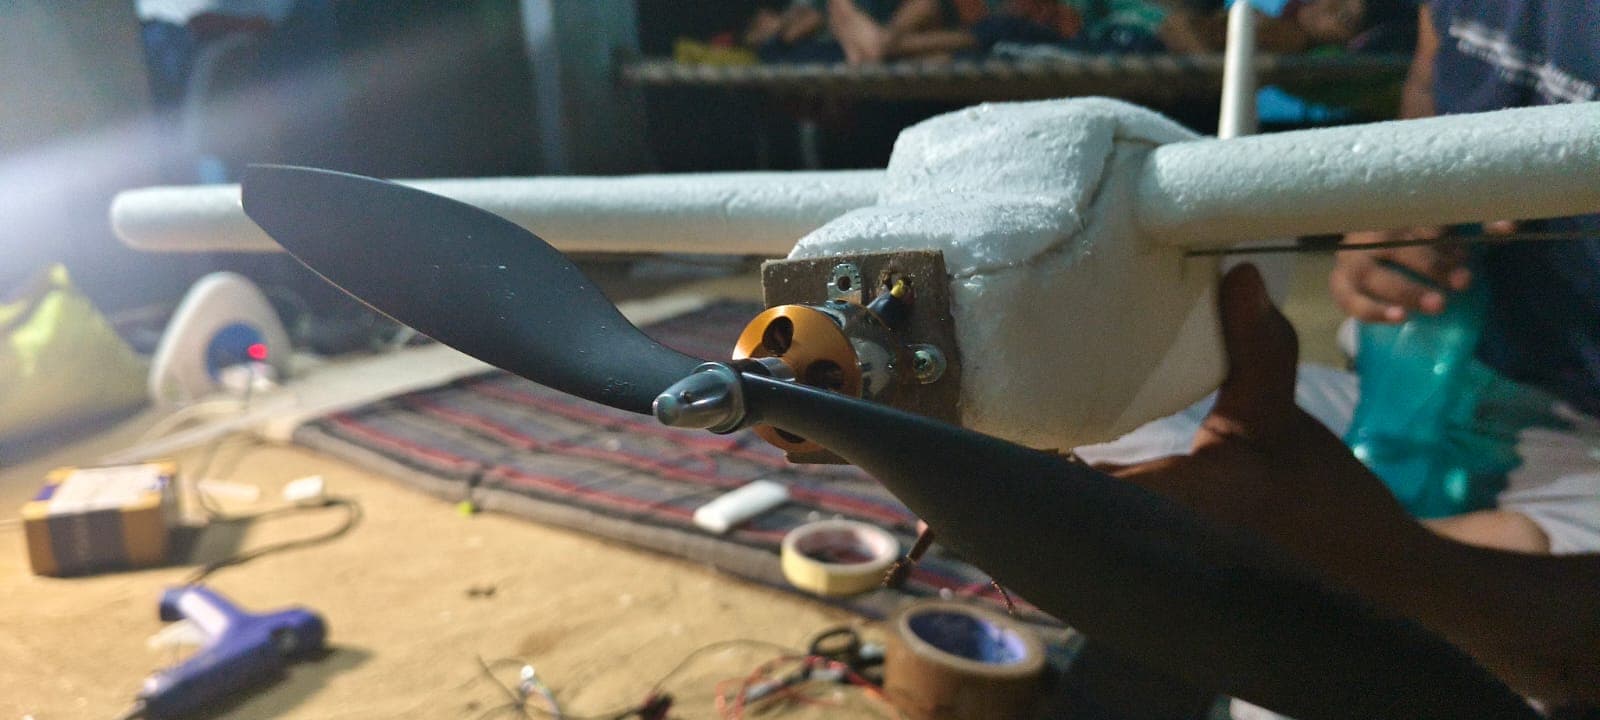
A hand-built fixed-wing RC aircraft designed, balanced, and flown by the team.
Why we built this
Aeromodelling kits are expensive; we used foam board and locally sourced motors so flight becomes accessible to every curious student.
Free technical report & Drive guide available
 Electronics
2026
Tesla Coil
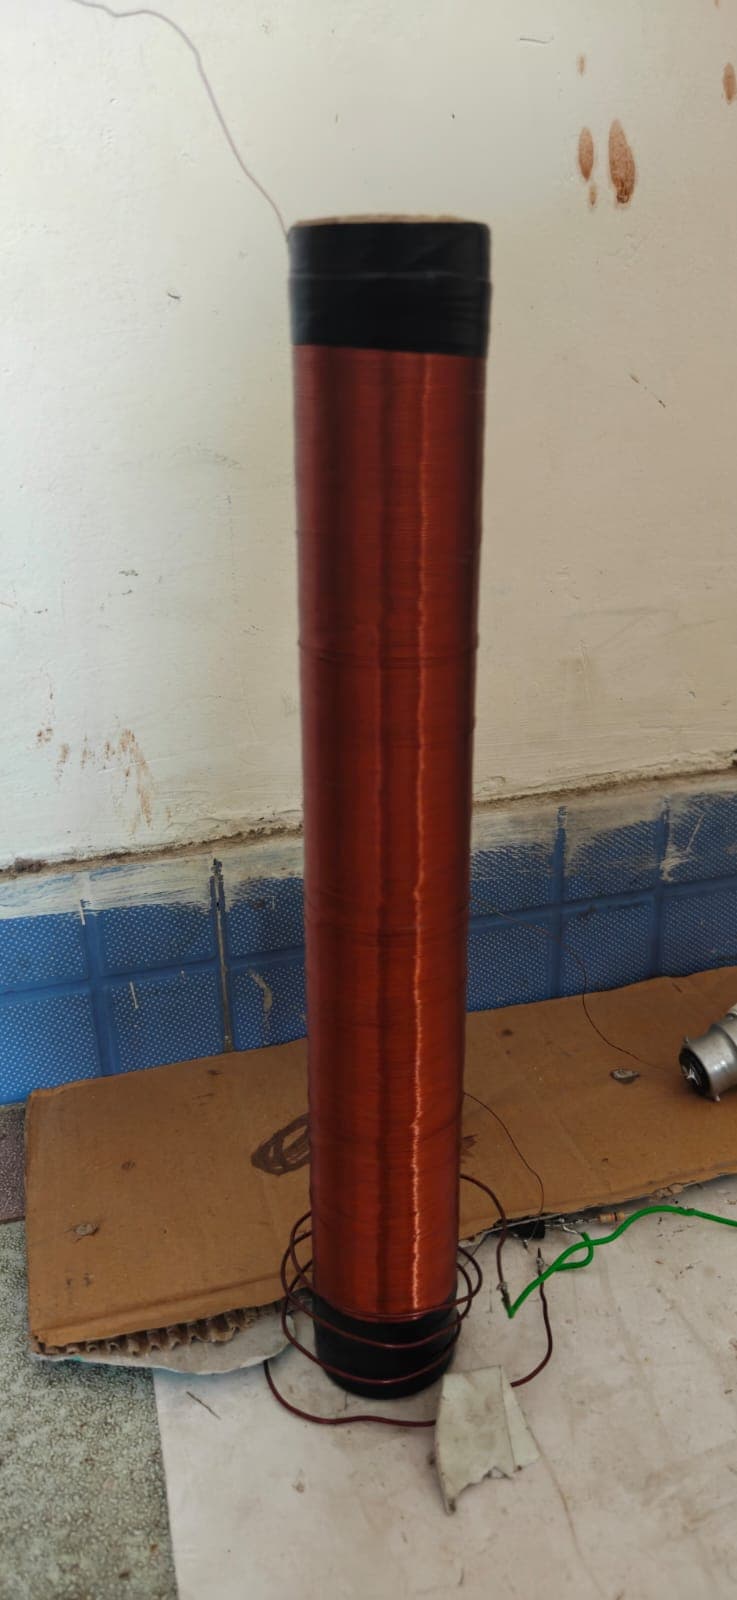
A slayer-exciter Tesla coil that produces visible high-voltage arcs and wirelessly lights bulbs.
Why we built this
High-voltage demos inspire curiosity; we designed ours with safety cut-offs so we can bring electromagnetism to any classroom.
Free technical report & Drive guide available
 Autonomous Systems
2026
Object Collision-Avoiding Robot
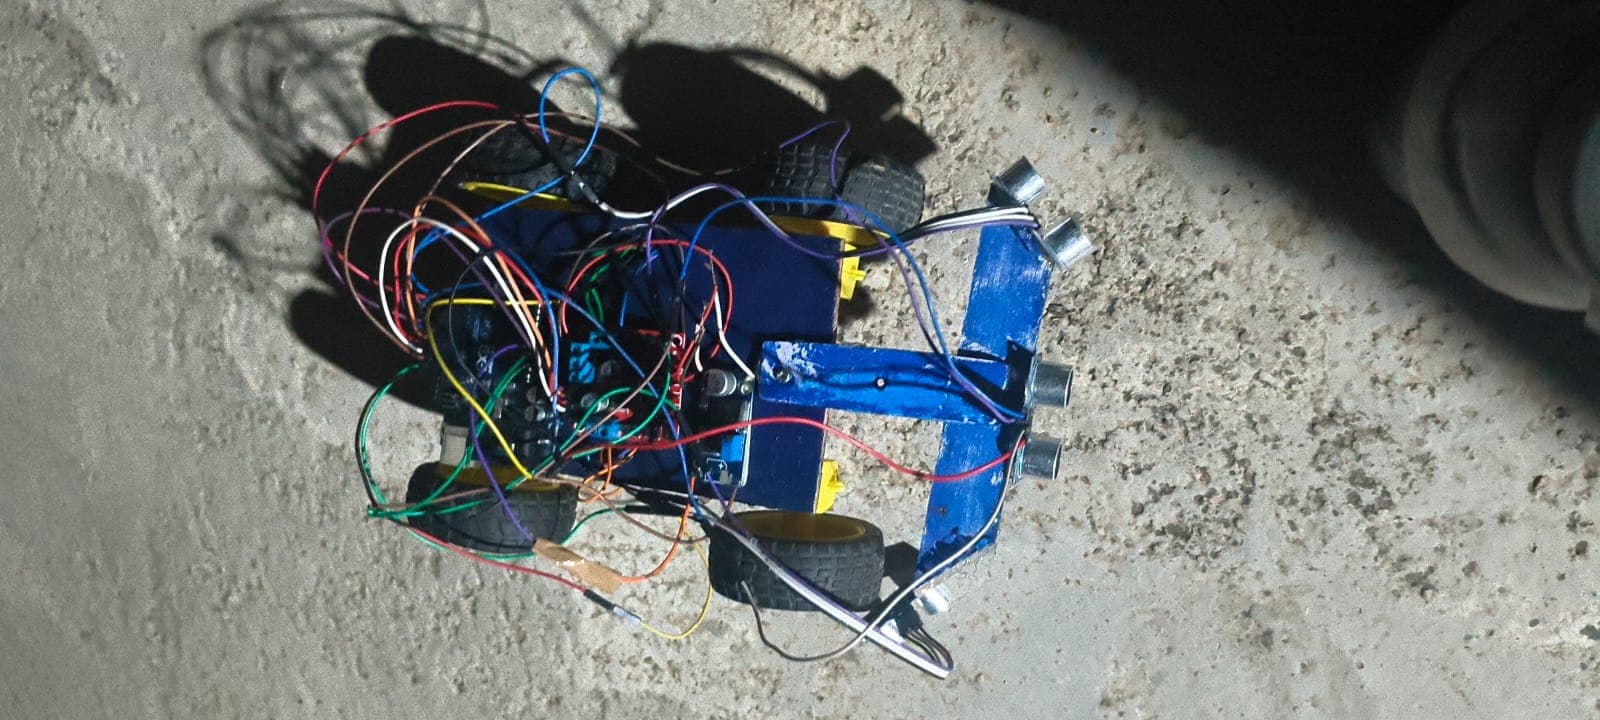
An autonomous rover that sweeps an ultrasonic sensor to detect obstacles and steer around them.
Why we built this
Autonomy made simple: our clean, commented code lets beginners understand every line and extend the robot themselves.
Free technical report & Drive guide available