All Projects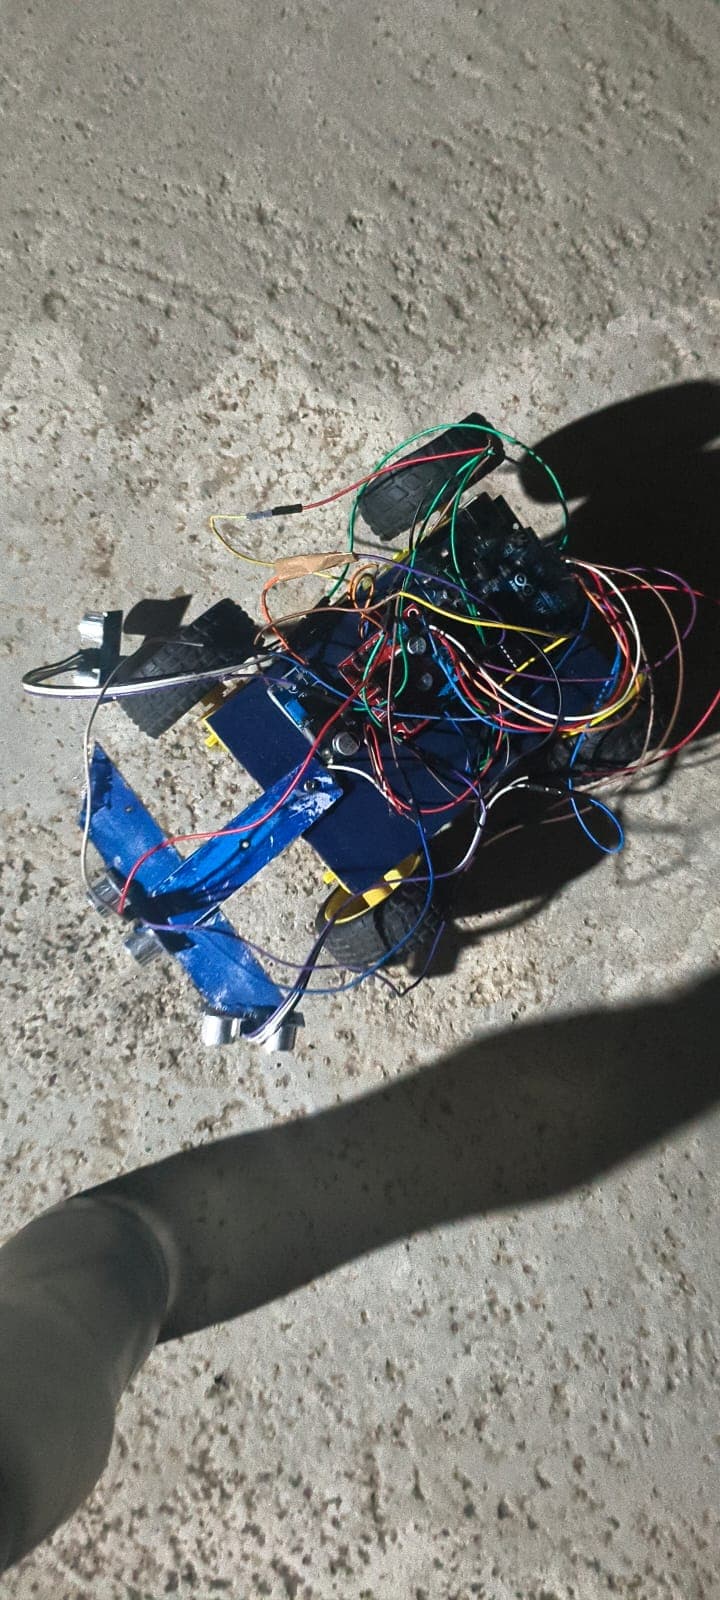
Autonomous SystemsYear 2026
Object Collision-Avoiding Robot
An autonomous rover that sweeps an ultrasonic sensor to detect obstacles and steer around them.
ArduinoC++UltrasonicRobotics
Ultrasonic sensor on servo scanning forward
Overview
A teaching platform for autonomy, this rover sweeps a servo-mounted ultrasonic sensor, measures clearances, and picks the freest heading to avoid collisions.
Highlights
- Servo-swept ultrasonic scanning
- Clear, beginner-friendly state machine
- All-terrain four-wheel drive
- Modular, hackable codebase
The Challenge
Keeping the logic simple for beginners while staying robust meant a clean, well-commented control loop.
The Outcome
Navigates cluttered spaces without collisions and is a core kit in our intro workshops.
Project Media & Build Gallery
[3 PHOTOS]Ultrasonic sensor on servo scanning forward
More Projects
 Control Systems
2026
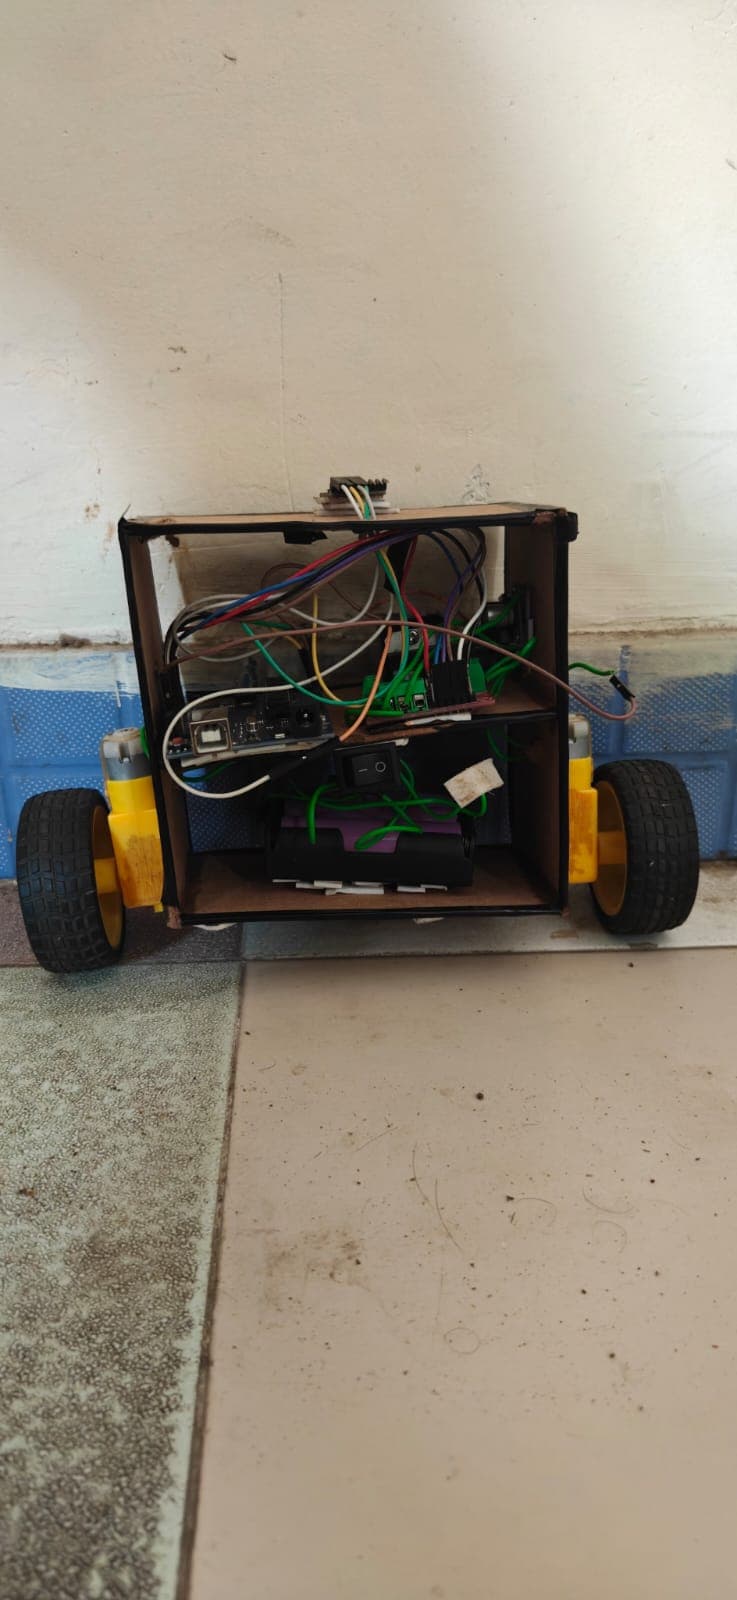
Self-Balancing Robot
A two-wheeled robot that stays upright in real time using an IMU and a PID balance controller.
Why we built this
Control theory on a budget — we're building this so students can experiment with PID tuning without industrial equipment.
Free technical report & Drive guide available
 Aerospace
2026
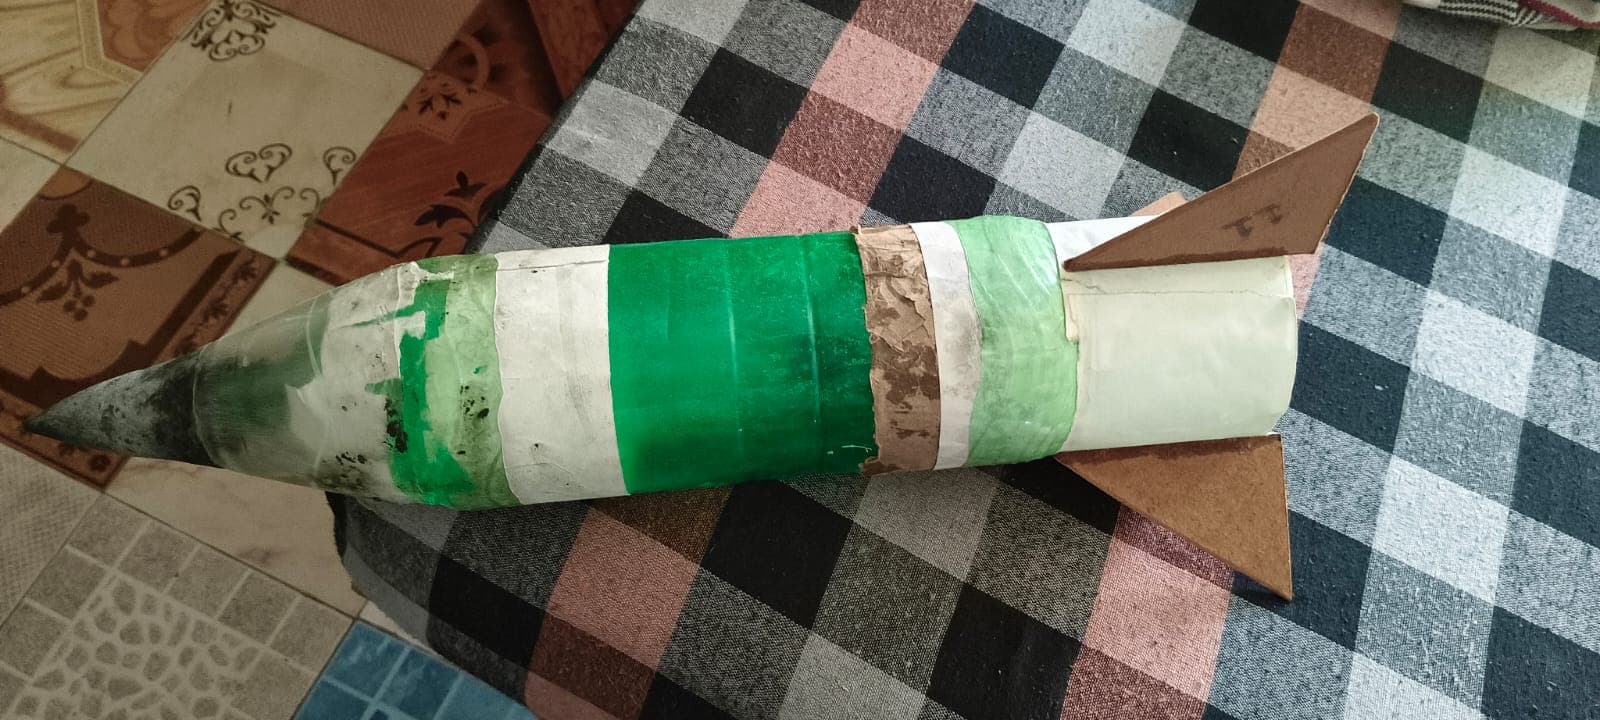
Water Rocket
A pressurised water-and-air rocket engineered for maximum altitude and a clean recovery.
Why we built this
A zero-cost intro to physics and engineering using recycled bottles — perfect for school outreach demos where budgets are tight.
Free technical report & Drive guide available
 Autonomous Systems
2026
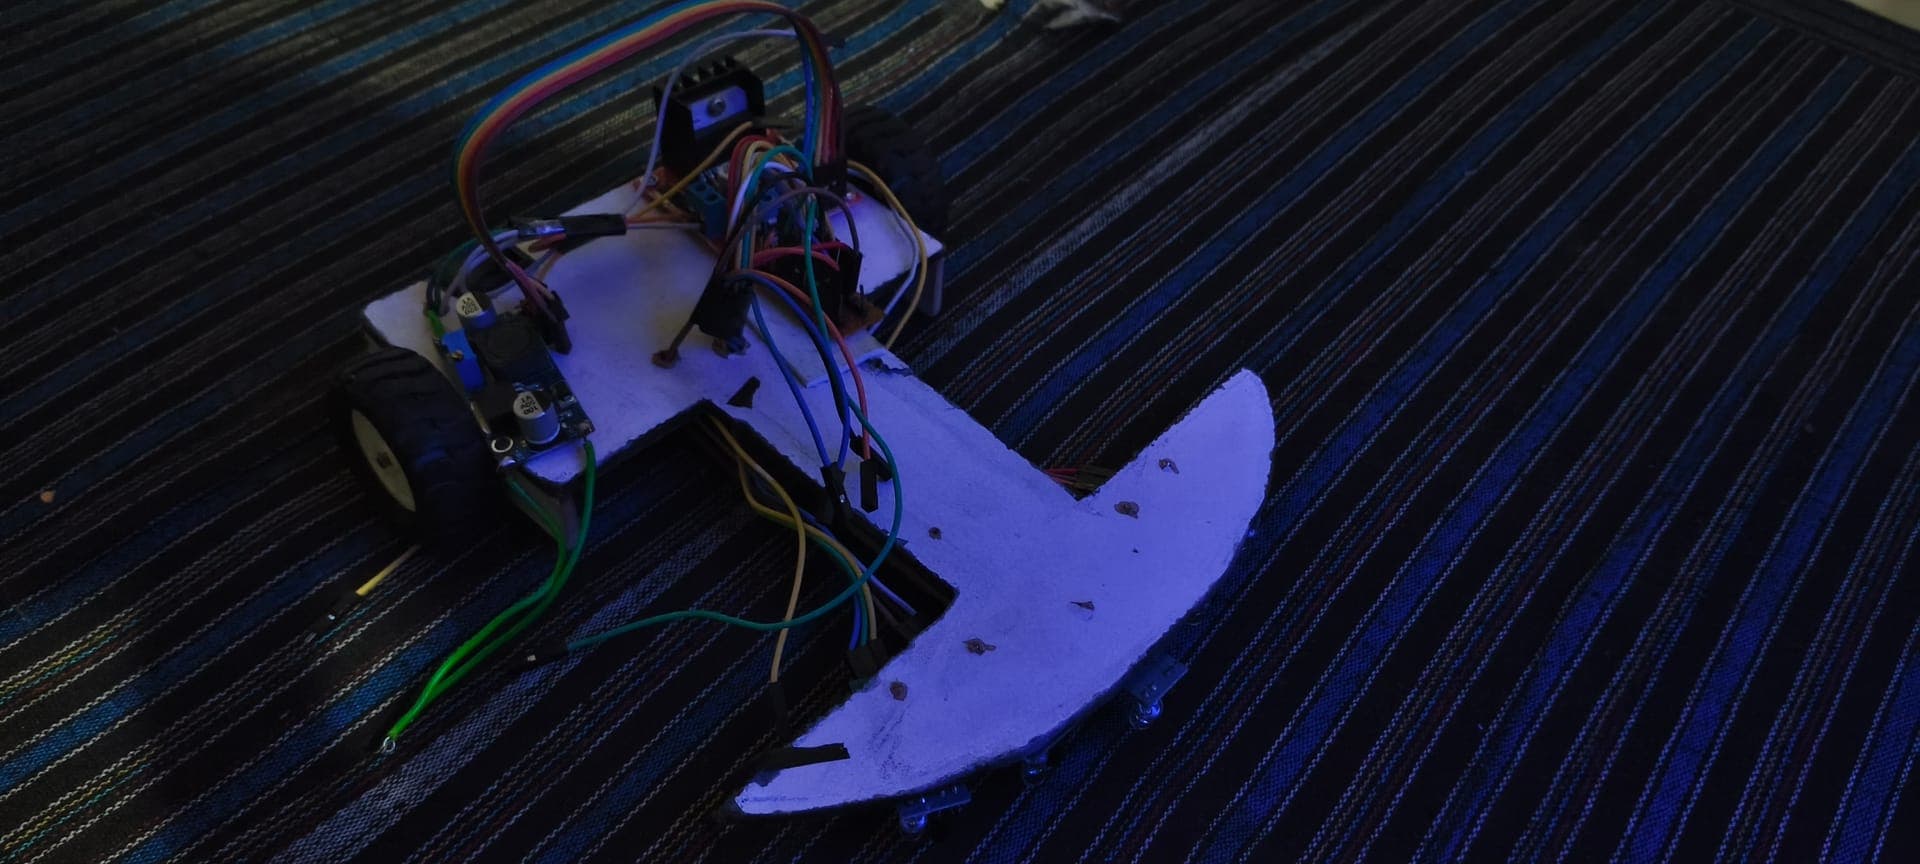
Autonomous 5-Channel IR Line Follower Robot
An autonomous line follower robot with a 5-channel TCRT5000 IR sensor array, L298N differential drive, and PID weighted error logic for smooth trajectory execution.
Why we built this
Standard 2-IR followers produce harsh, jerky turns. We engineered this 5-IR system so students could master proportional-derivative (PID) feedback control on affordable hardware.
Free technical report & Drive guide available