Control SystemsYear 2026Completed
Self-Balancing Robot 1
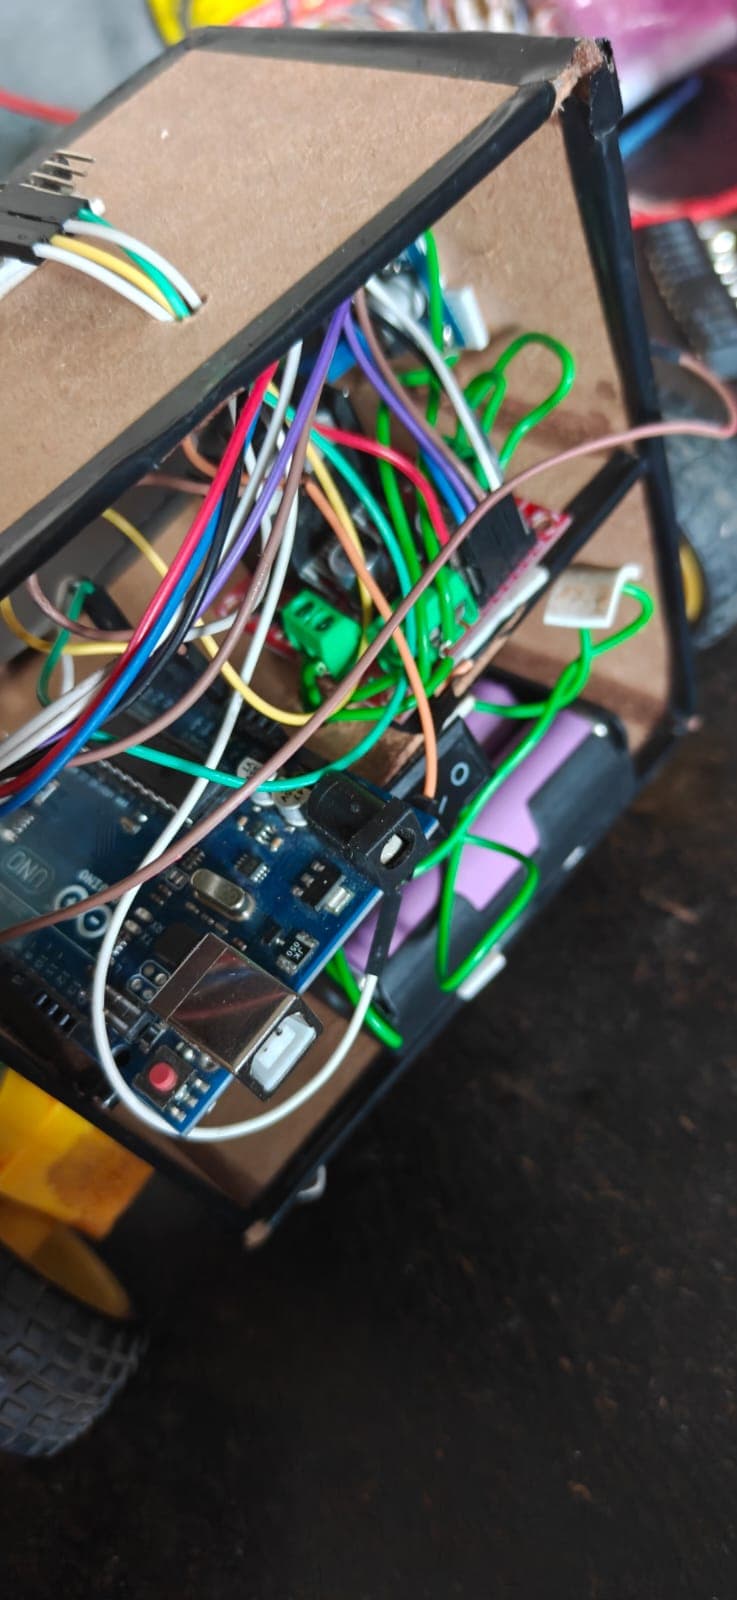
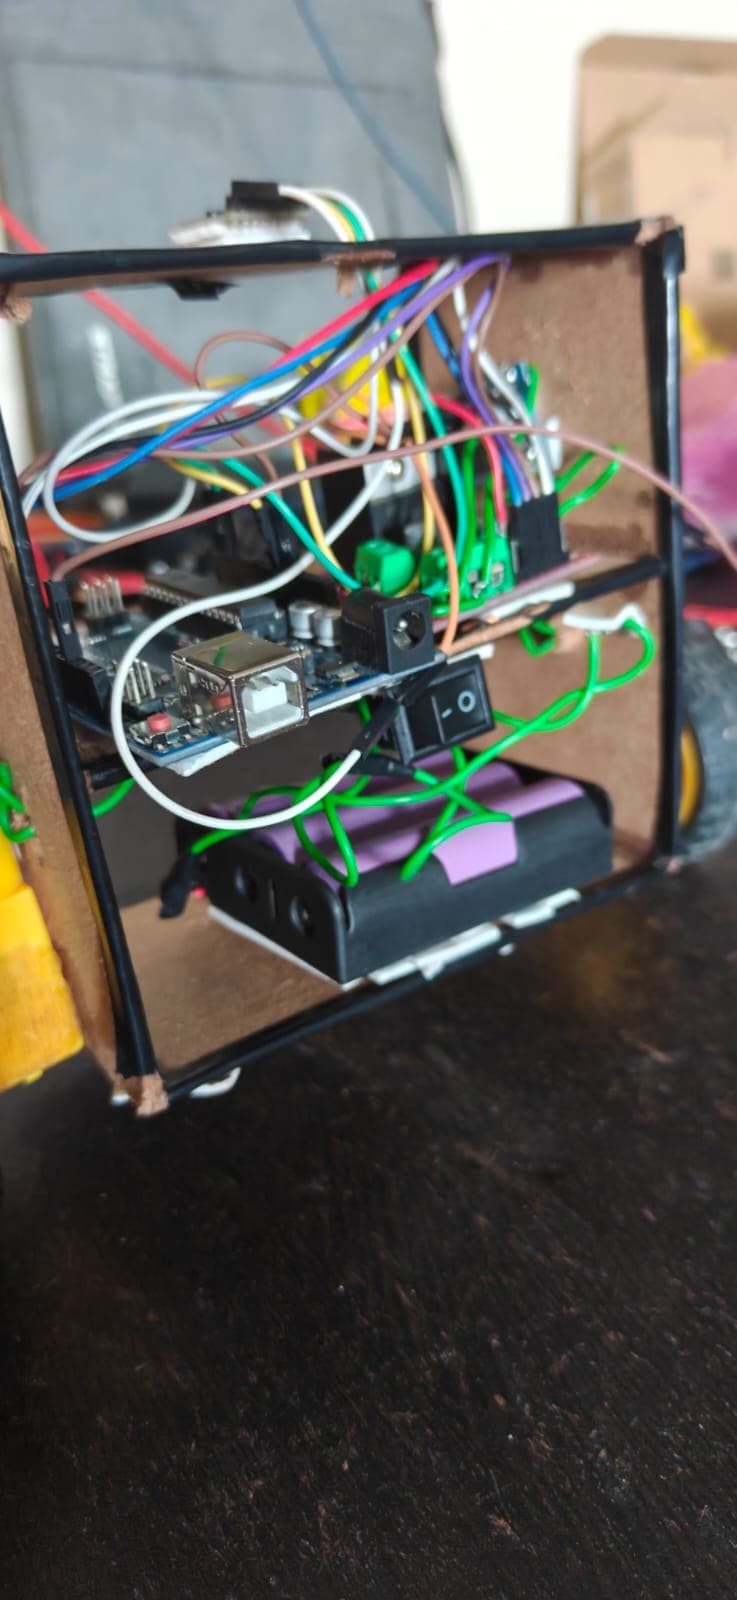
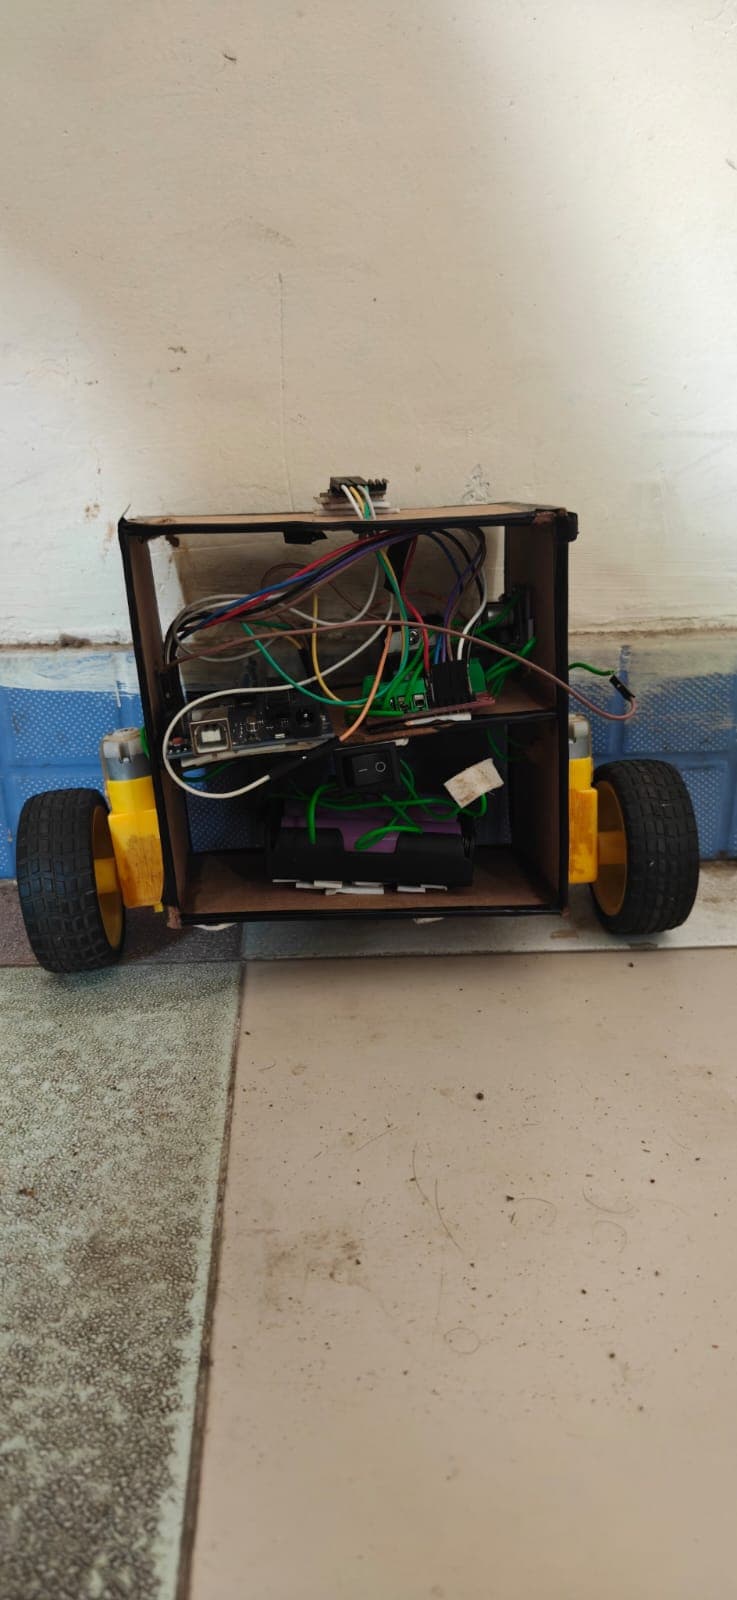
A two-wheeled robot that stays upright in real time using an IMU and a PID balance controller.
ArduinoSensor FusionPID ControlControl Theory
1 / 4
Two-wheeled PID inverted pendulum balancing
Why We Built This
Control theory on a budget — we built this so students can experiment with PID tuning without industrial equipment.
Overview
An inverted-pendulum challenge, this two-wheeled robot reads tilt from an IMU and drives its motors to constantly correct its balance.
Highlights & Key Features
- MPU6050 IMU with complementary filter
- Real-time PID balance loop
- Recovers from small pushes
- Tunable gains for experimentation
The Challenge
Fusing accelerometer and gyro data into a stable tilt estimate, then tuning the PID for fast recovery.
The Outcome
The robot balances and self-corrects; serves as our foundational control theory platform.
Build Gallery & Photos
[4 PHOTOS]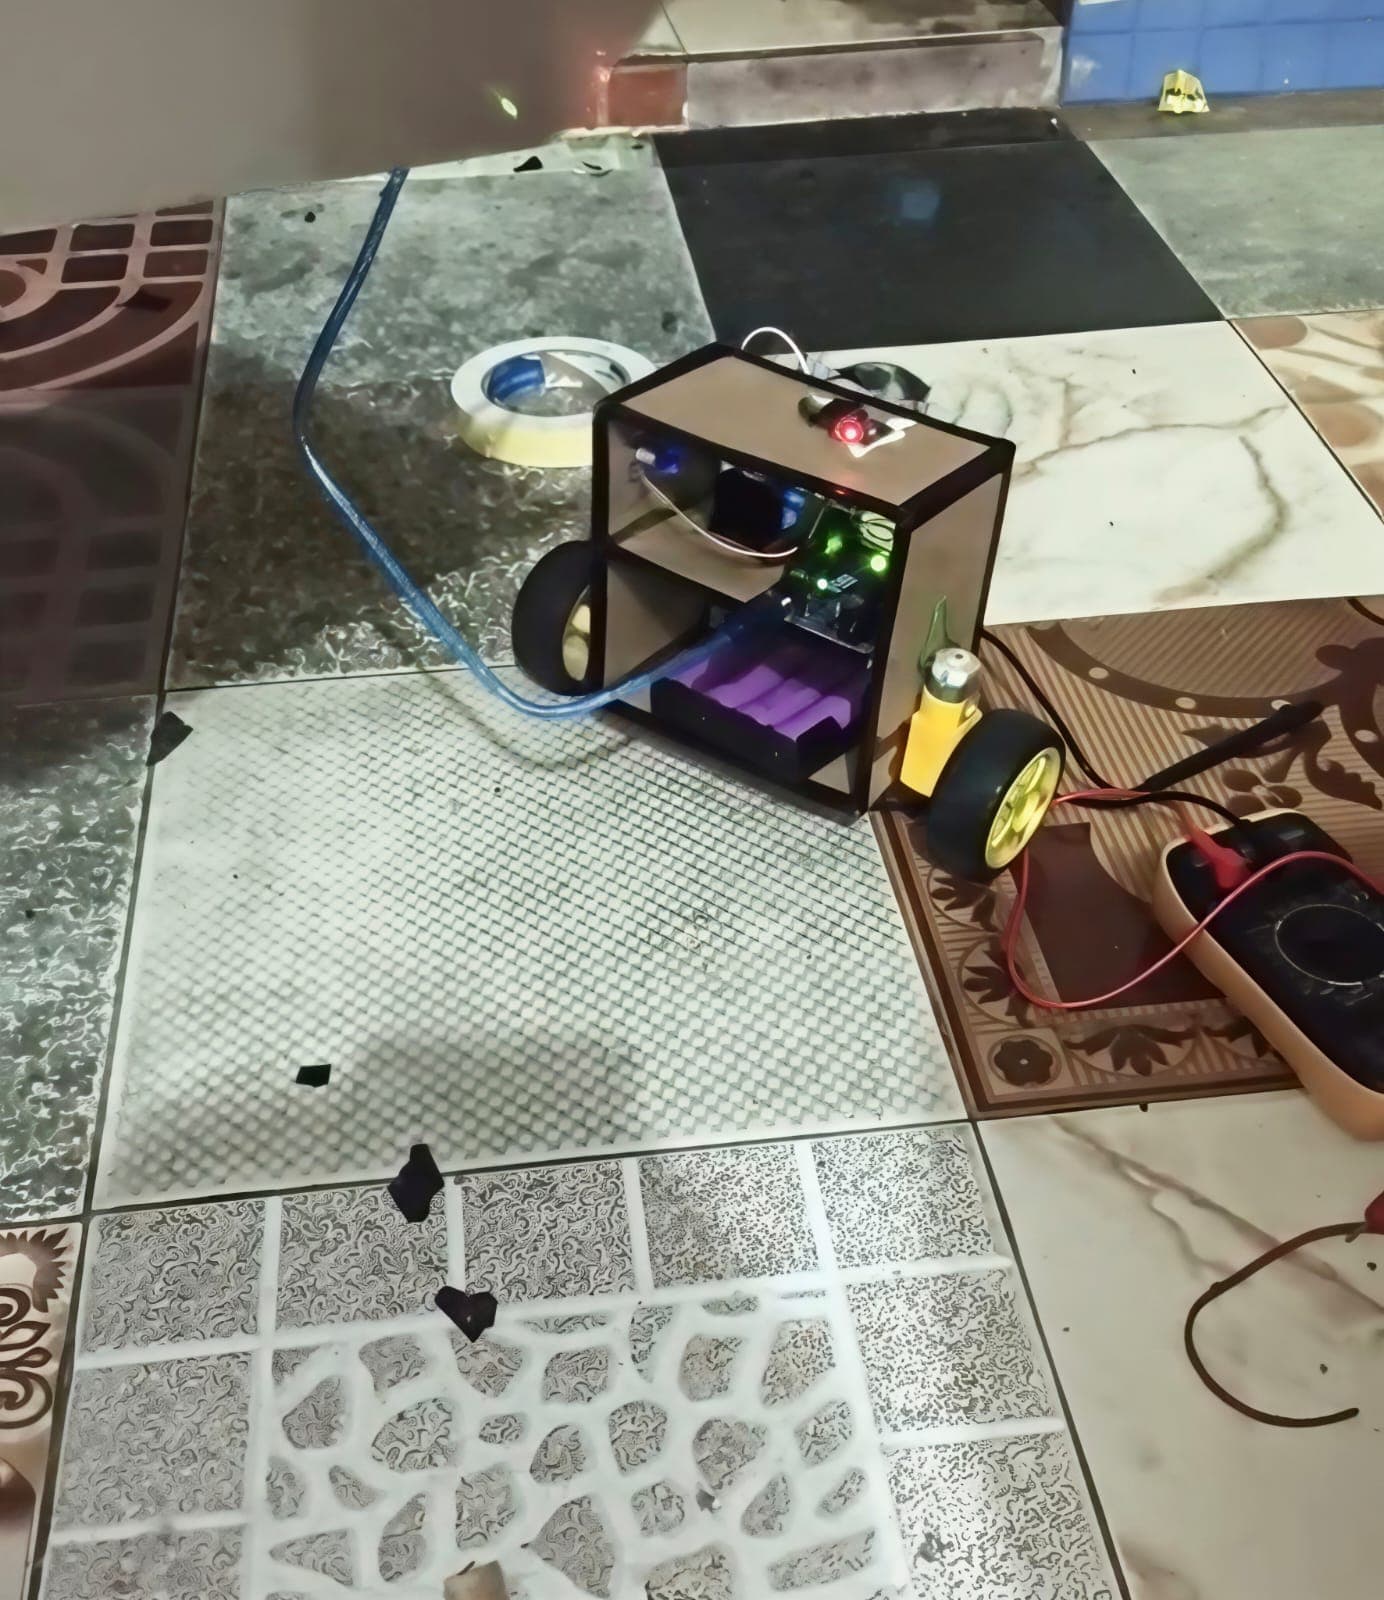
More Projects
 Control Systems
2026
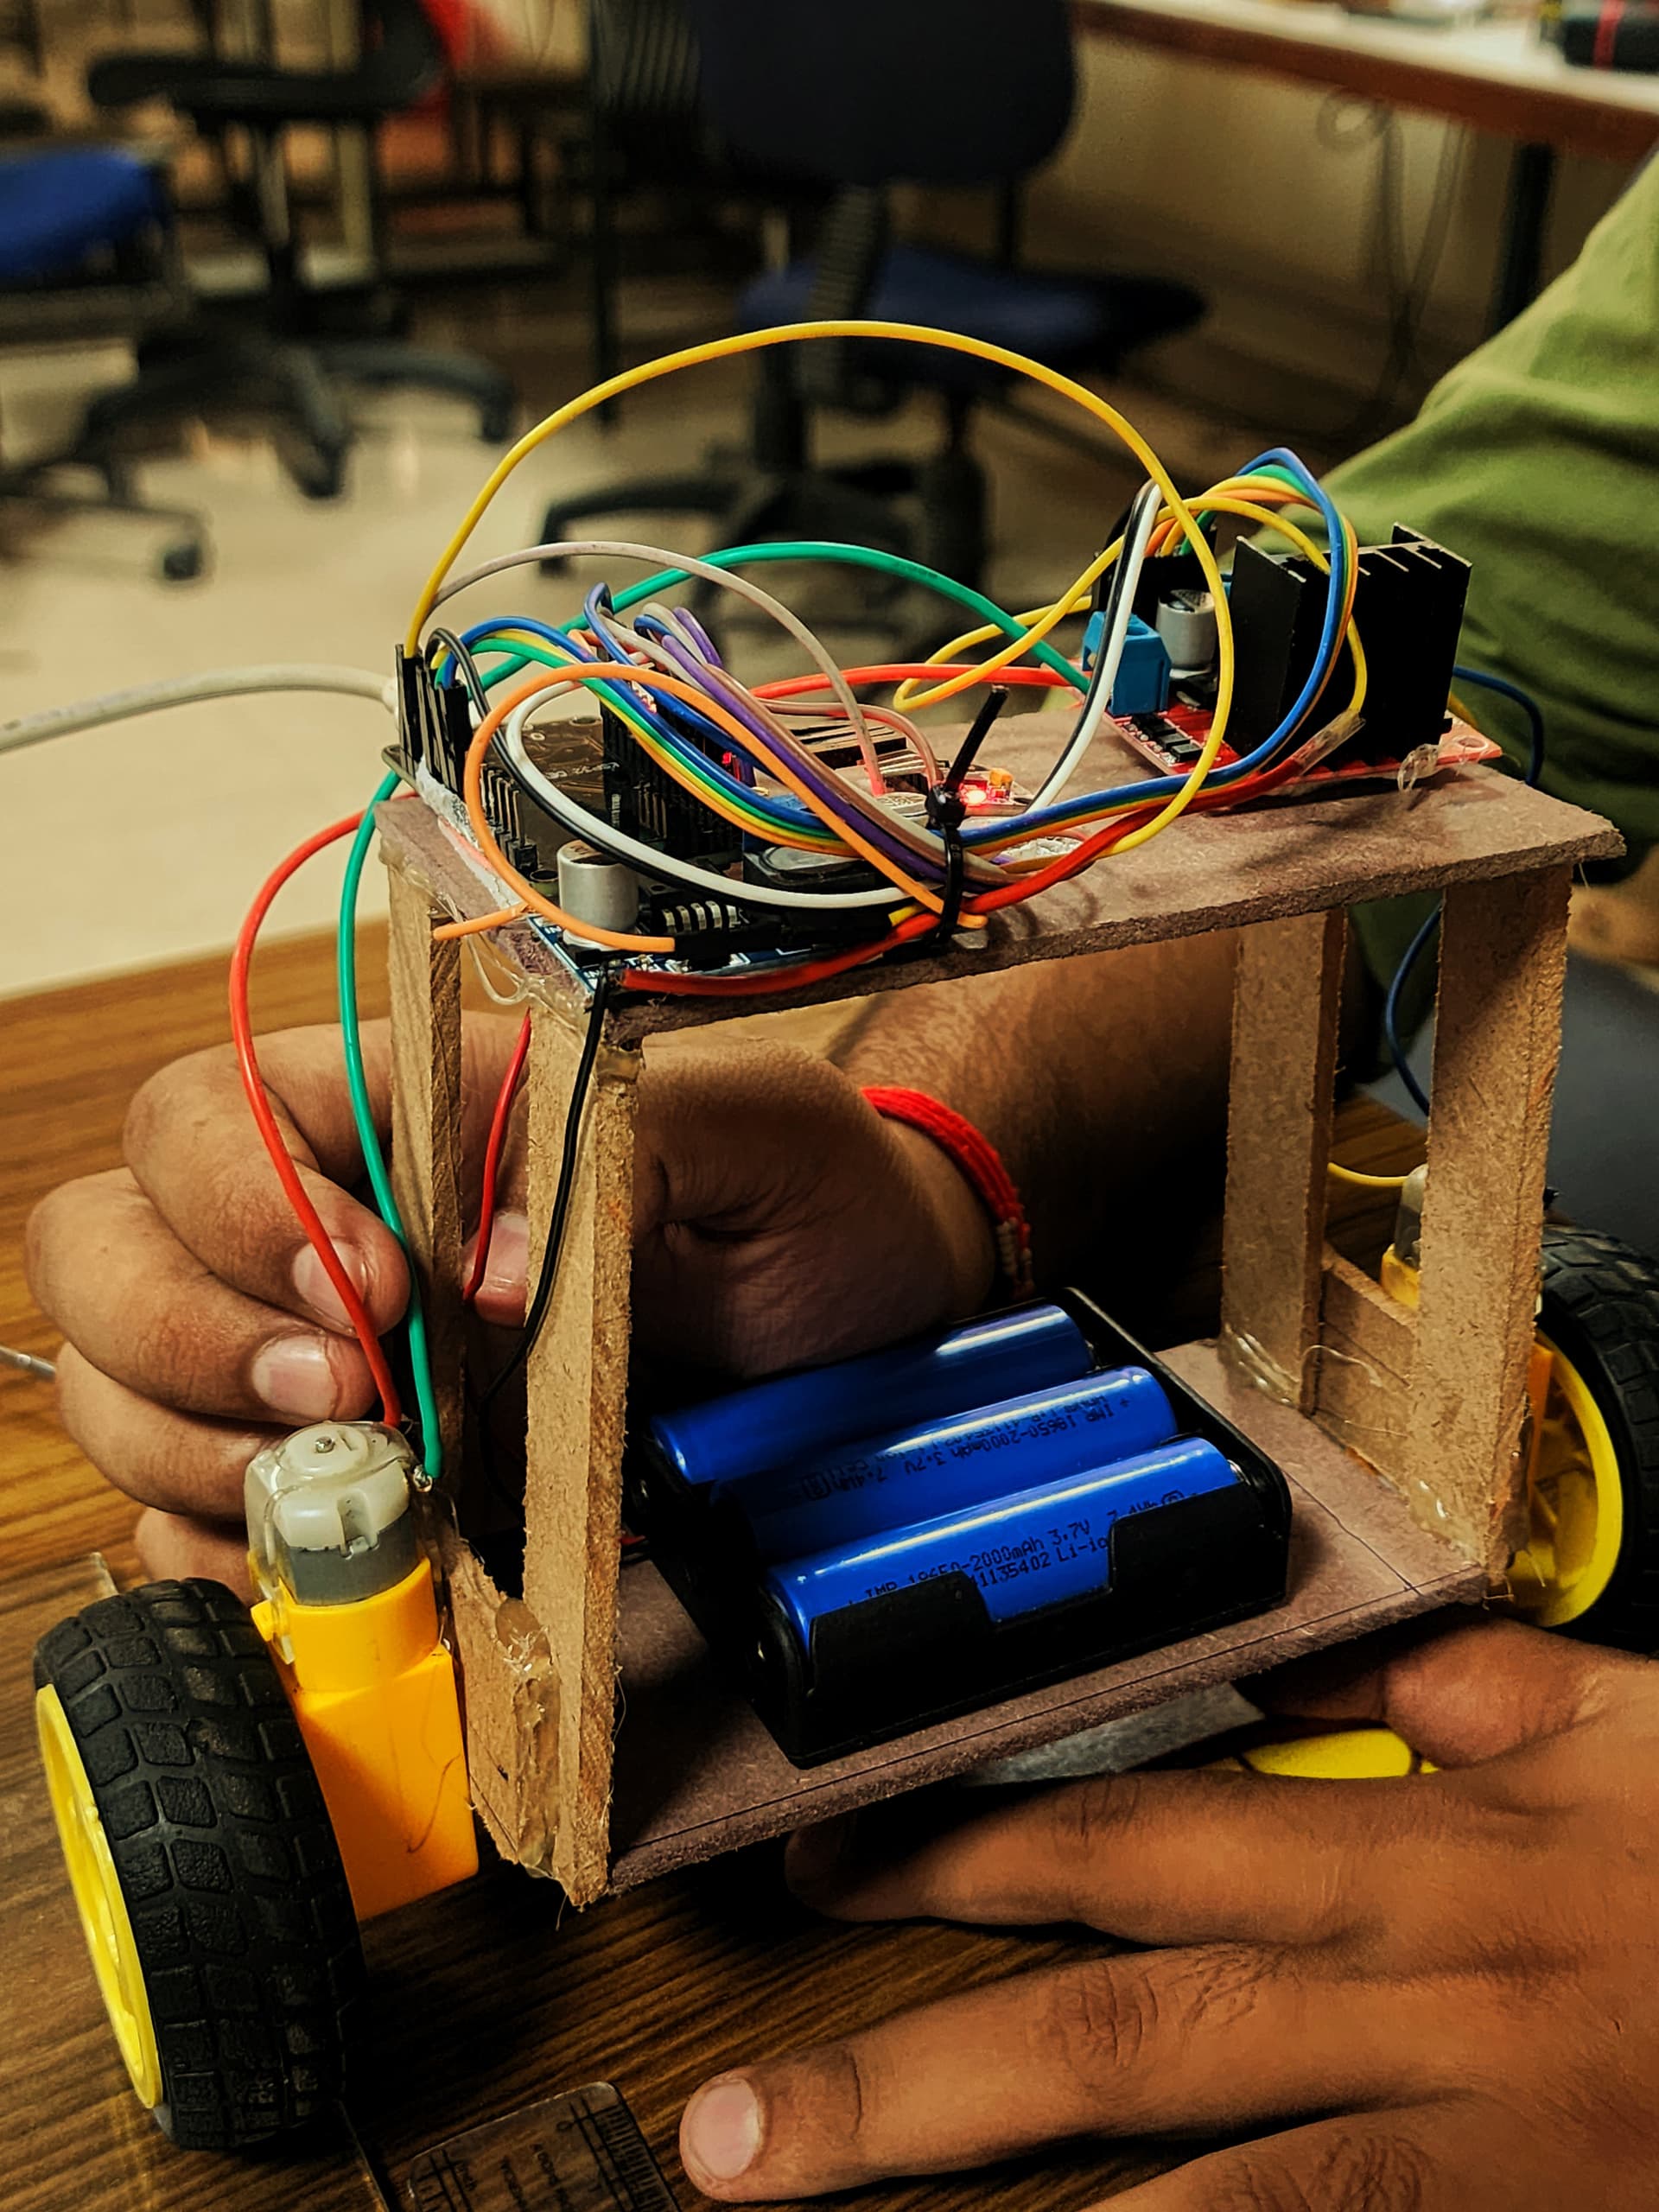
Self-Balancing Robot 2
A second-generation inverted pendulum robot featuring a modular dual-deck chassis, low-center-of-gravity 3S 18650 battery bank, MPU6050 6-axis IMU, and closed-loop PID tilt recovery.
Why we built this
Iterating on our initial self-balancing experiments, Version 2 addresses chassis rotational inertia by placing heavy battery cells low on the base deck, dramatically improving recovery stability.
Free technical report & Drive guide available
 Aerospace
2026
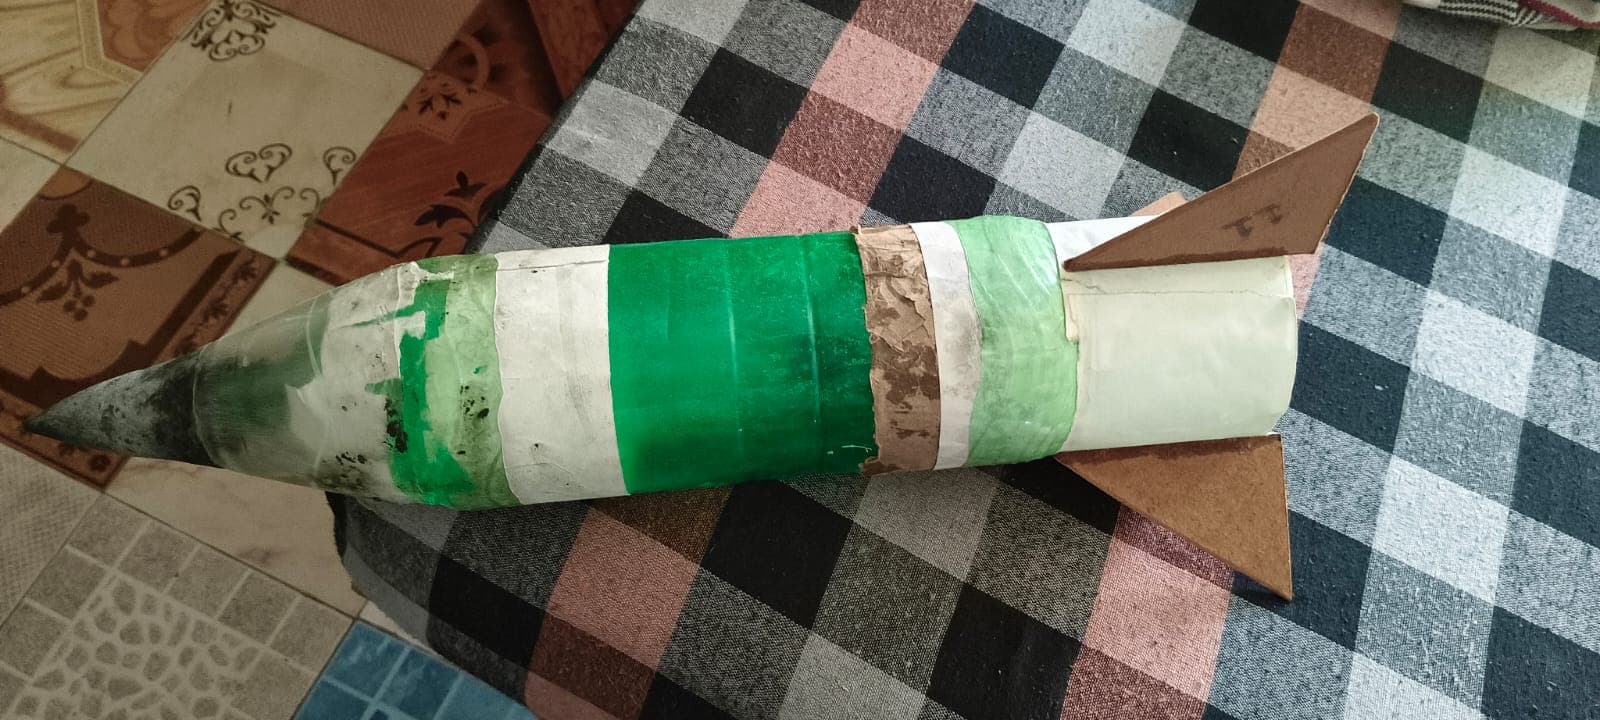
Water Rocket
A pressurised water-and-air rocket engineered for maximum altitude and a clean recovery.
Why we built this
A zero-cost intro to physics and engineering using recycled bottles — perfect for school outreach demos where budgets are tight.
Free technical report & Drive guide available
 Autonomous Systems
2026
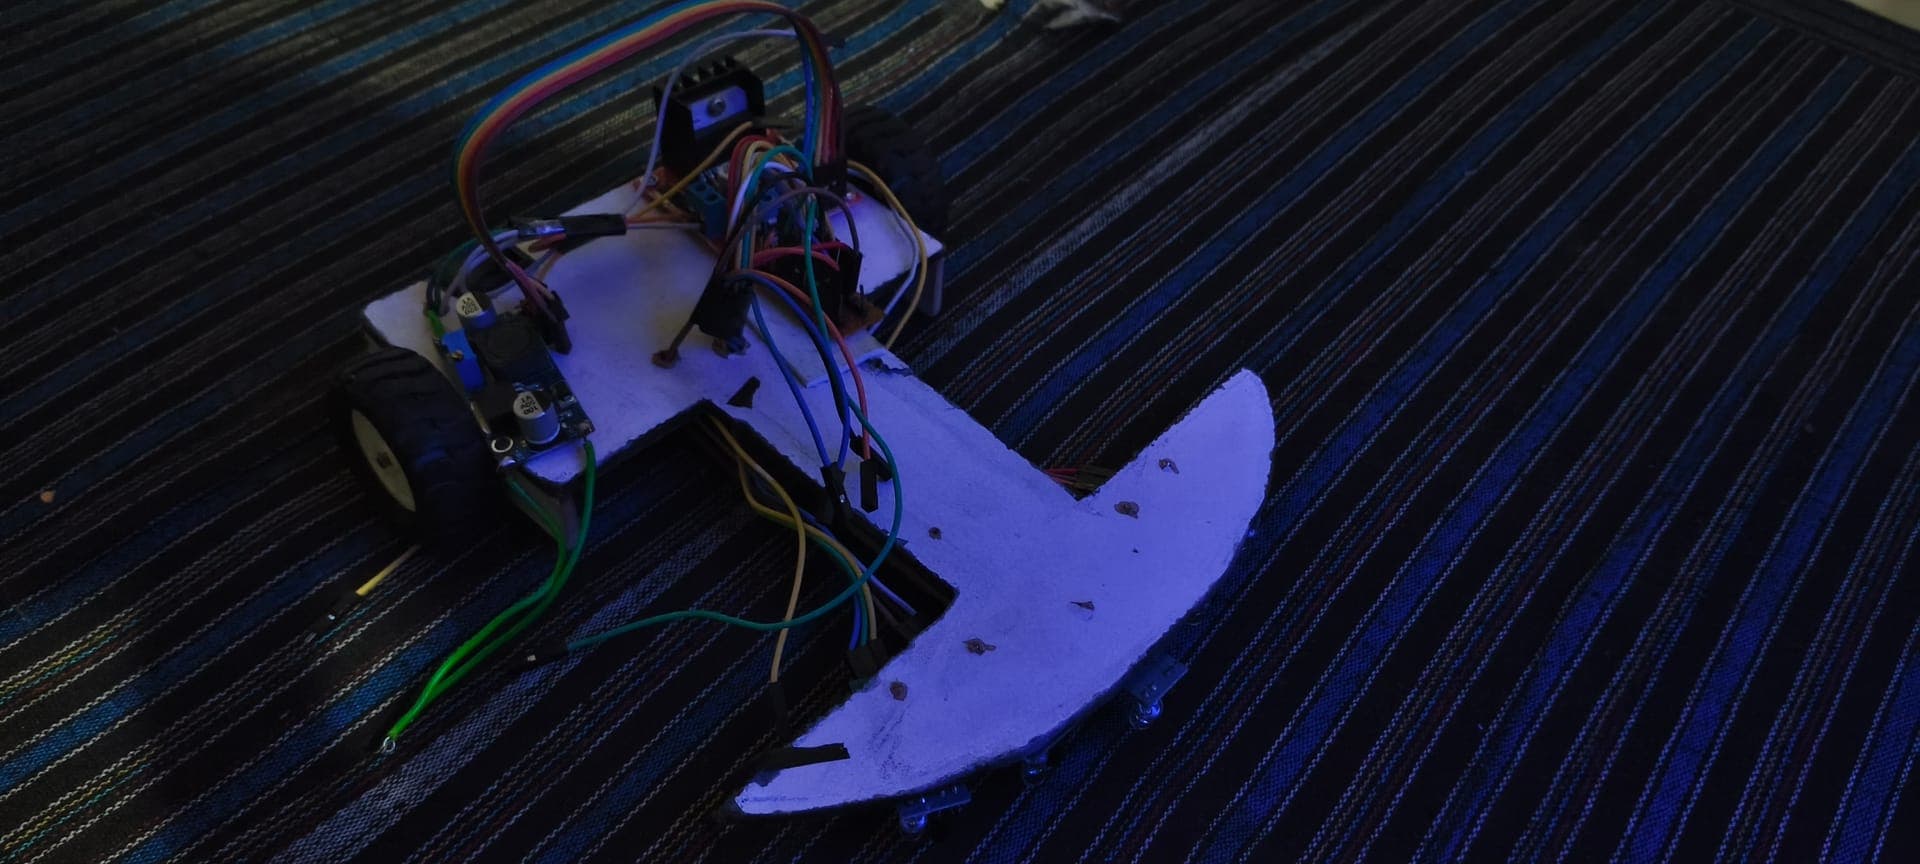
Autonomous 5-Channel IR Line Follower Robot
An autonomous line follower robot with a 5-channel TCRT5000 IR sensor array, L298N differential drive, and PID weighted error logic for smooth trajectory execution.
Why we built this
Standard 2-IR followers produce harsh, jerky turns. We engineered this 5-IR system so students could master proportional-derivative (PID) feedback control on affordable hardware.
Free technical report & Drive guide available