All Projects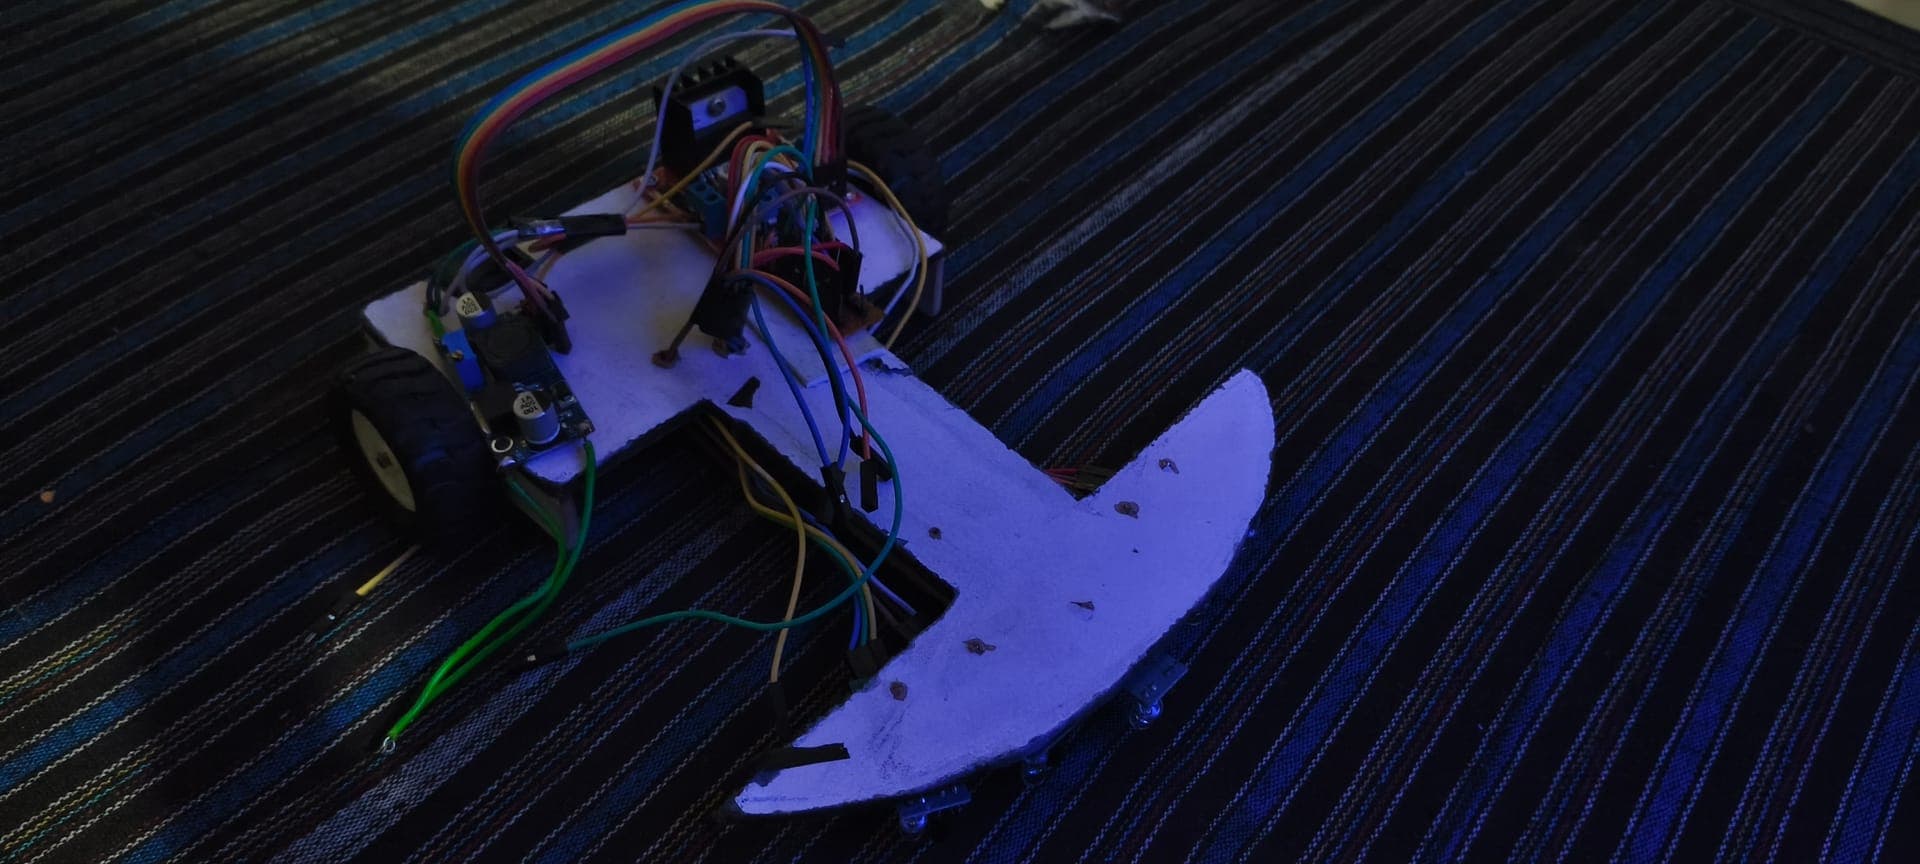
Autonomous SystemsYear 2026
Autonomous 5-Channel IR Line Follower Robot
An autonomous line follower robot with a 5-channel TCRT5000 IR sensor array, L298N differential drive, and PID weighted error logic for smooth trajectory execution.
Arduino C++PID ControlIR SensingDifferential Drive
5-Channel IR sensor array & L298N chassis layout
Overview
This autonomous line follower employs a 5-sensor IR array (Far Left, Near Left, Center, Near Right, Far Right) paired with an L298N dual H-bridge motor driver. By calculating weighted spatial errors across the array (-4 to +4), the robot dynamically computes smooth differential motor speeds using a PID algorithm (BaseSpeed ± Kp×Error + Kd×ΔError). If the line is momentarily lost, an error-memory recovery loop executes sharp pivot recovery.
Highlights
- 5-Channel TCRT5000 IR sensor array with weighted error scale
- Proportional-Integral-Derivative (PID) dynamic motor control
- L298N Dual H-Bridge motor driver with PWM speed regulation
- Last-error tracking for automatic off-track pivot recovery
The Challenge
Eliminating mechanical jerks on sharp 90-degree track curves required fine-tuning the proportional (Kp=25.0) and derivative (Kd=15.0) gain parameters.
The Outcome
Achieved smooth, high-speed line tracking with zero oscillation on sharp bends, serving as a core hands-on control theory model.
Project Media & Build Gallery
[4 PHOTOS]5-Channel IR sensor array & L298N chassis layout
More Projects
 Human-Machine Interface
2026
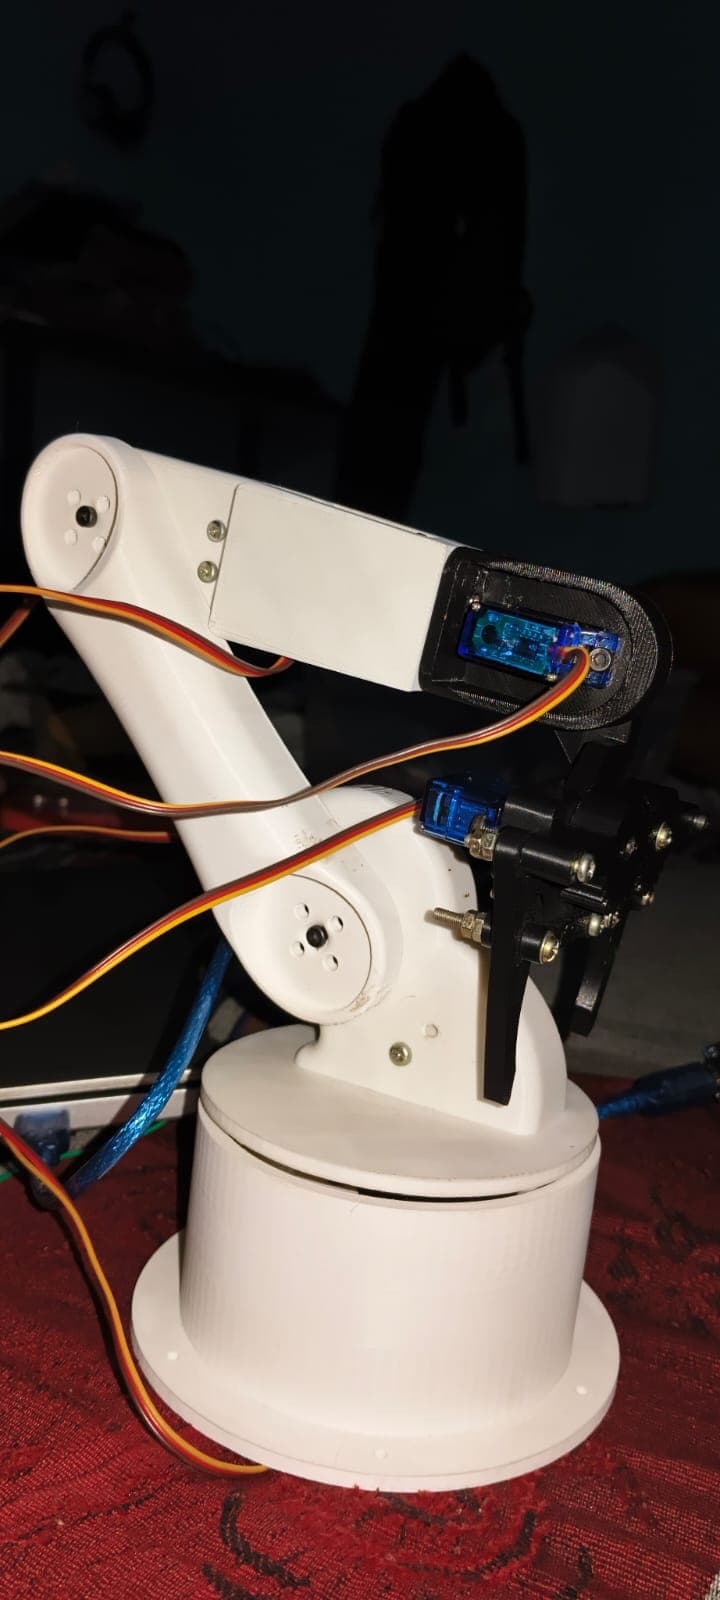
6-DOF CyberDeck & 5-DOF Teach-Repeat Robotic Arm
Industrial-grade 6-DOF & 5-DOF robotic manipulation systems featuring OpenCV AI vision hand tracking, Flask-SocketIO web control, and teach-repeat trajectory playback.
Why we built this
Industrial robot arms are typically locked behind proprietary software; we designed an open hardware ecosystem combining AI computer vision, web dashboards, and manual potentiometer teach modes.
Free technical report & Drive guide available
 Renewable Energy Systems
2026
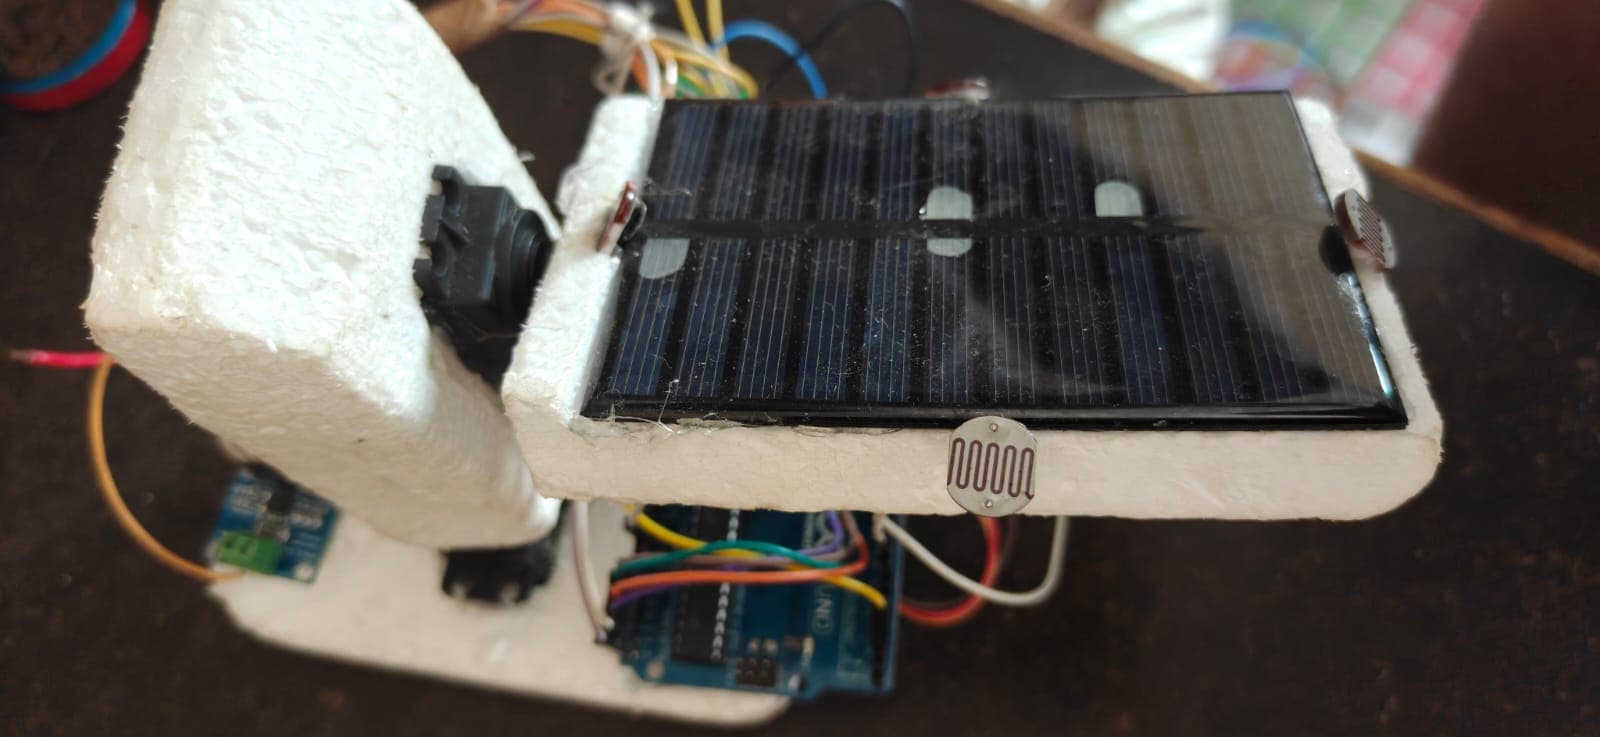
Dual-Axis Solar Tracking & Energy Management System
A dual-axis (Yaw & Pitch) photovoltaic tracking system equipped with high-side INA219 I2C current/voltage telemetry, DHT22 climate sensors, and closed-loop battery charging.
Why we built this
Stationary solar panels suffer significant efficiency drops; we built an intelligent dual-axis tracker that maximizes energy capture while monitoring real-time power metrics.
Free technical report & Drive guide available
 IoT & Embedded Systems
2026
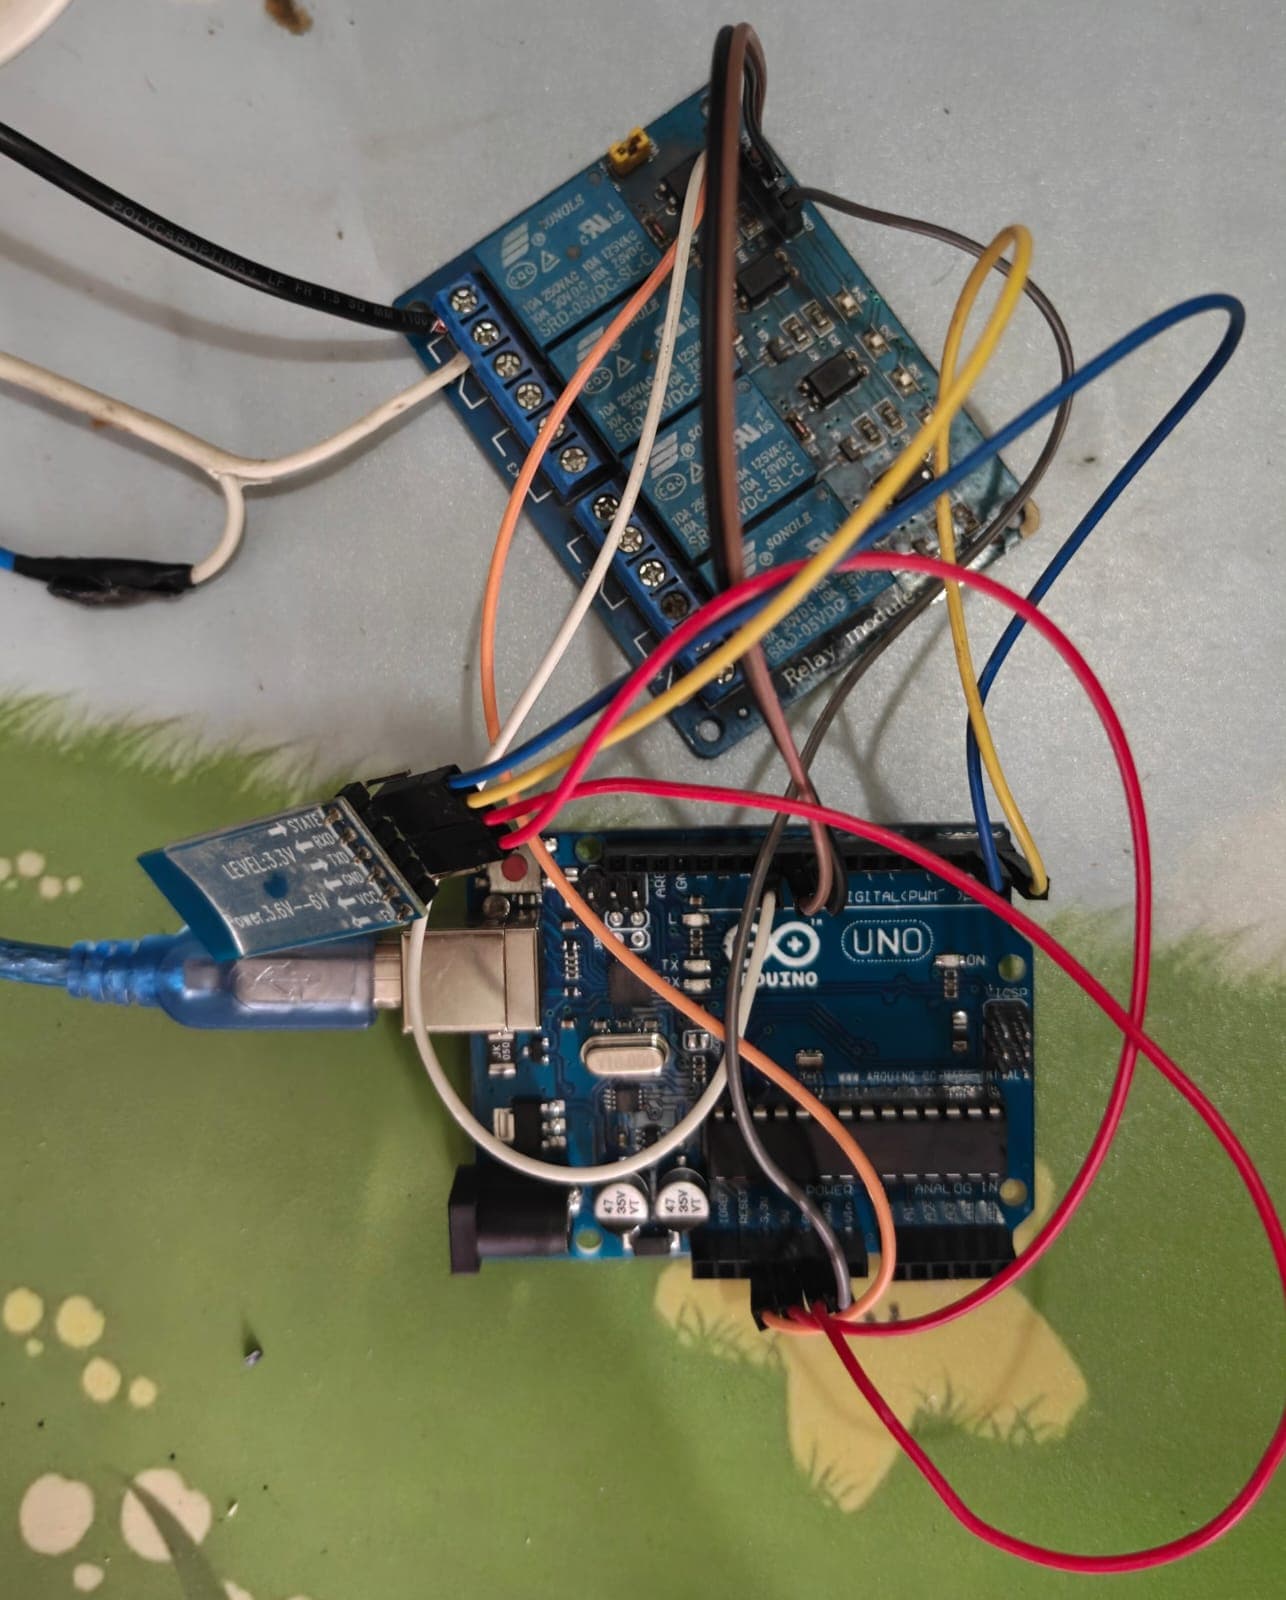
Smart Home Automation & IoT Energy Hub
A modular ESP32-powered home automation controller supporting multi-channel relay switching, MQTT telemetry, local web dashboard, and physical wall switch overrides.
Why we built this
Modern home automation proprietary hubs are expensive; we engineered a low-cost, open-hardware controller with fallback physical wall switches.
Free technical report & Drive guide available