Autonomous SystemsYear 2026Completed
Autonomous Line Follower Robot 2
A second-generation autonomous line tracker featuring a wide-span multi-channel optical sensor bar, high-speed differential drive, and refined PID trajectory recovery algorithms.
Arduino C++PID ControlOptical SensingDifferential DriveRapid Prototyping
1 / 4
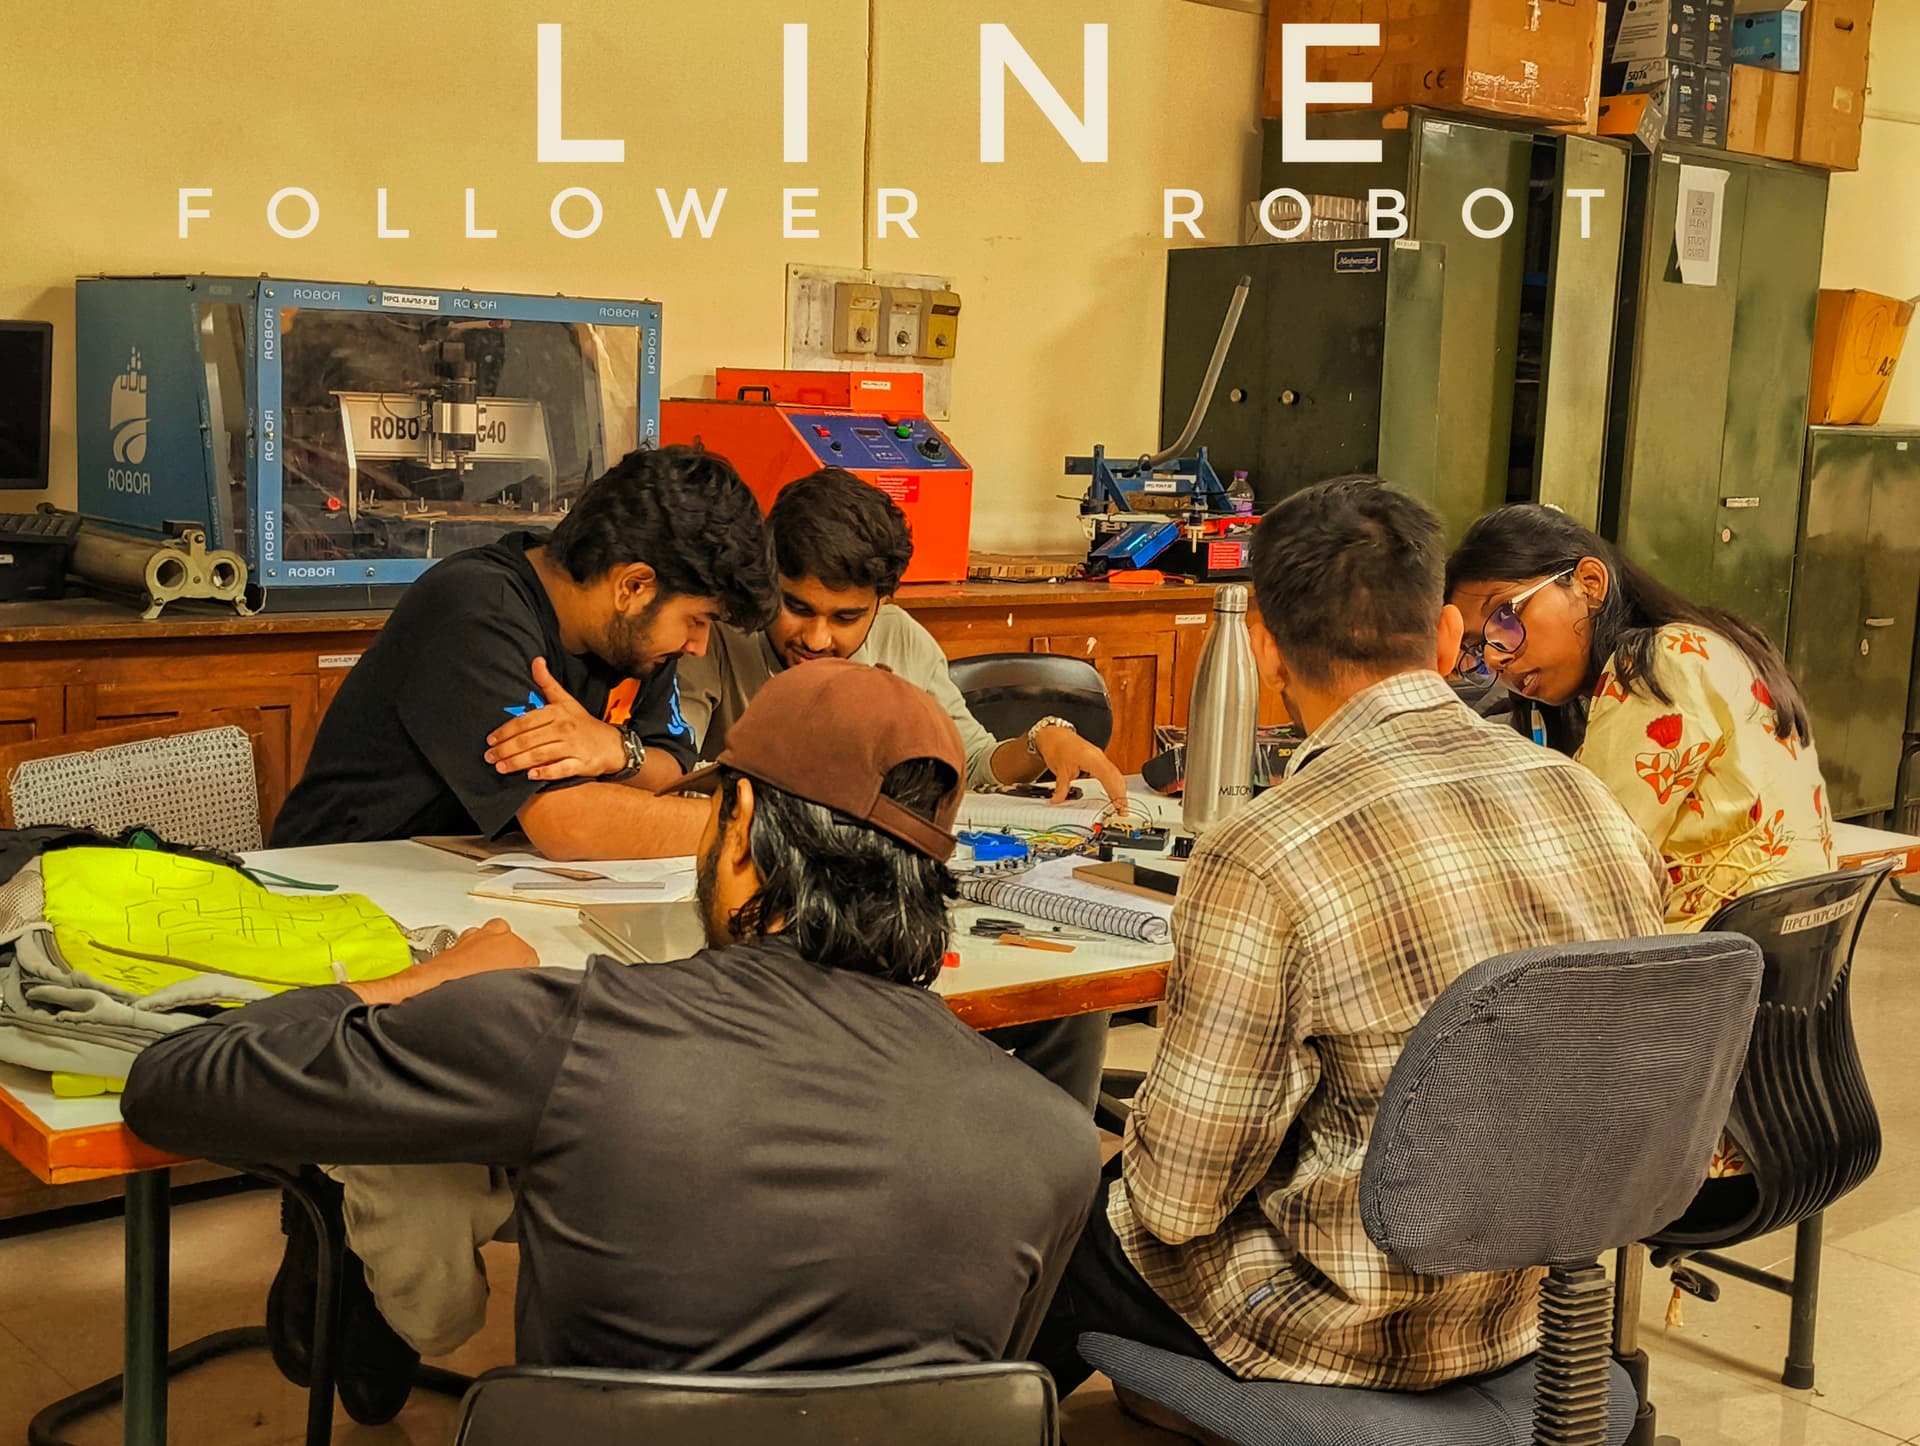
VyomikX engineering team collaborating on Line Follower 2 development in the lab
Why We Built This
Building on our first line follower, Line Follower 2 was designed with an extended sensor baseline and streamlined chassis to achieve higher cornering speeds and tighter tracking accuracy on complex tracks.
Overview
Line Follower Robot 2 evolves our autonomous navigation platform with an extended multi-channel optical sensor array mounted on a custom front boom bar. The wider sensor footprint provides early look-ahead detection for high-curvature turns. Paired with dual high-traction drive wheels and an optimized PID control loop with differential PWM speed throttling, the robot tracks continuous trajectories with minimal hunting oscillation.
Highlights & Key Features
- Extended wide-span optical sensor array with active status indicators
- High-speed differential steering with high-grip rubber drive wheels
- Fine-tuned PID trajectory tracking with look-ahead corner anticipation
- Dual 18650 lithium power supply with regulated motor voltage
The Challenge
Balancing weight distribution between the forward sensor boom and the rear battery pack to prevent front dragging while maintaining strong wheel traction.
The Outcome
Demonstrated superior curve handling and stability compared to earlier prototypes, serving as a competition-ready testbed.
Build Gallery & Photos
[4 PHOTOS]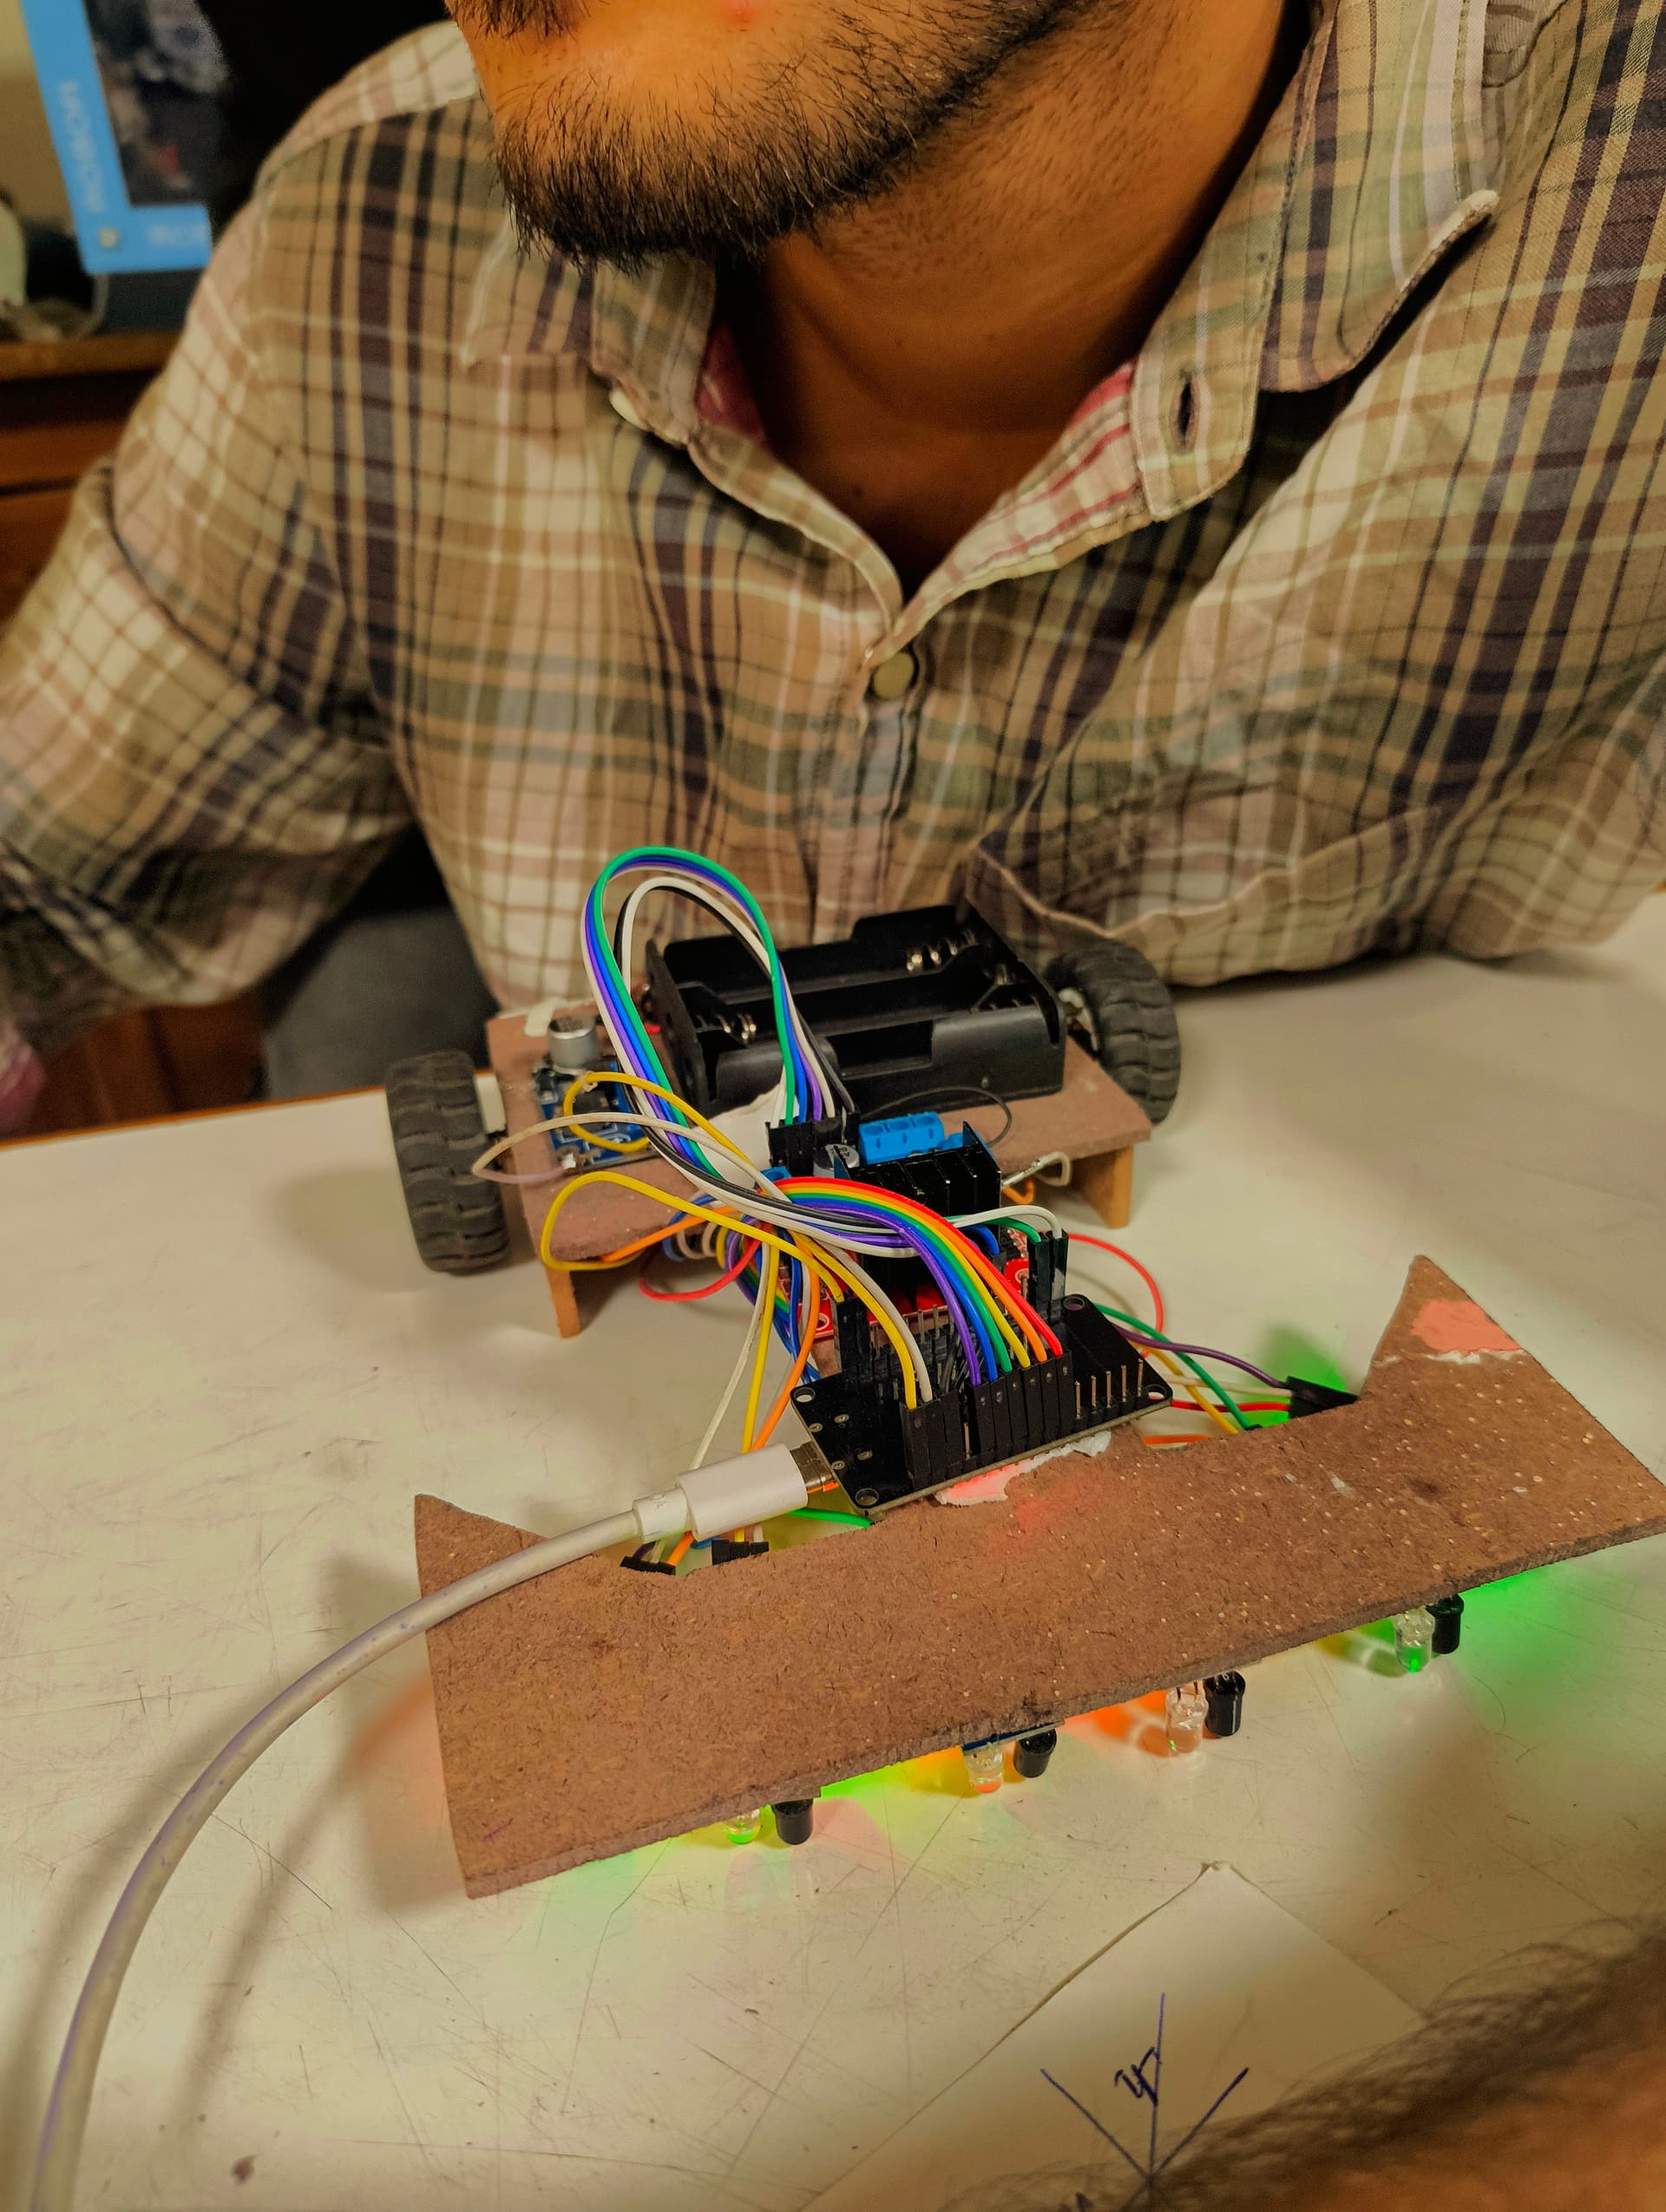
More Projects
 Human-Machine Interface
2026
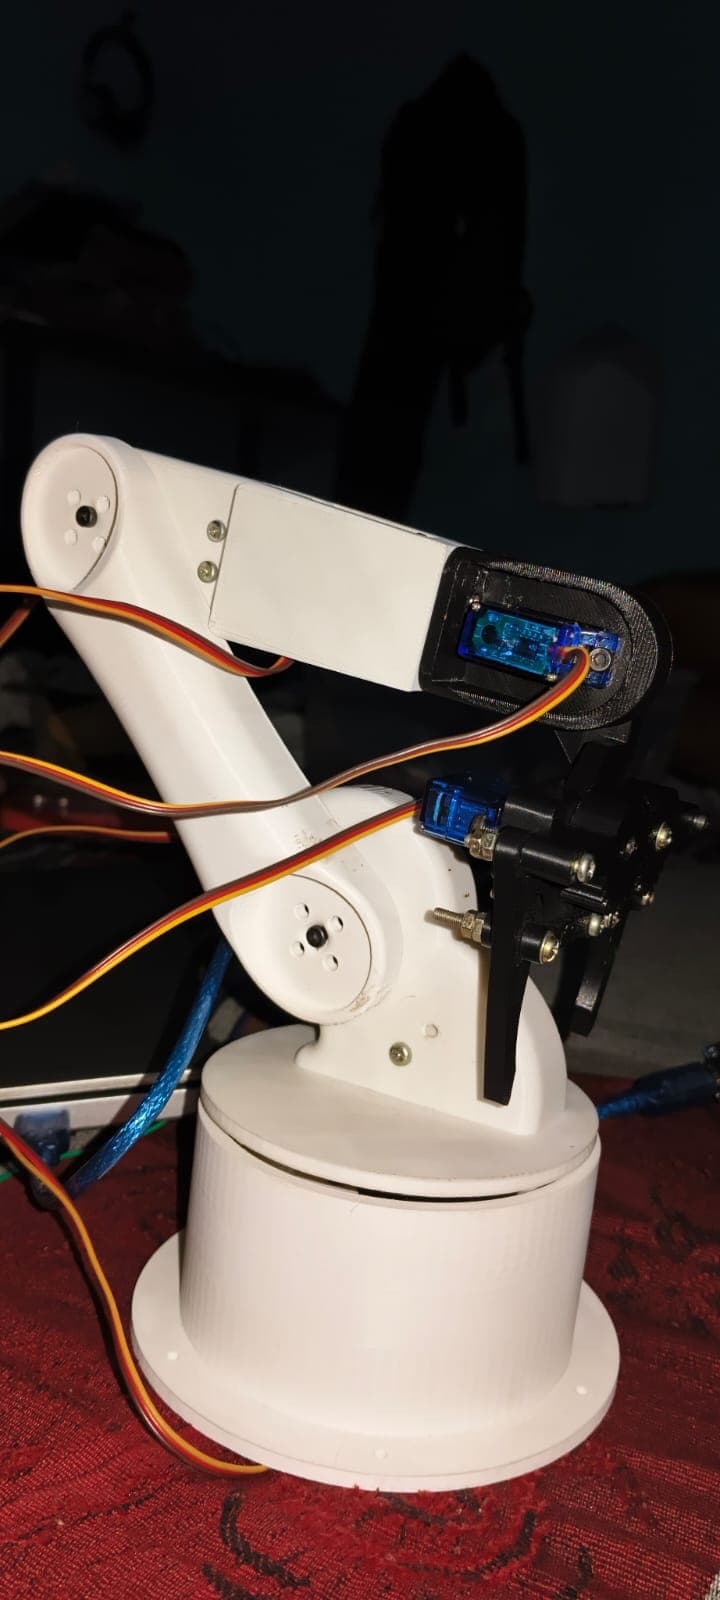
6-DOF CyberDeck & 5-DOF Teach-Repeat Robotic Arm
Advanced 6-DOF & 5-DOF robotic manipulation systems featuring OpenCV AI vision hand tracking, Flask-SocketIO web control, and teach-repeat trajectory playback.
Why we built this
Advanced robot arms are typically locked behind proprietary software; we designed an open hardware ecosystem combining AI computer vision, web dashboards, and manual potentiometer teach modes.
Free technical report & Drive guide available
 Aerial Robotics
2026
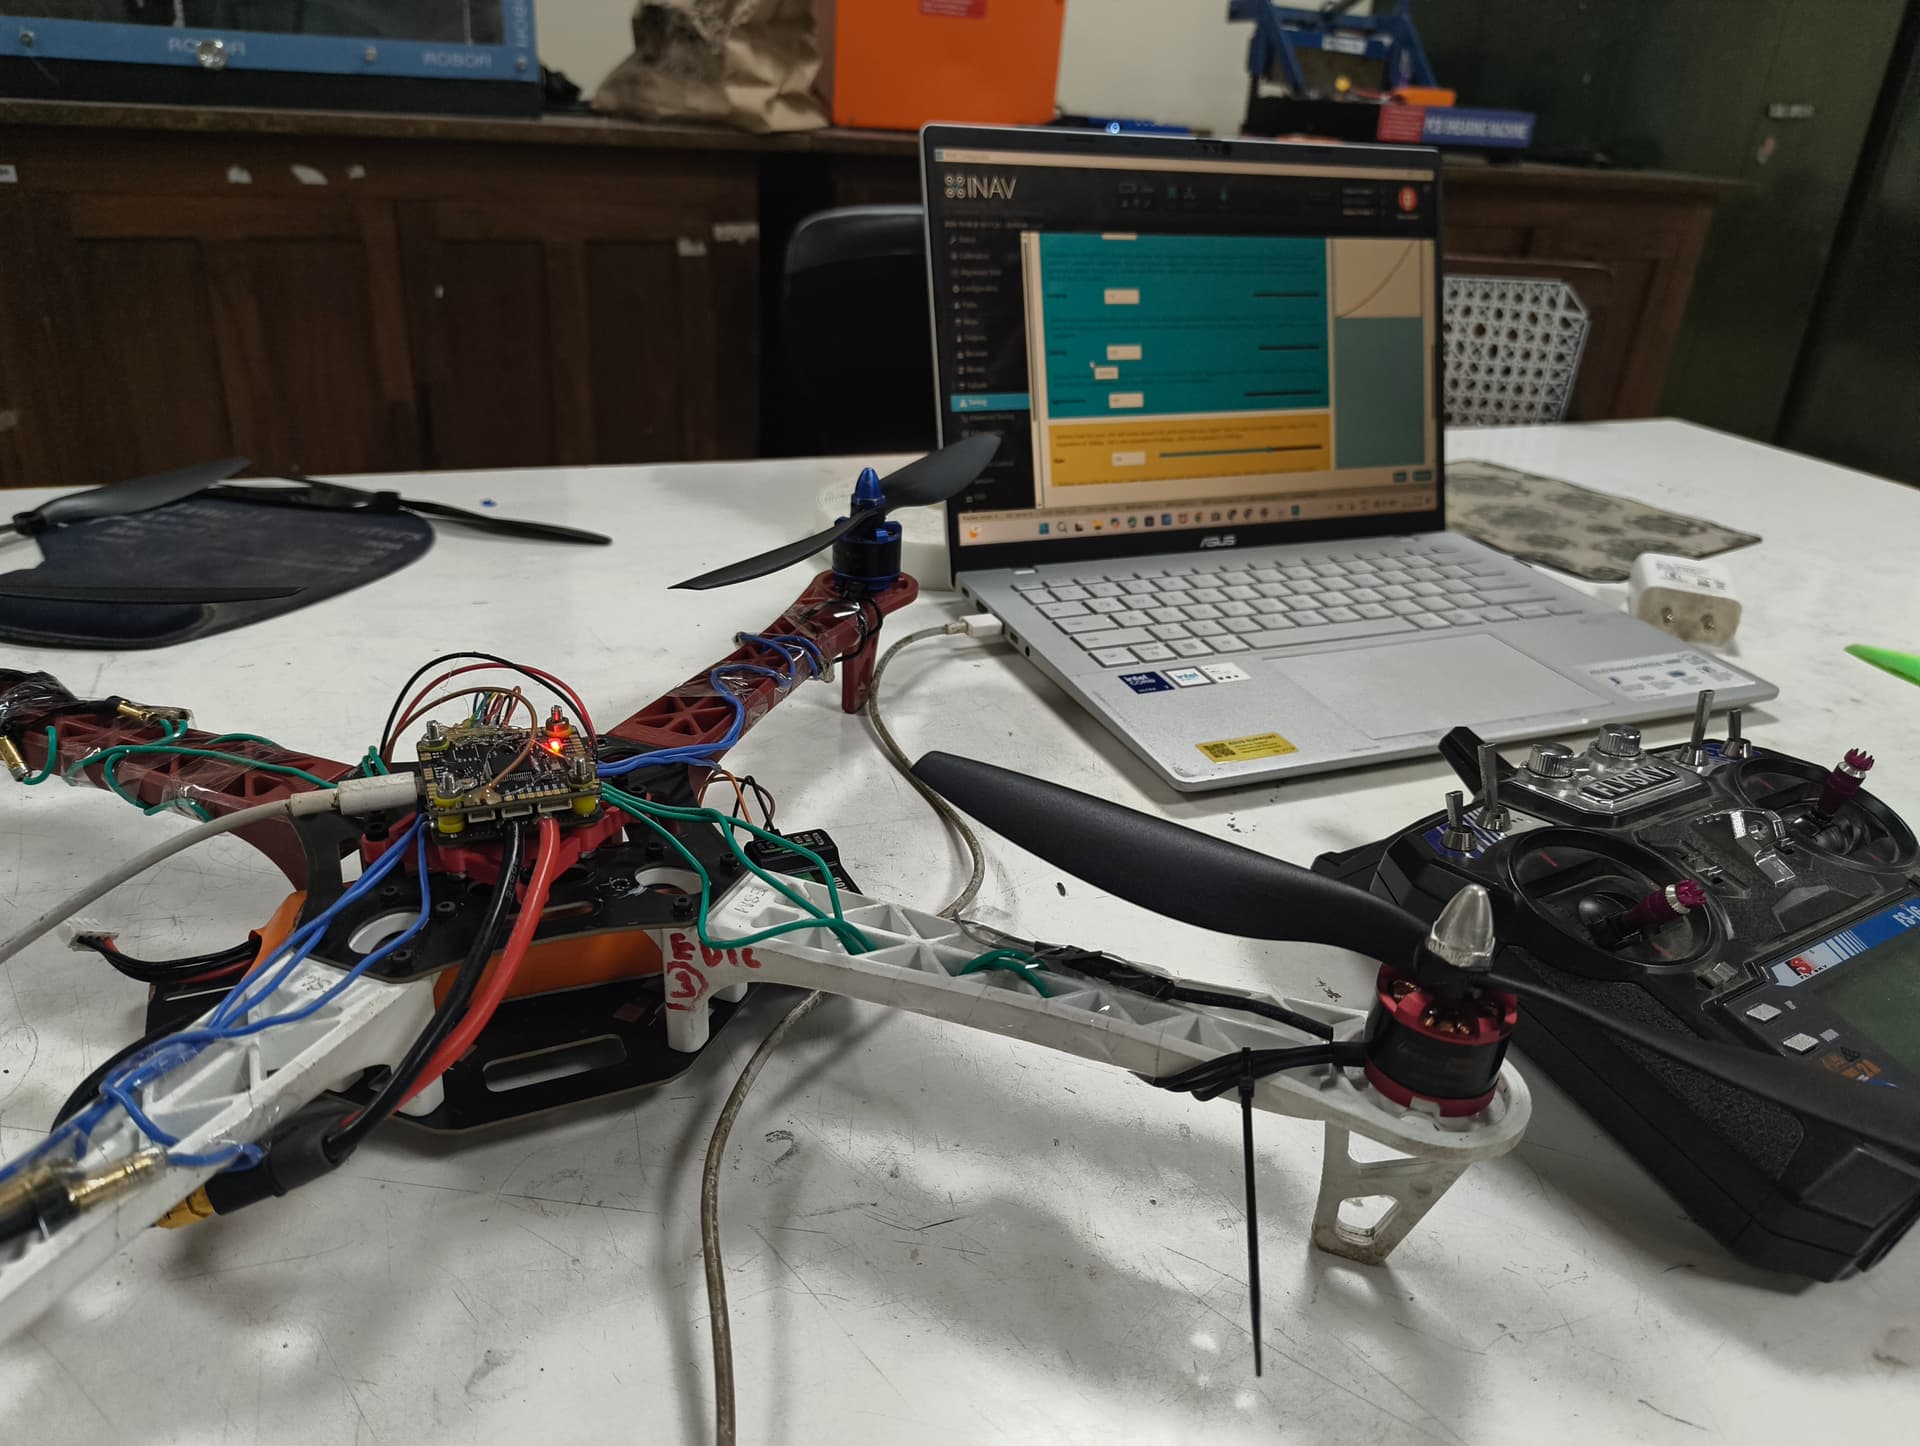
F450 Autonomous Quadcopter Drone
A custom-built F450 quadcopter drone featuring an STM32 F405 flight controller running INAV, 1000KV brushless motors, 1045 propellers, and 2.4GHz FlySky FS-i6 telemetry control.
Why we built this
Commercial ready-to-fly drones hide flight mechanics behind proprietary black boxes; we engineered an open-platform F450 quadcopter from component level so students could master flight dynamics, PID attitude tuning, and avionics.
Free technical report & Drive guide available
 Renewable Energy Systems
2026
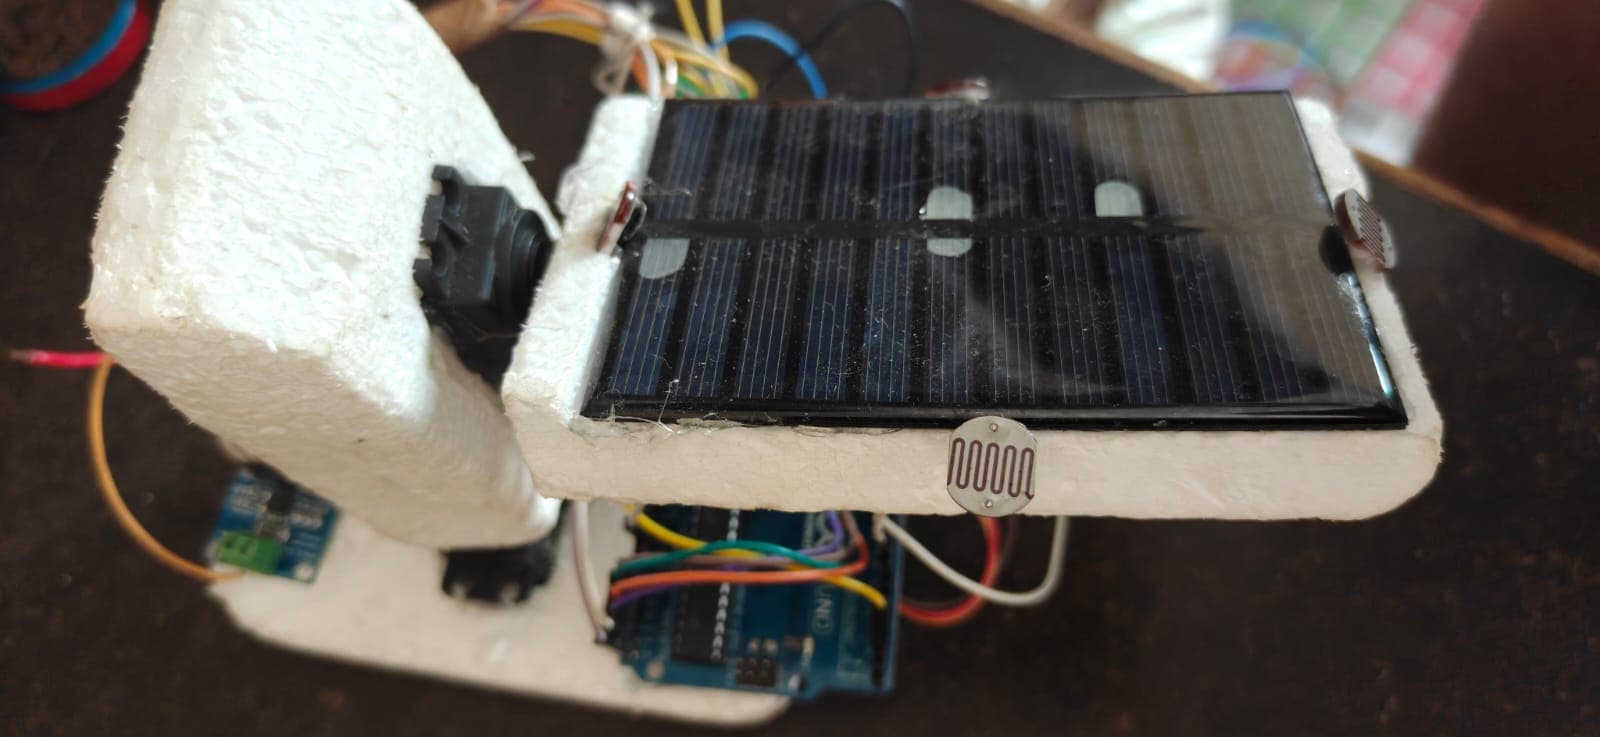
Dual-Axis Solar Tracking & Energy Management System
A dual-axis (Yaw & Pitch) photovoltaic tracking system equipped with high-side INA219 I2C current/voltage telemetry, DHT22 climate sensors, and closed-loop battery charging.
Why we built this
Stationary solar panels suffer significant efficiency drops; we built an intelligent dual-axis tracker that maximizes energy capture while monitoring real-time power metrics.
Free technical report & Drive guide available