All Projects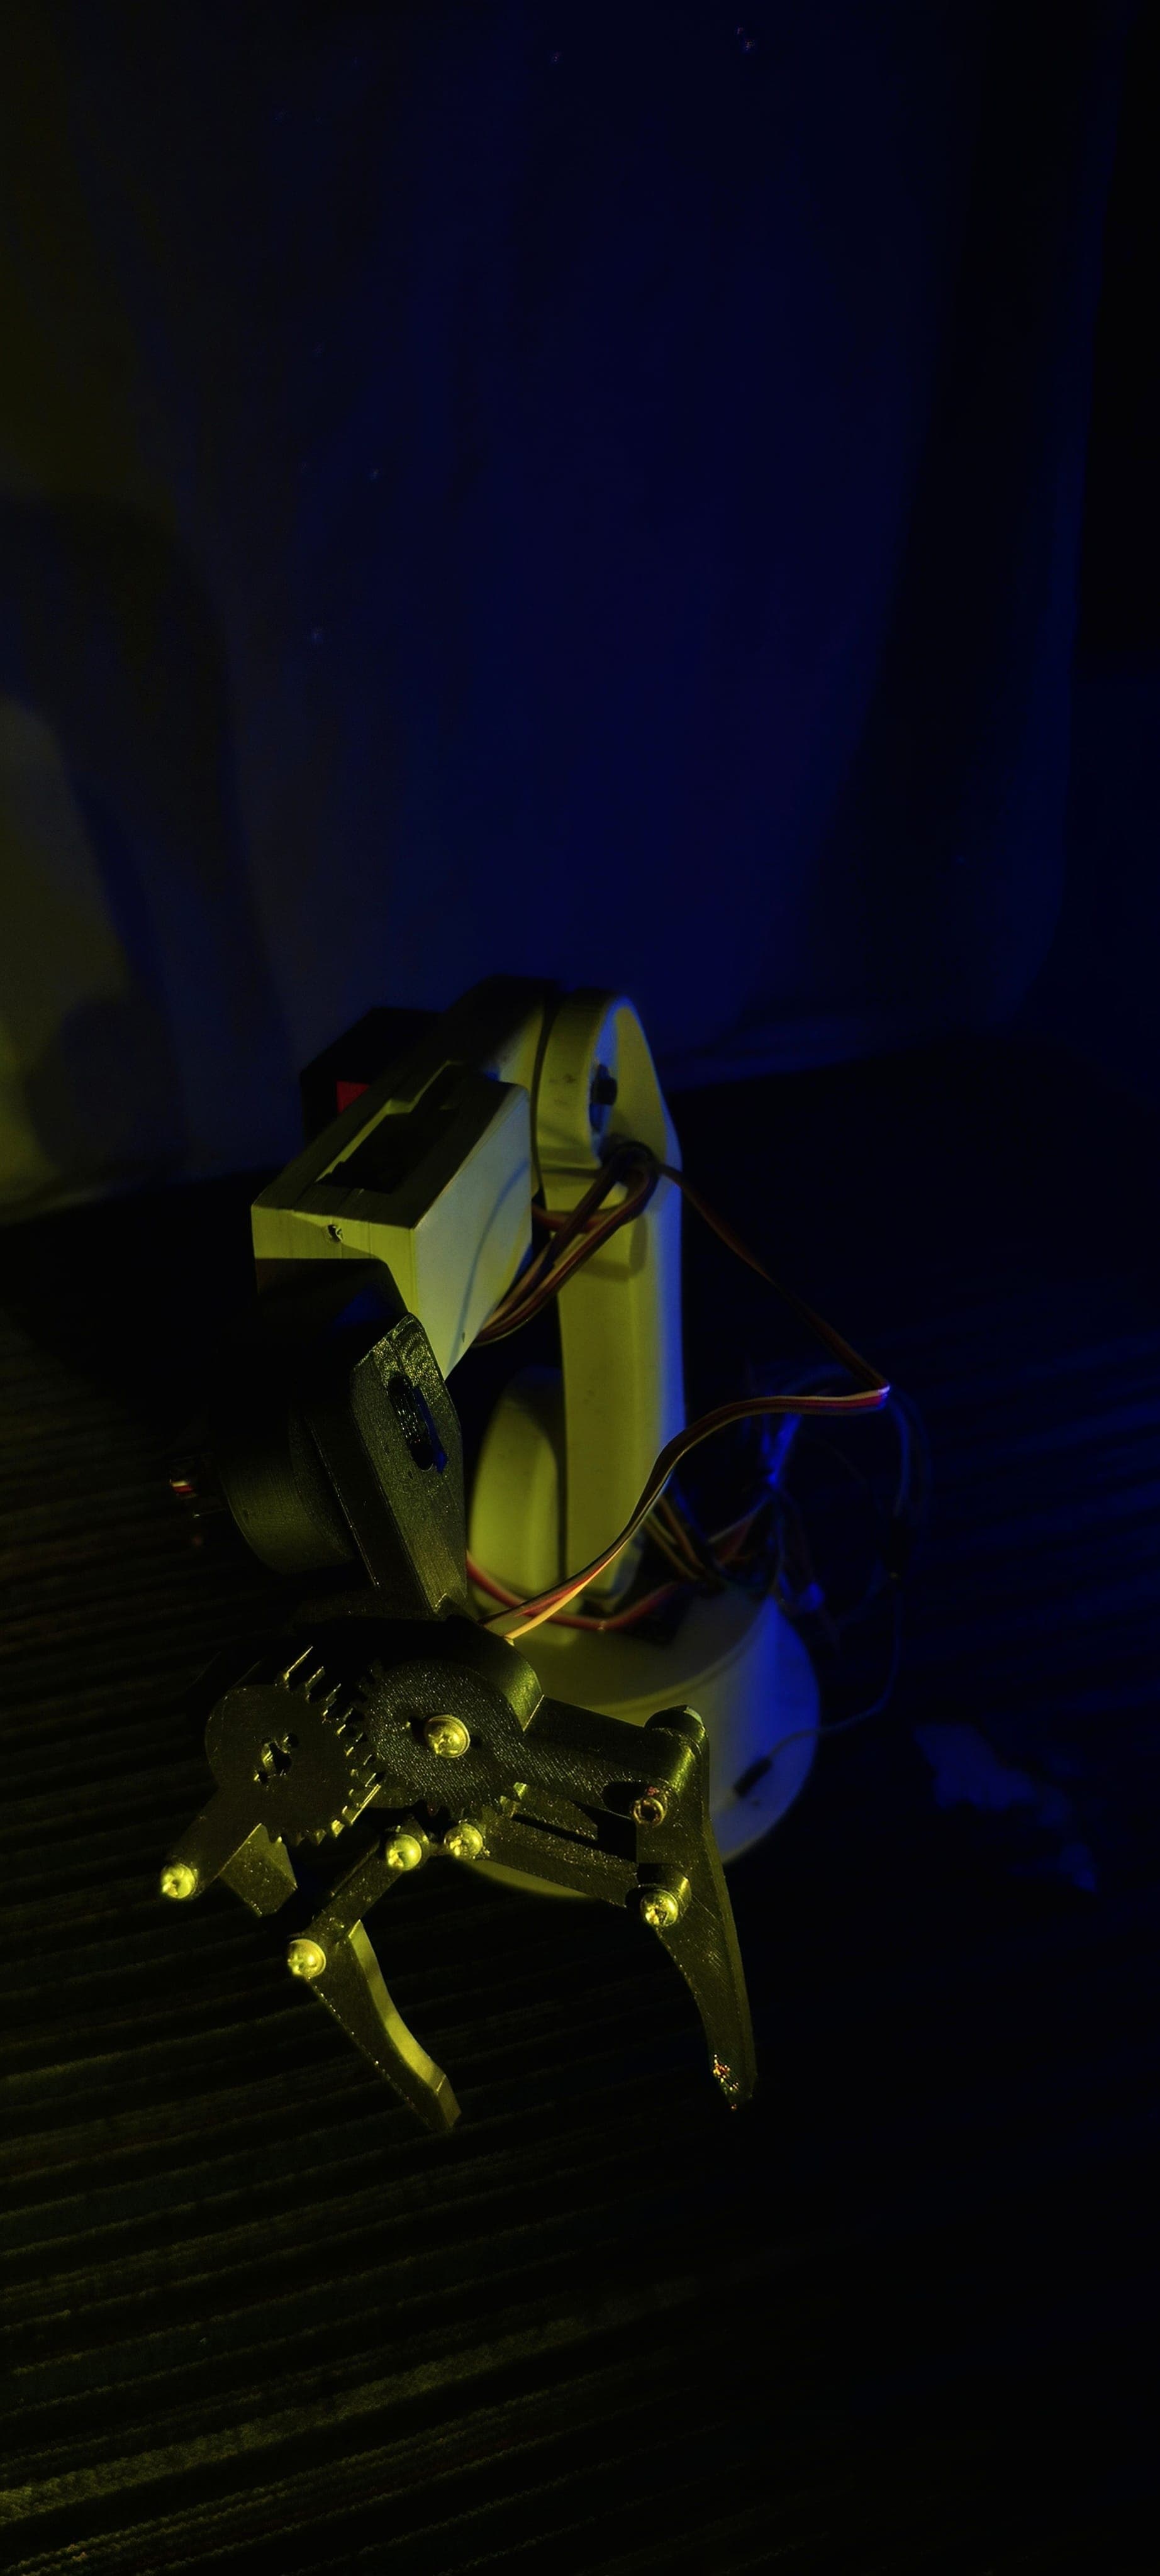
Human-Machine InterfaceYear 2026
6-DOF CyberDeck & 5-DOF Teach-Repeat Robotic Arm
Industrial-grade 6-DOF & 5-DOF robotic manipulation systems featuring OpenCV AI vision hand tracking, Flask-SocketIO web control, and teach-repeat trajectory playback.
PythonFlask-SocketIOOpenCVMediaPipeArduino C++I2C Bus
6-DOF CyberDeck robotic manipulator assembly
Overview
Our robotic arm platform integrates two advanced control architectures: a 6-DOF OpenCV MediaPipe hand gesture tracking controller communicating via Flask-SocketIO to a PCA9685 I2C PWM driver, and a 5-DOF Teach & Repeat system. The software incorporates cubic Hermite polynomial (Smoothstep) trajectory interpolation and Exponential Moving Average (EMA) noise filtering to deliver fluid, jerk-free mechanical arm movement.
Highlights
- Real-time OpenCV + MediaPipe 6-DOF hand tracking controller
- Flask-SocketIO web dashboard with interactive joint matrix sliders
- PCA9685 16-channel 12-bit PWM I2C servo driver abstraction
- Teach & Repeat RAM waypoint recording with Smoothstep Hermite interpolation
The Challenge
Fitting 100 5-DOF spatial waypoints into the constrained 2KB SRAM of the ATmega328P was solved by optimizing joint structures into compact uint8_t byte arrays.
The Outcome
Delivered a fluid, multi-modal robotic manipulator capable of vision-controlled sorting and automated pick-and-place playback.
Project Media & Build Gallery
[7 PHOTOS]6-DOF CyberDeck robotic manipulator assembly
More Projects
 Renewable Energy Systems
2026
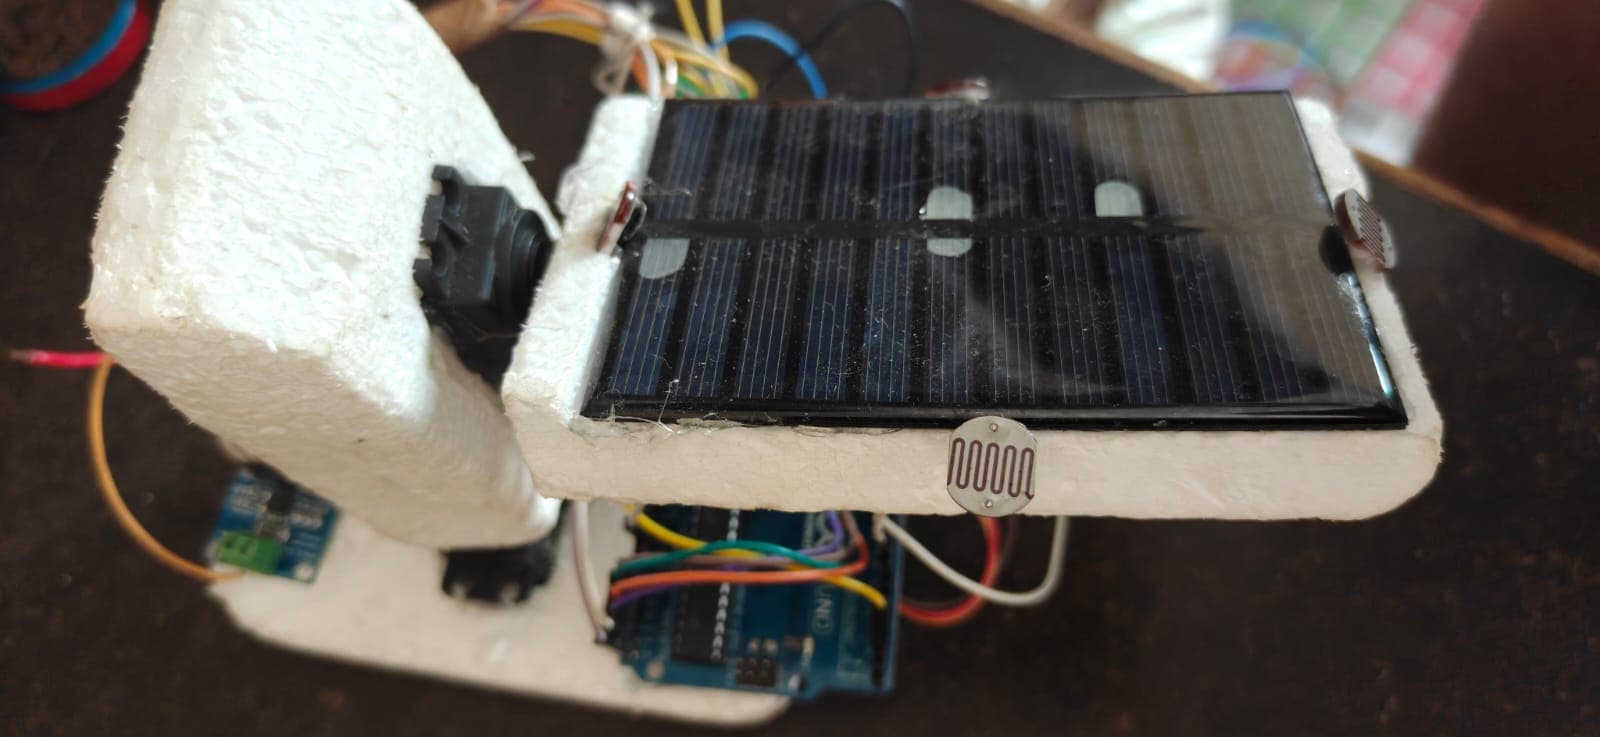
Dual-Axis Solar Tracking & Energy Management System
A dual-axis (Yaw & Pitch) photovoltaic tracking system equipped with high-side INA219 I2C current/voltage telemetry, DHT22 climate sensors, and closed-loop battery charging.
Why we built this
Stationary solar panels suffer significant efficiency drops; we built an intelligent dual-axis tracker that maximizes energy capture while monitoring real-time power metrics.
Free technical report & Drive guide available
 IoT & Embedded Systems
2026
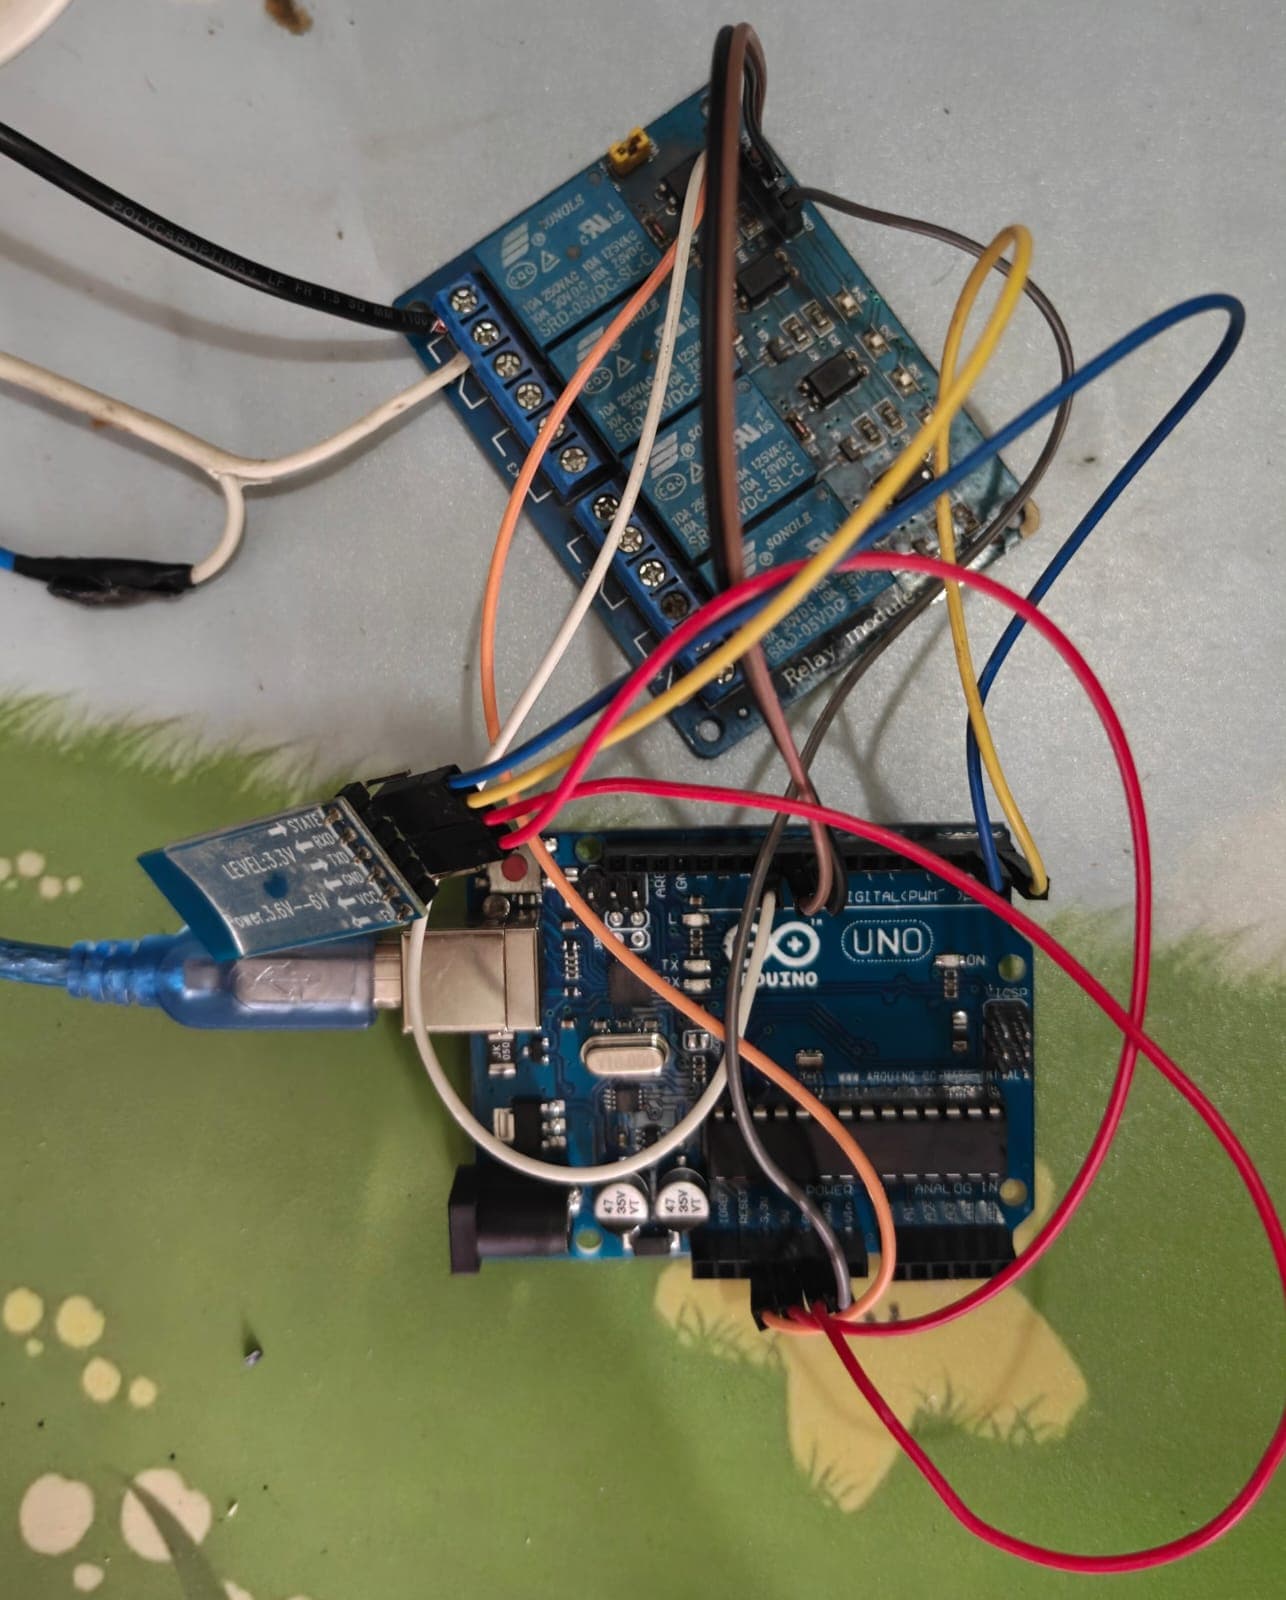
Smart Home Automation & IoT Energy Hub
A modular ESP32-powered home automation controller supporting multi-channel relay switching, MQTT telemetry, local web dashboard, and physical wall switch overrides.
Why we built this
Modern home automation proprietary hubs are expensive; we engineered a low-cost, open-hardware controller with fallback physical wall switches.
Free technical report & Drive guide available
 Competitive Robotics
2026
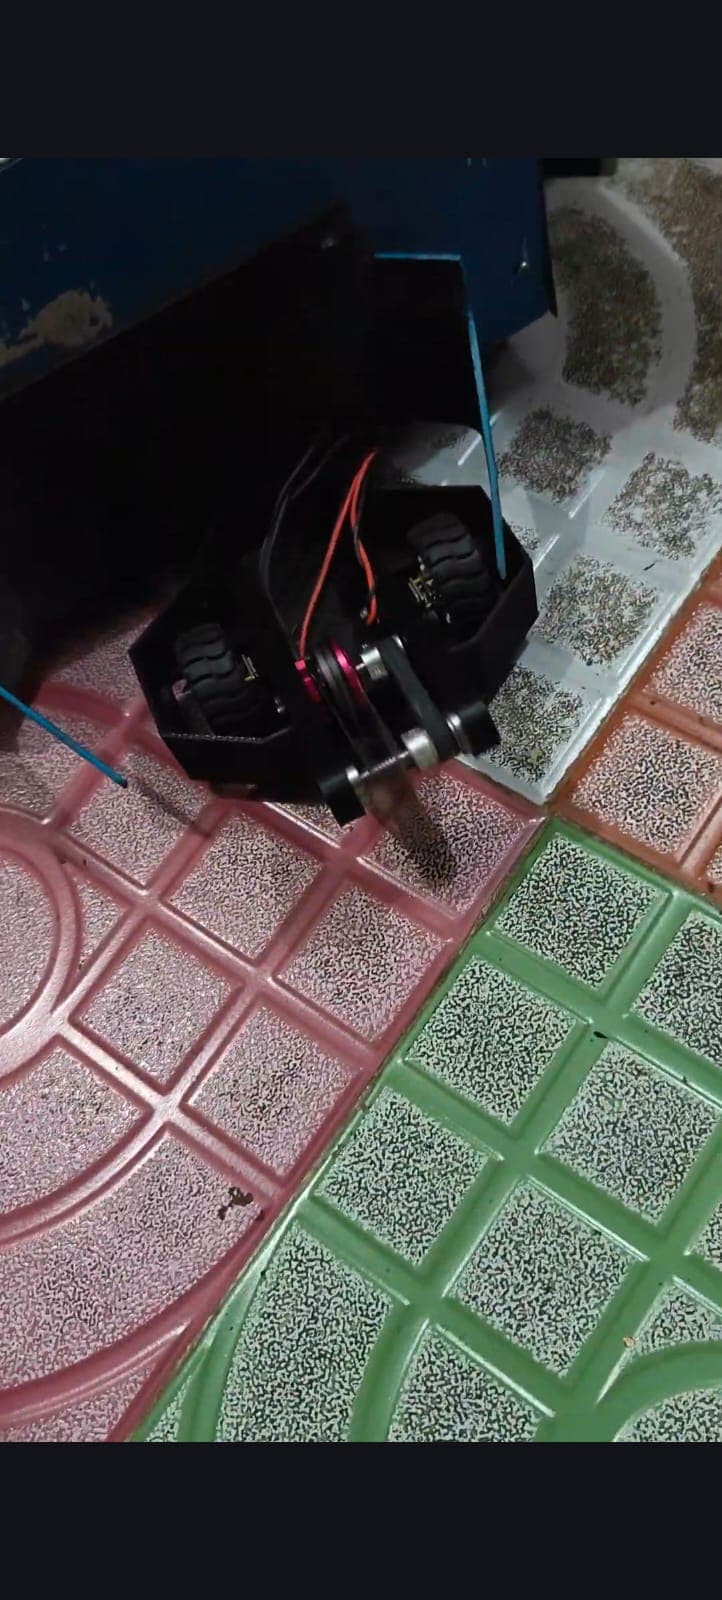
High-Impact Combat BattleBot
A heavy-duty combat robot with an armor-plated chassis, high-torque dual H-bridge differential drive, and high-RPM active kinetic weapon spinner.
Why we built this
Combat robotics teaches extreme mechanical stress tolerance, impact dynamics, and high-current electrical safety under competition conditions.
Free technical report & Drive guide available