Aerial RoboticsYear 2026Completed
F450 Autonomous Quadcopter Drone
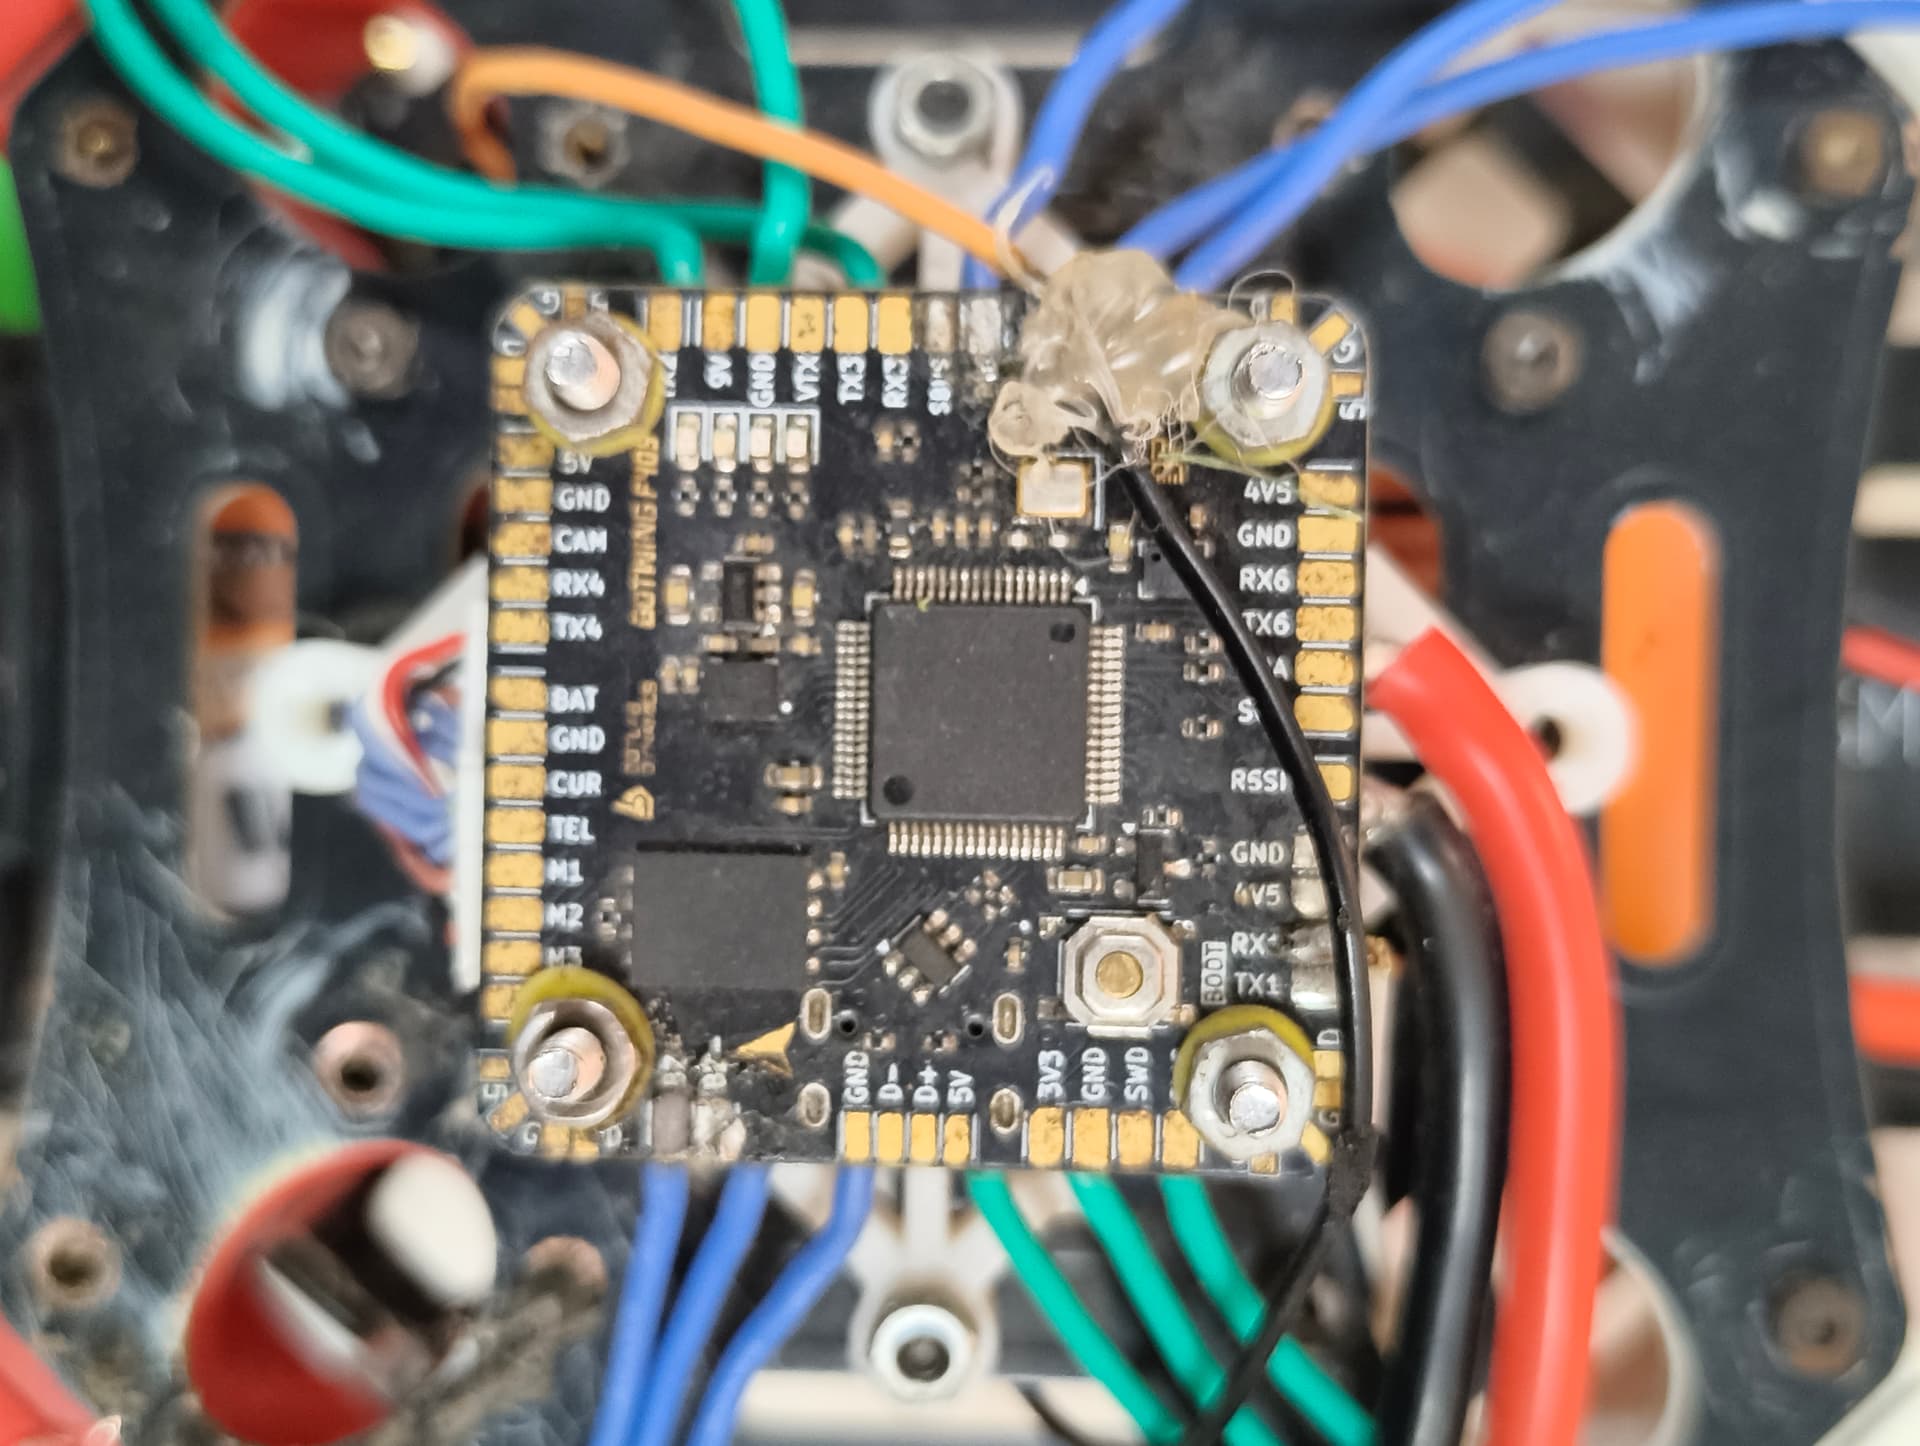
A custom-built F450 quadcopter drone featuring an STM32 F405 flight controller running INAV, 1000KV brushless motors, 1045 propellers, and 2.4GHz FlySky FS-i6 telemetry control.
AerodynamicsAvionicsINAV FirmwareBrushless DCPID Flight ControlTelemetry
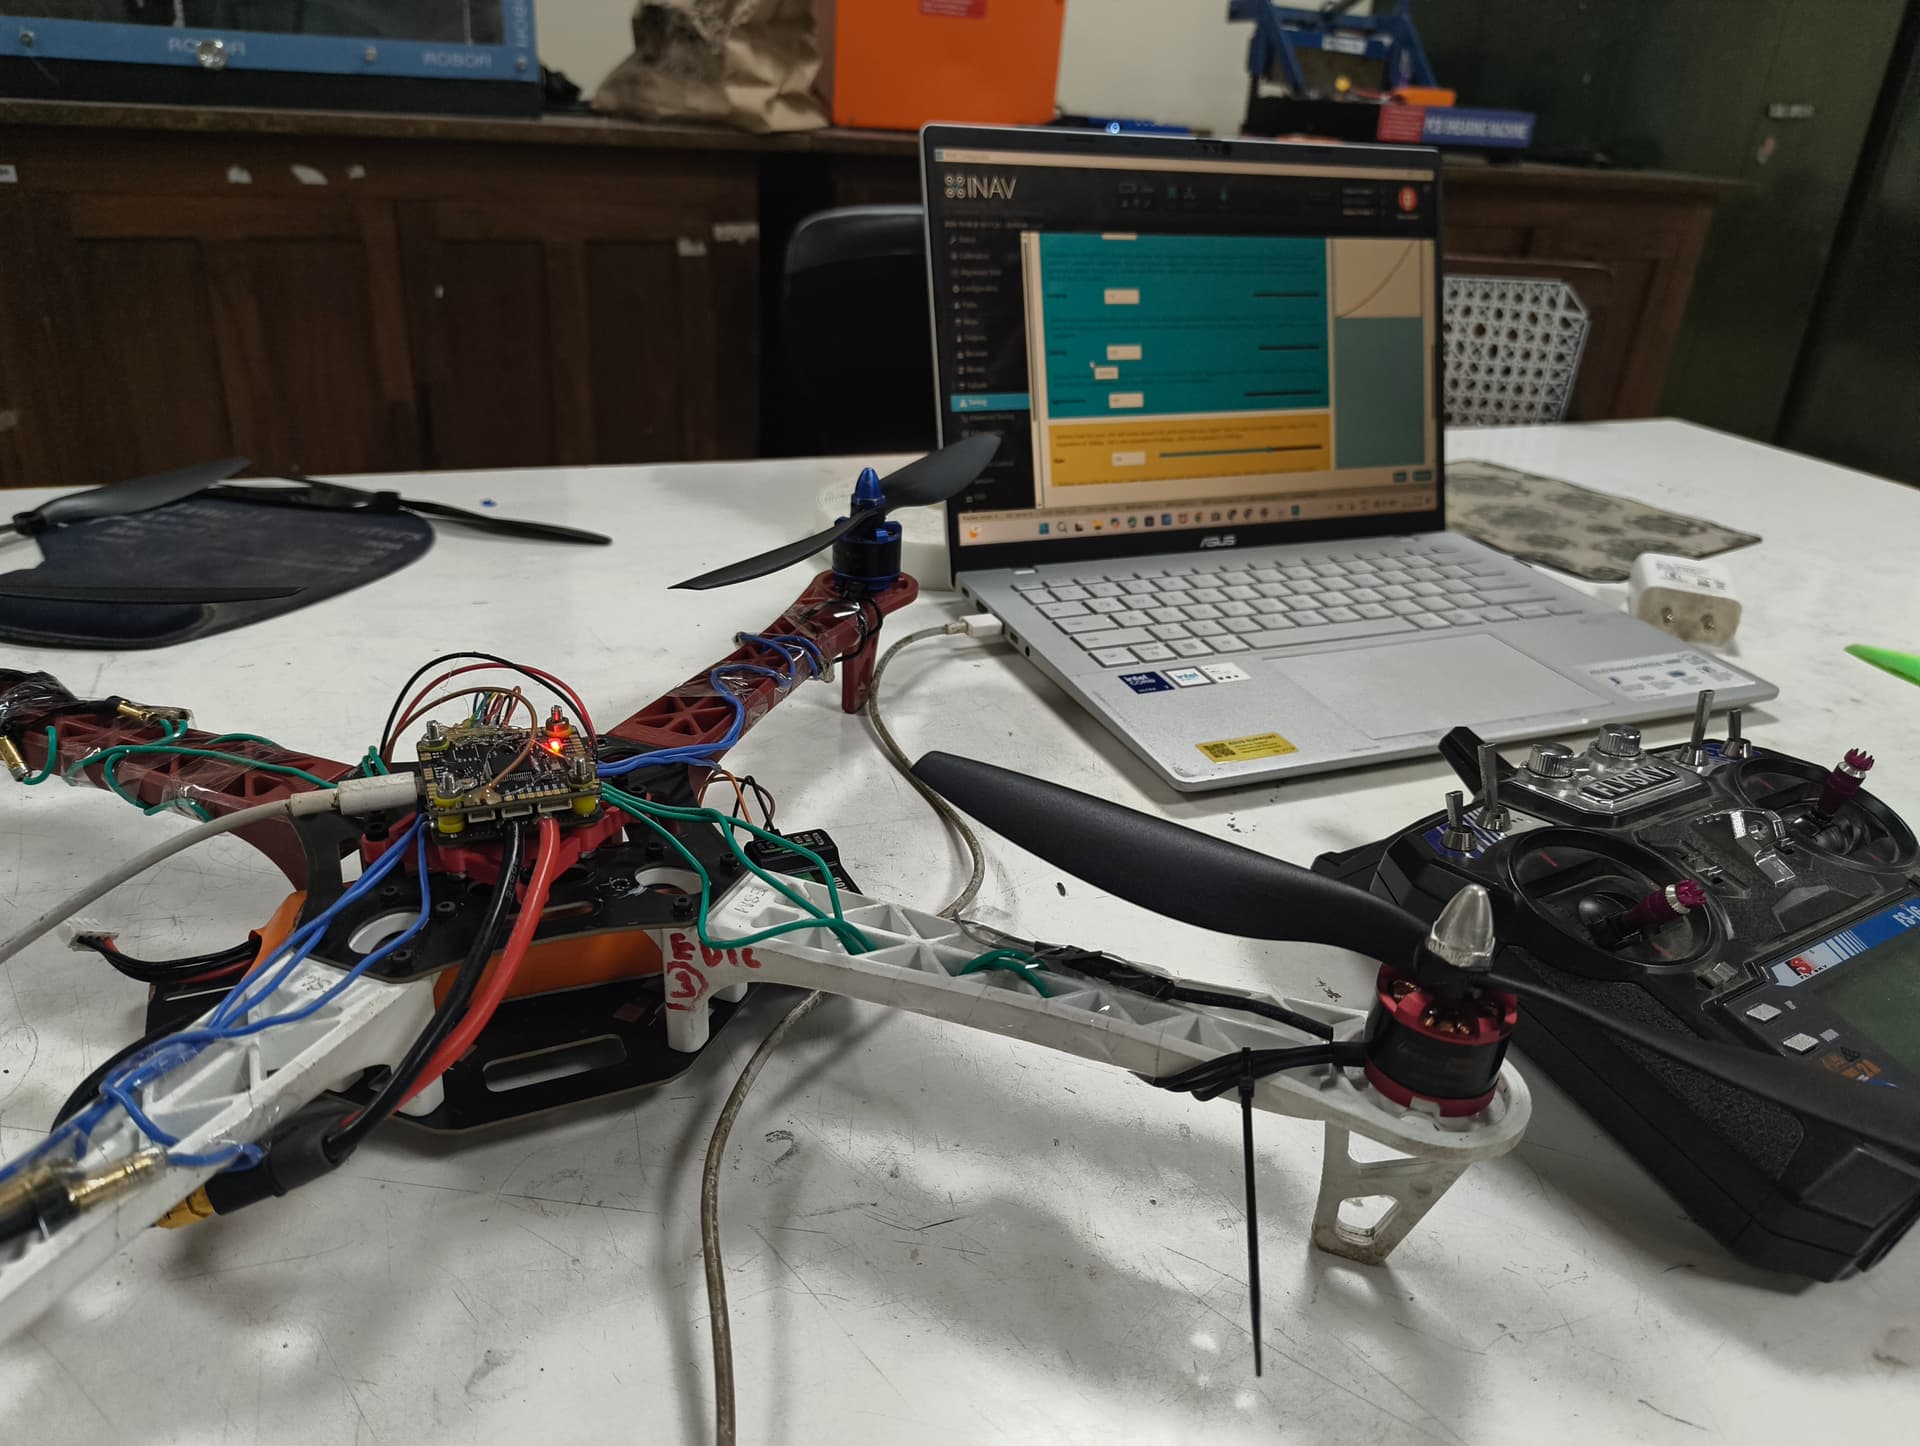
1 / 5
INAV configurator telemetry test with FlySky FS-i6 radio transmitter & 1045 props
Why We Built This
Commercial ready-to-fly drones hide flight mechanics behind proprietary black boxes; we engineered an open-platform F450 quadcopter from component level so students could master flight dynamics, PID attitude tuning, and avionics.
Overview
Engineered around an F450 glass-fiber reinforced multirotor frame, this quadcopter features an STM32 F405 flight controller with integrated high-rate gyro/accelerometer, vibration dampeners, and INAV flight firmware. Powered by four high-thrust brushless outrunner motors regulated by 30A ESCs and high-efficiency 1045 propellers, the aircraft communicates with a FlySky FS-i6 2.4GHz radio transceiver and provides configurable flight stabilization modes.
Highlights & Key Features
- F450 multirotor airframe with high-strength composite arms and integrated PDB
- STM32 F405 flight controller running INAV avionics firmware
- Four high-thrust 2212 1000KV brushless motors with 1045 pitch propellers
- Real-time USB-C telemetry calibration and PID rate tuning in INAV Configurator
- FlySky FS-i6 6-channel 2.4GHz digital proportional RC system
The Challenge
Eliminating motor vibration harmonics to prevent flight controller sensor noise required silicone vibration isolators and precise PID loop filtering.
The Outcome
Achieved rock-solid attitude hold, responsive throttle curves, and successful bench flight telemetry validation.
Build Gallery & Photos
[5 PHOTOS]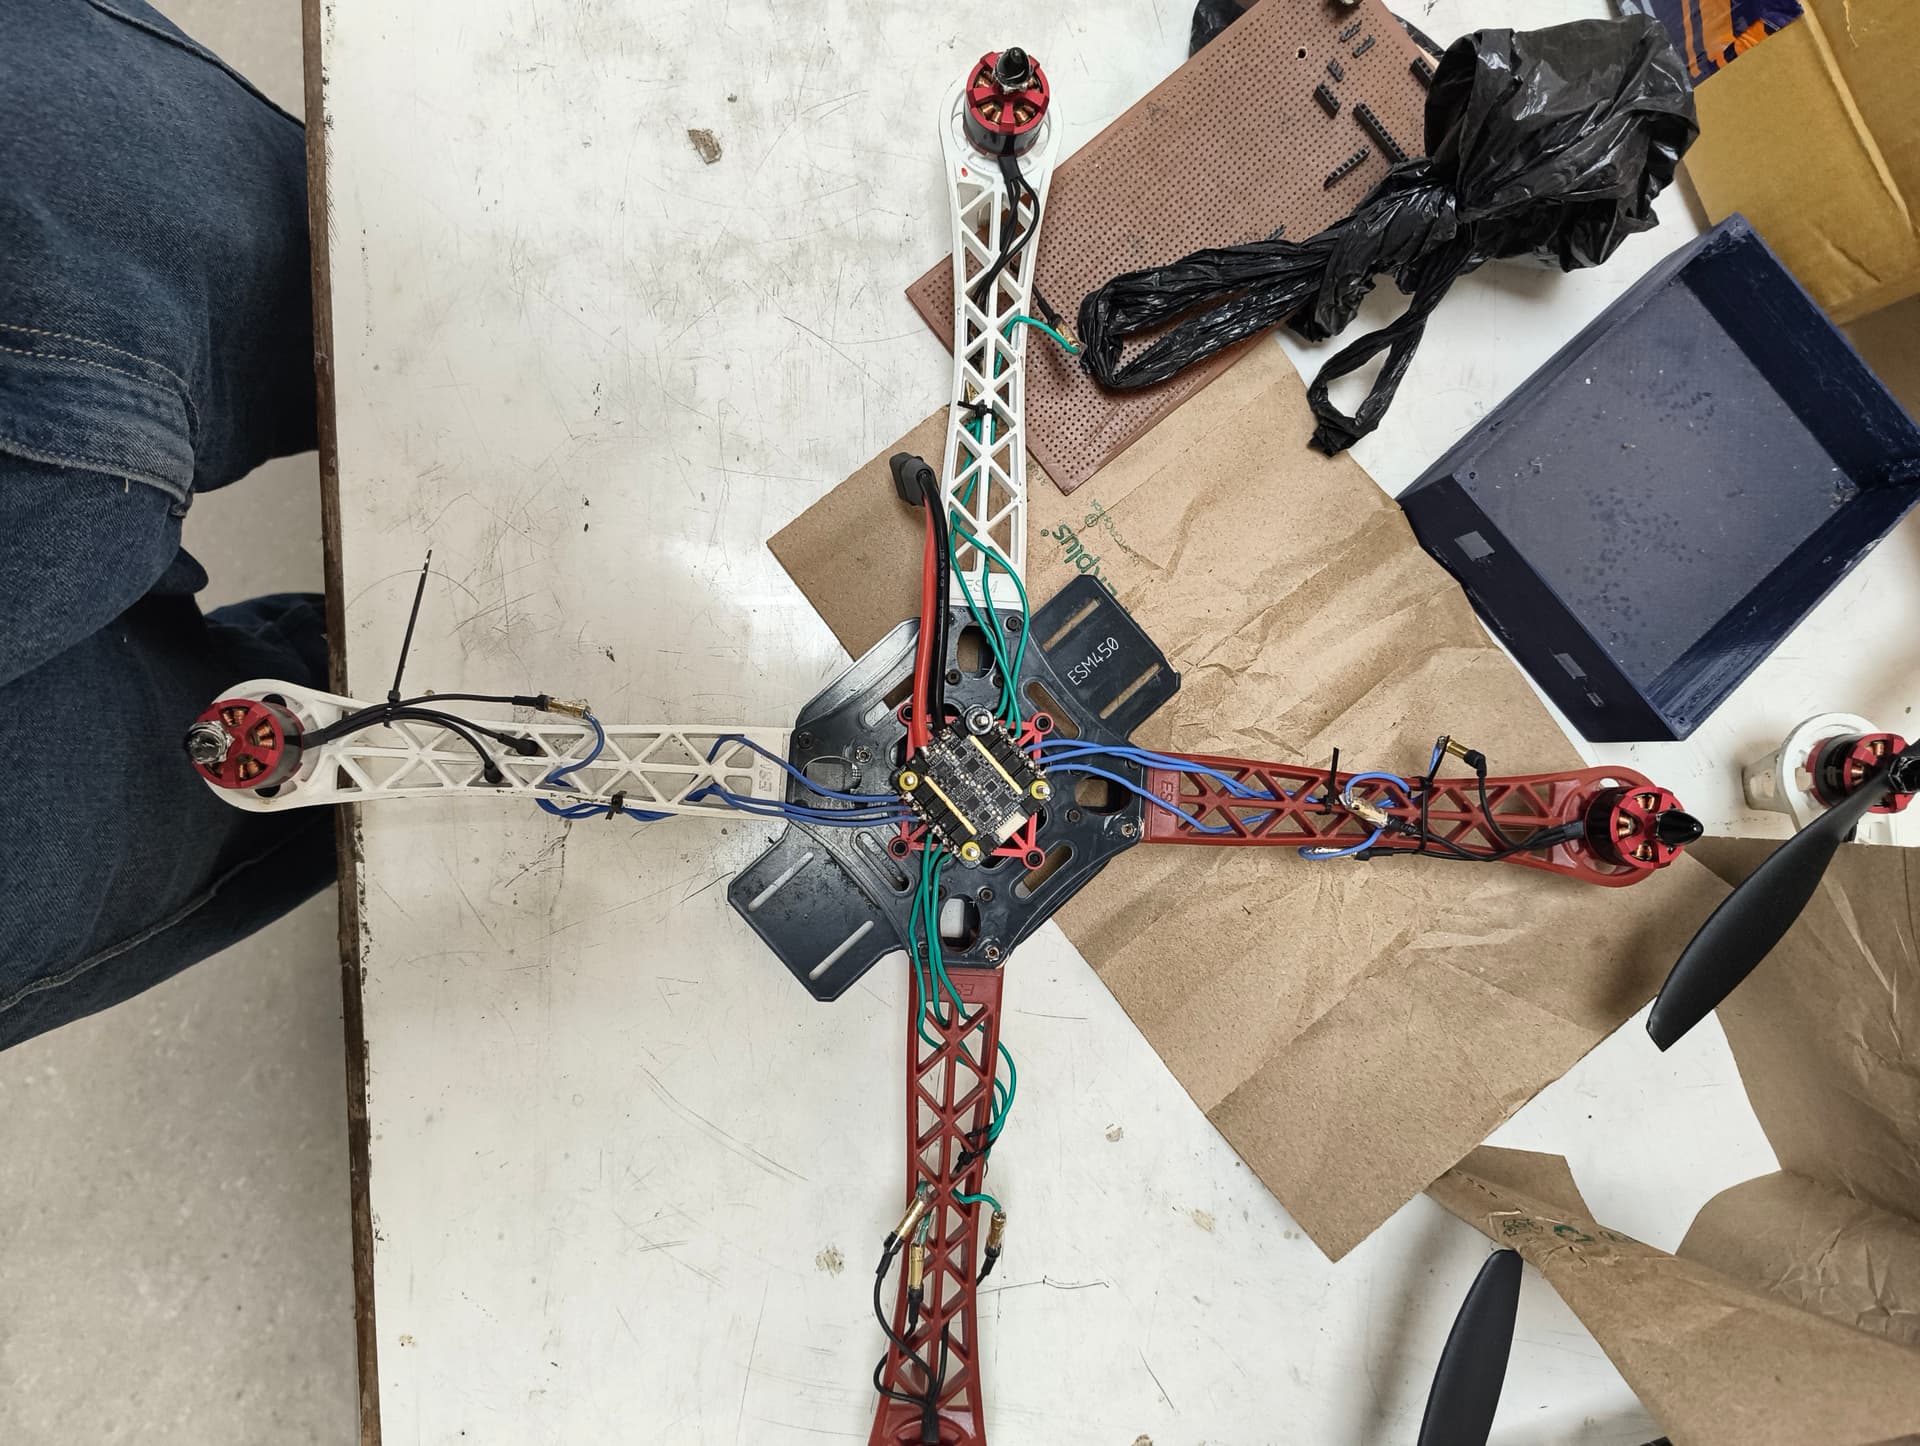
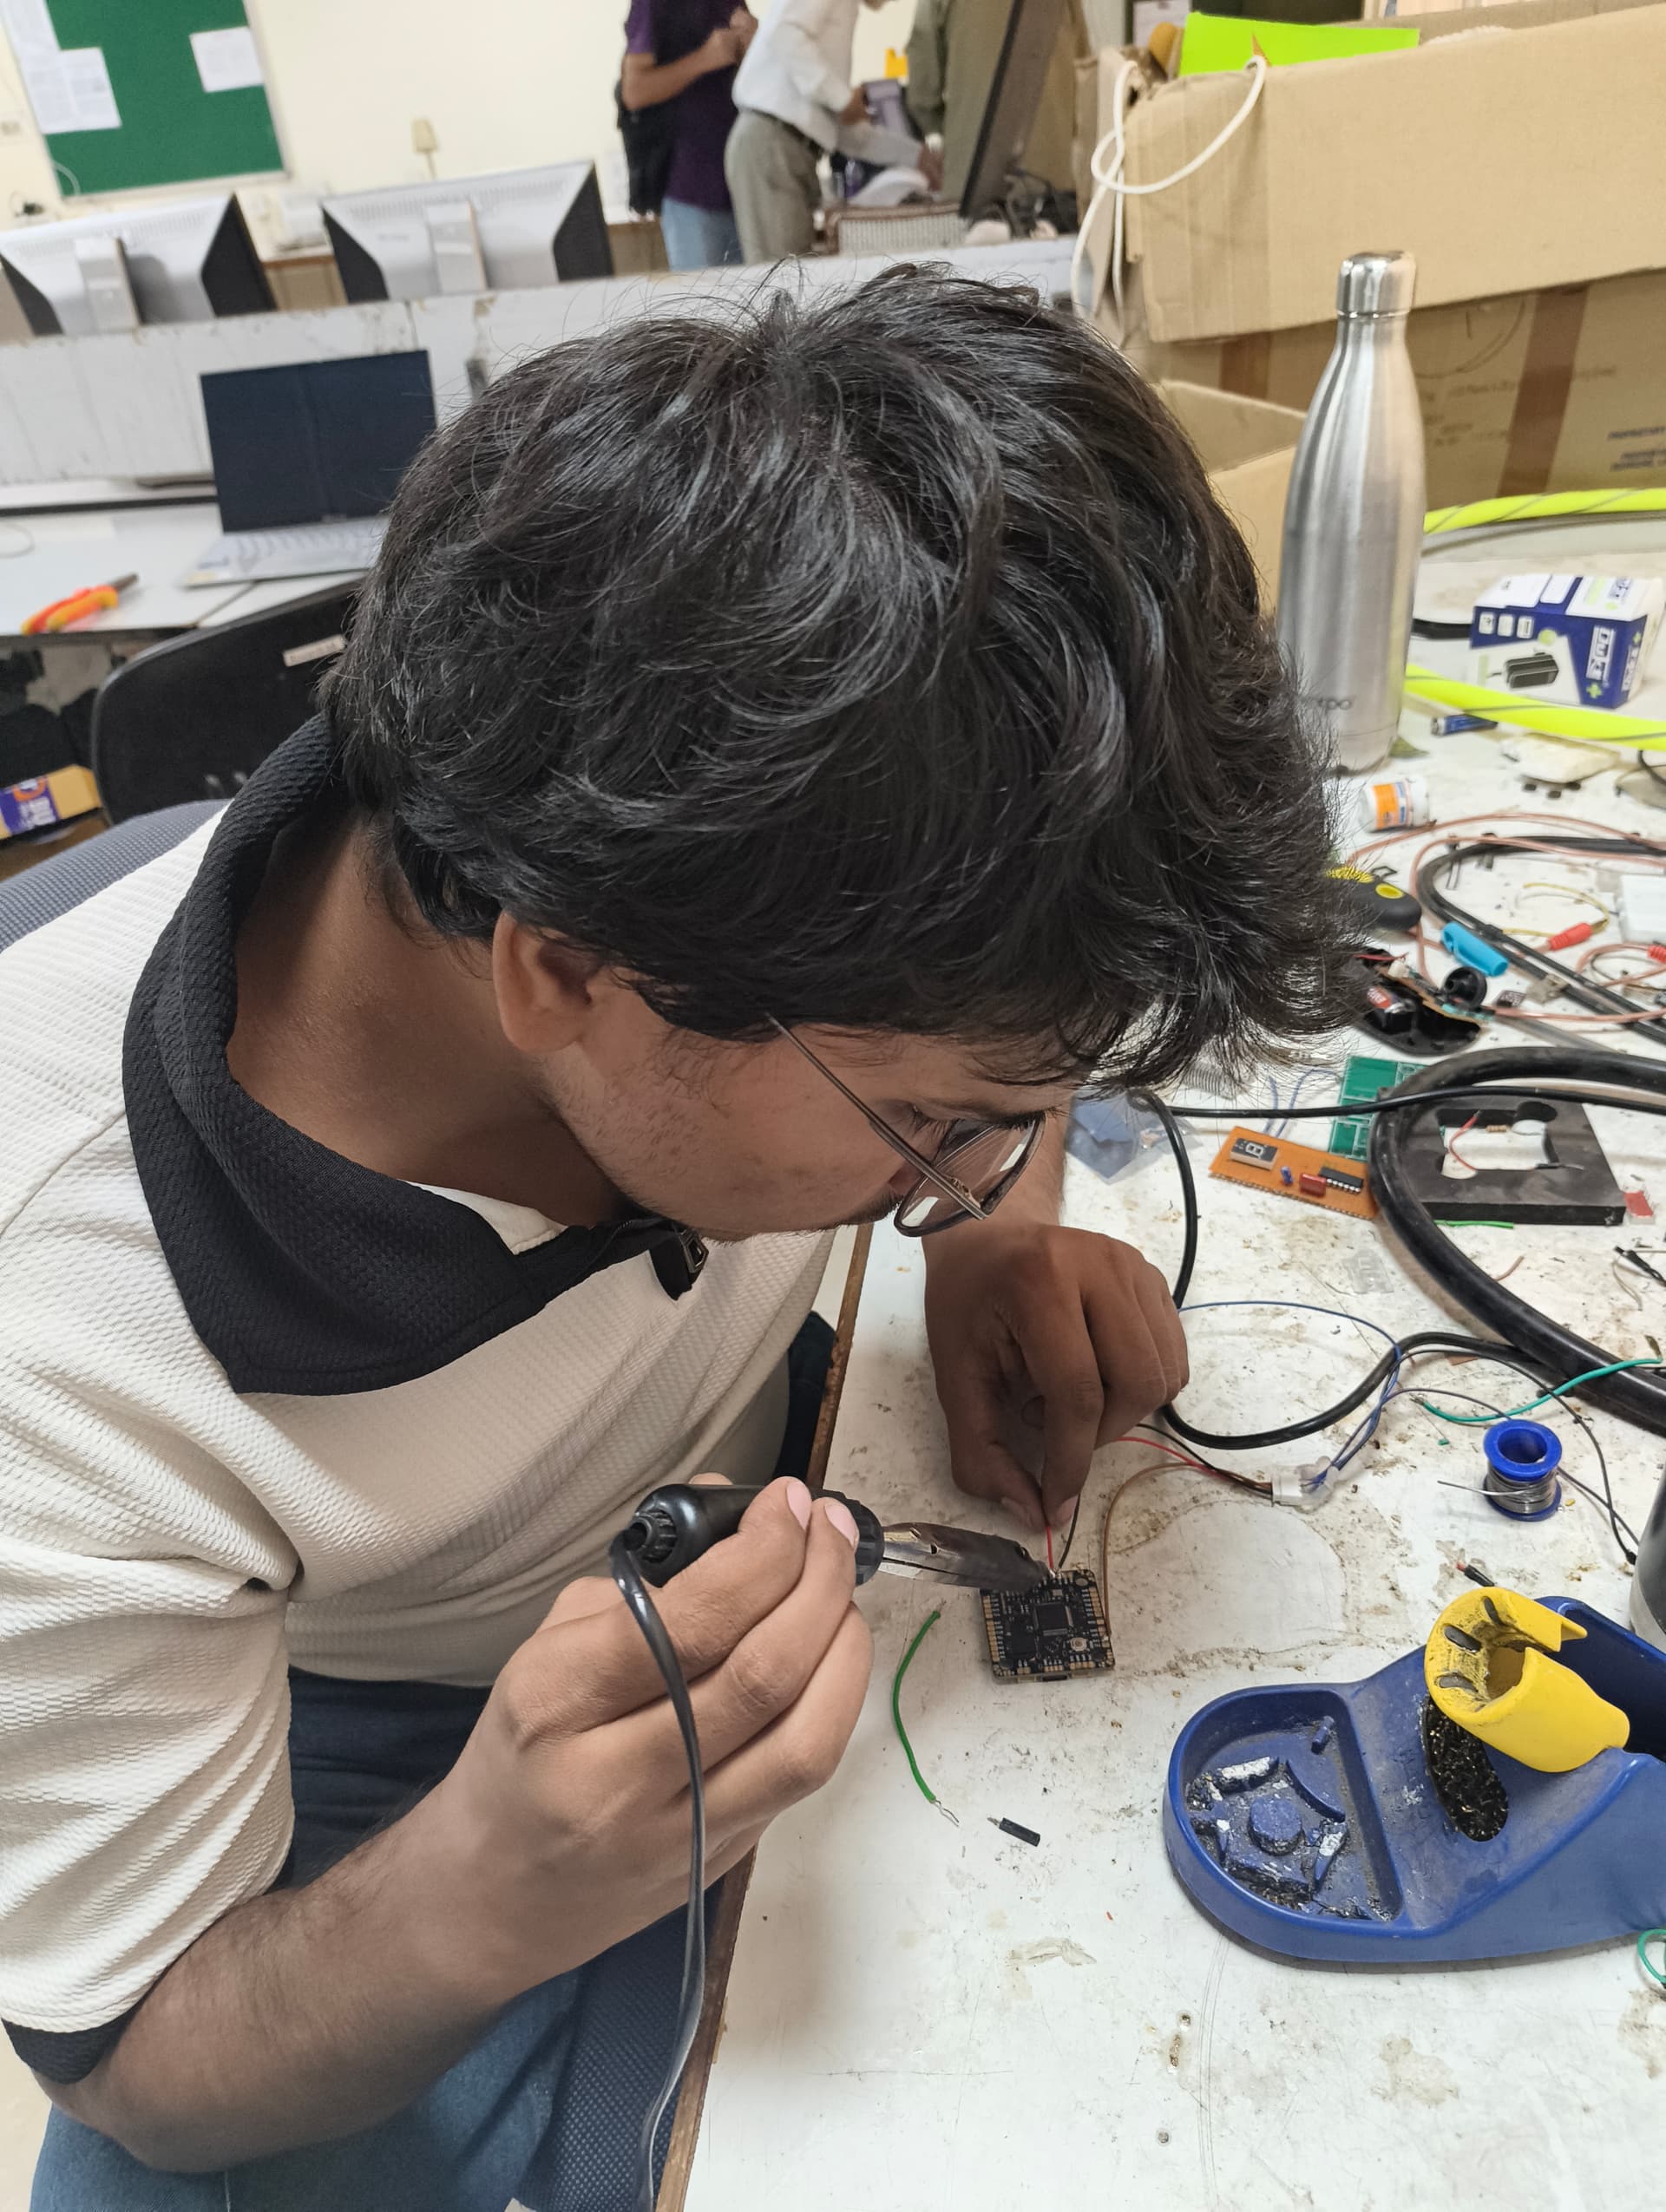
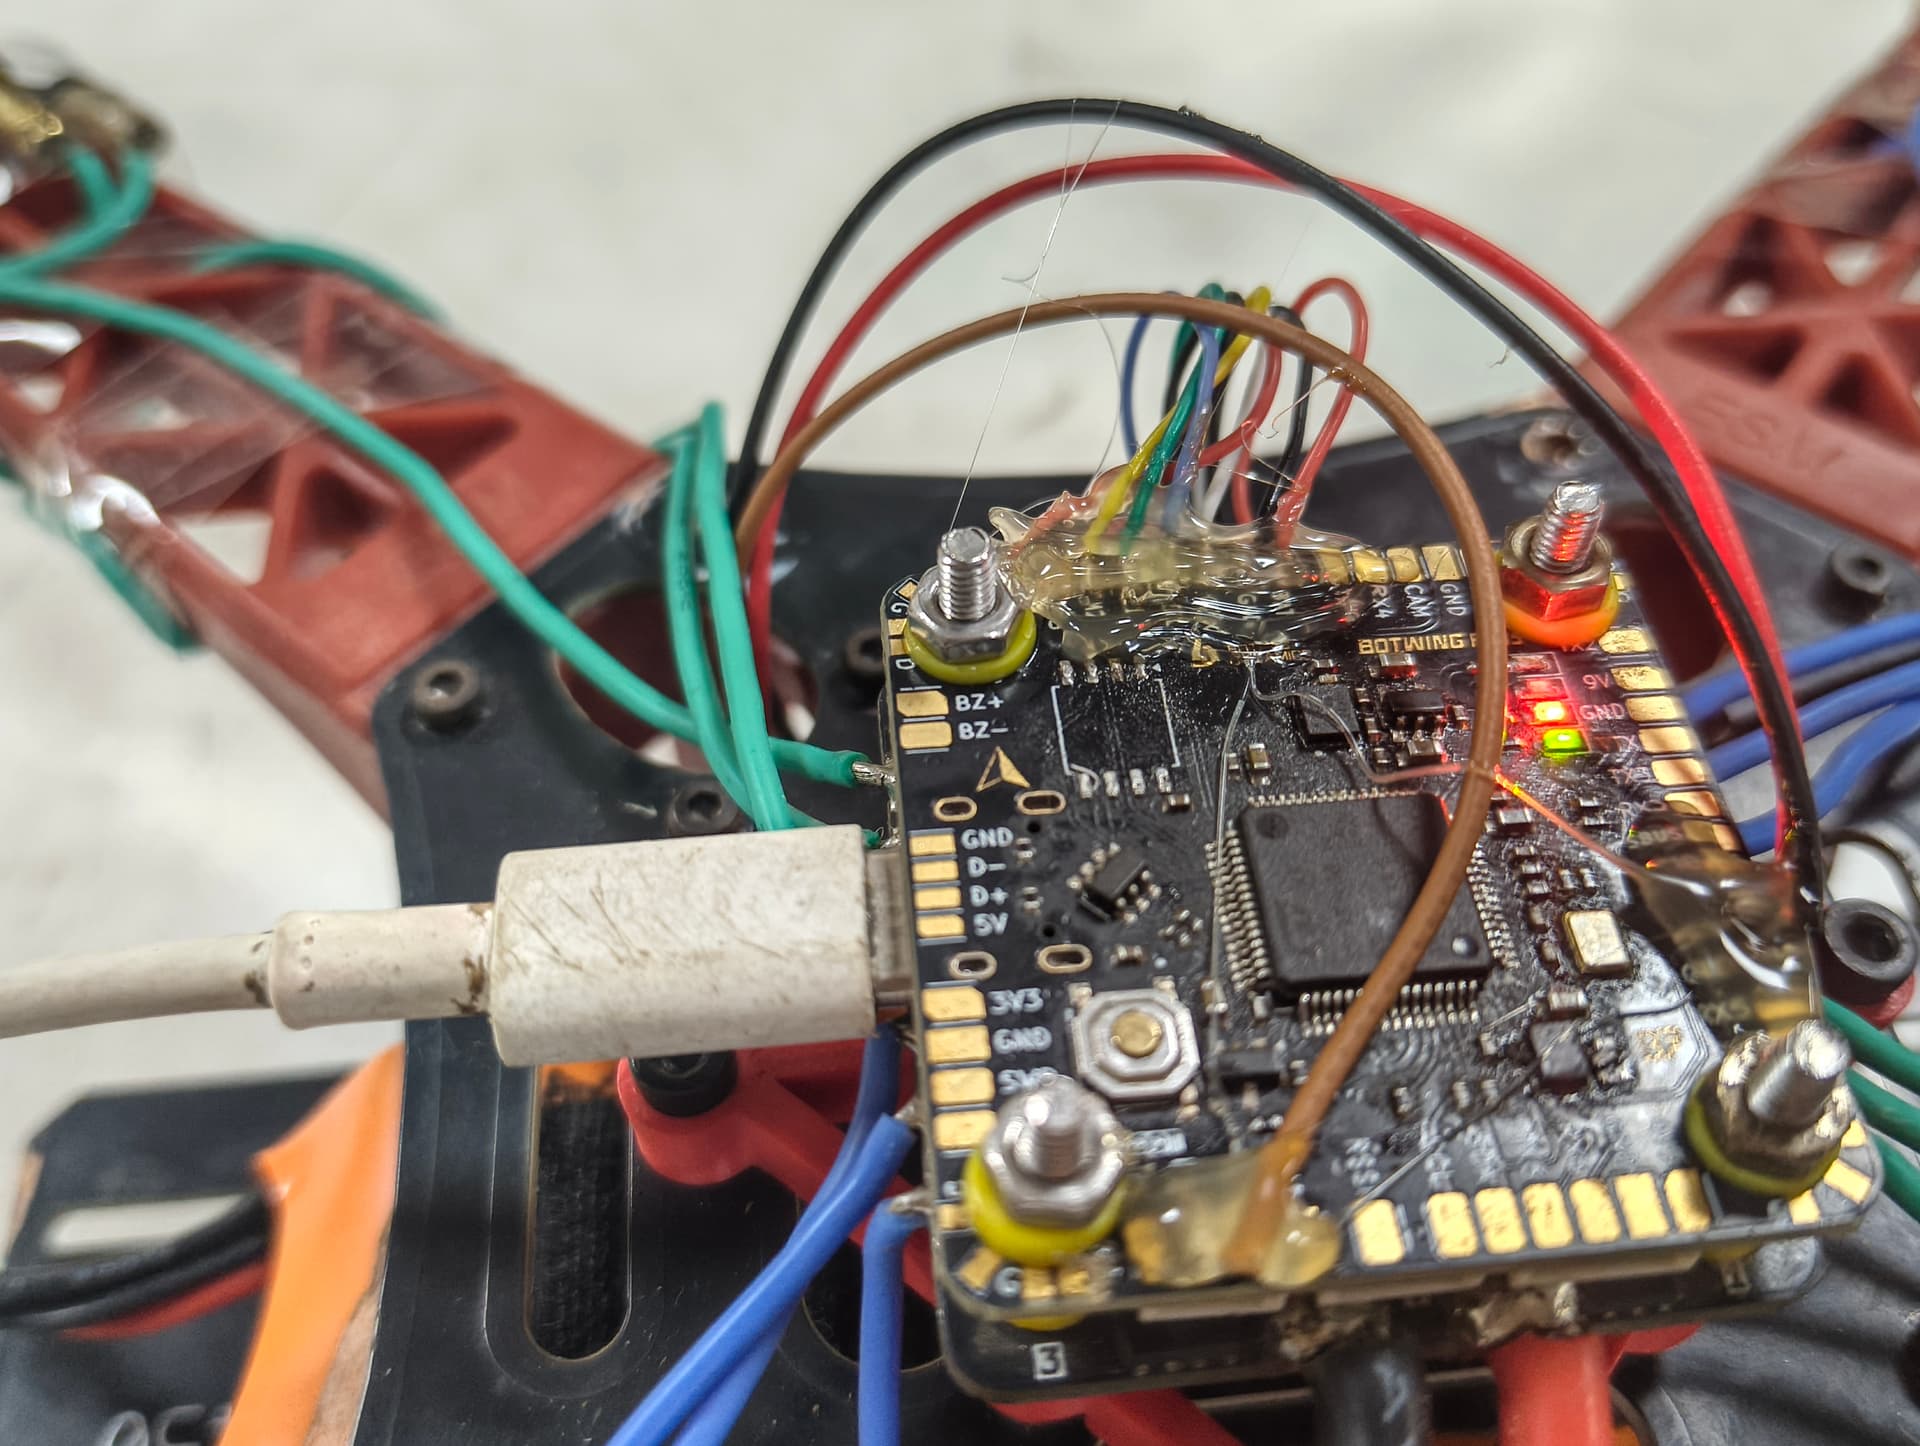
More Projects
 Renewable Energy Systems
2026
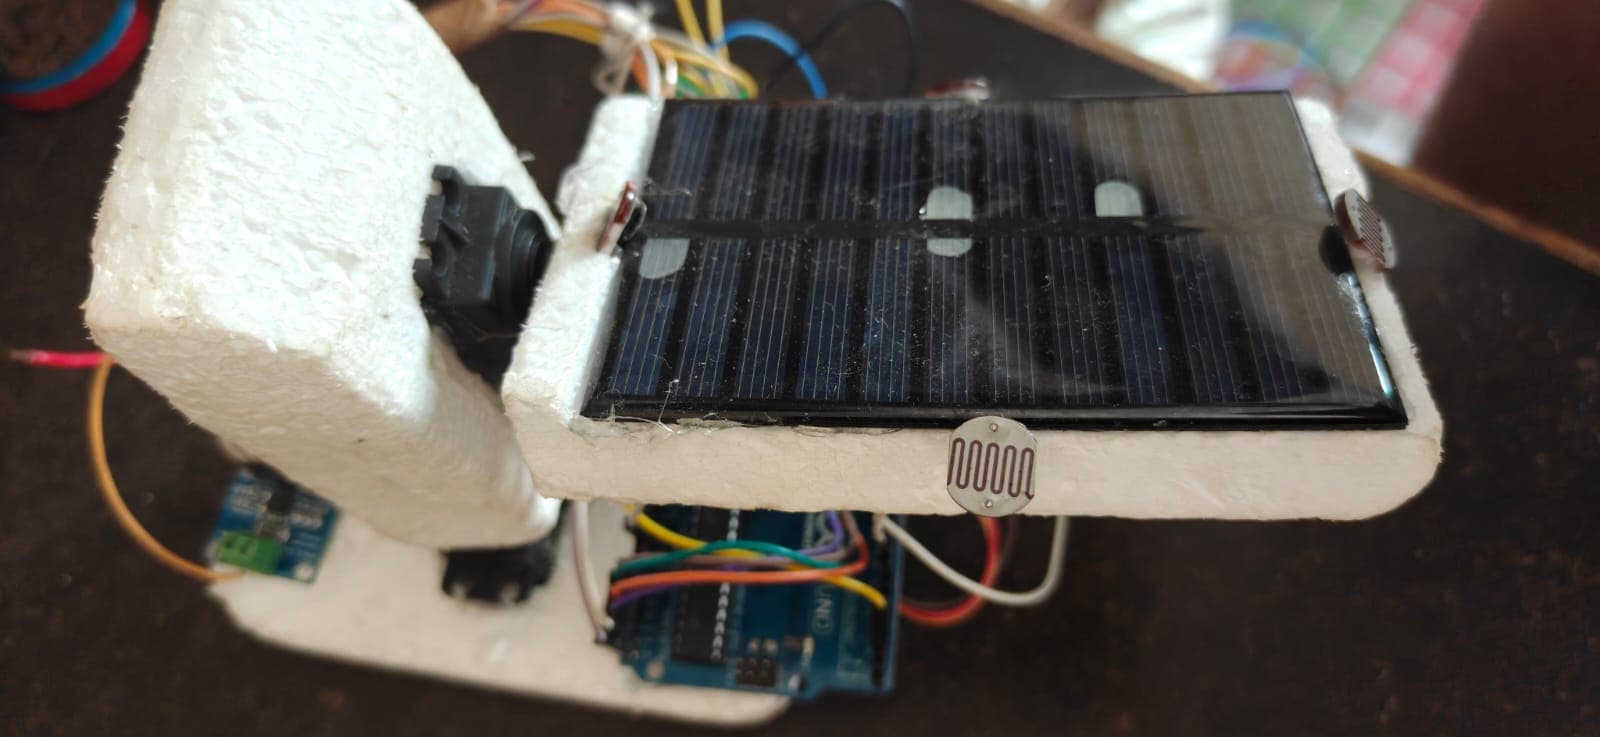
Dual-Axis Solar Tracking & Energy Management System
A dual-axis (Yaw & Pitch) photovoltaic tracking system equipped with high-side INA219 I2C current/voltage telemetry, DHT22 climate sensors, and closed-loop battery charging.
Why we built this
Stationary solar panels suffer significant efficiency drops; we built an intelligent dual-axis tracker that maximizes energy capture while monitoring real-time power metrics.
Free technical report & Drive guide available
 IoT & Embedded Systems
2026
Smart Home Automation & IoT Energy Hub
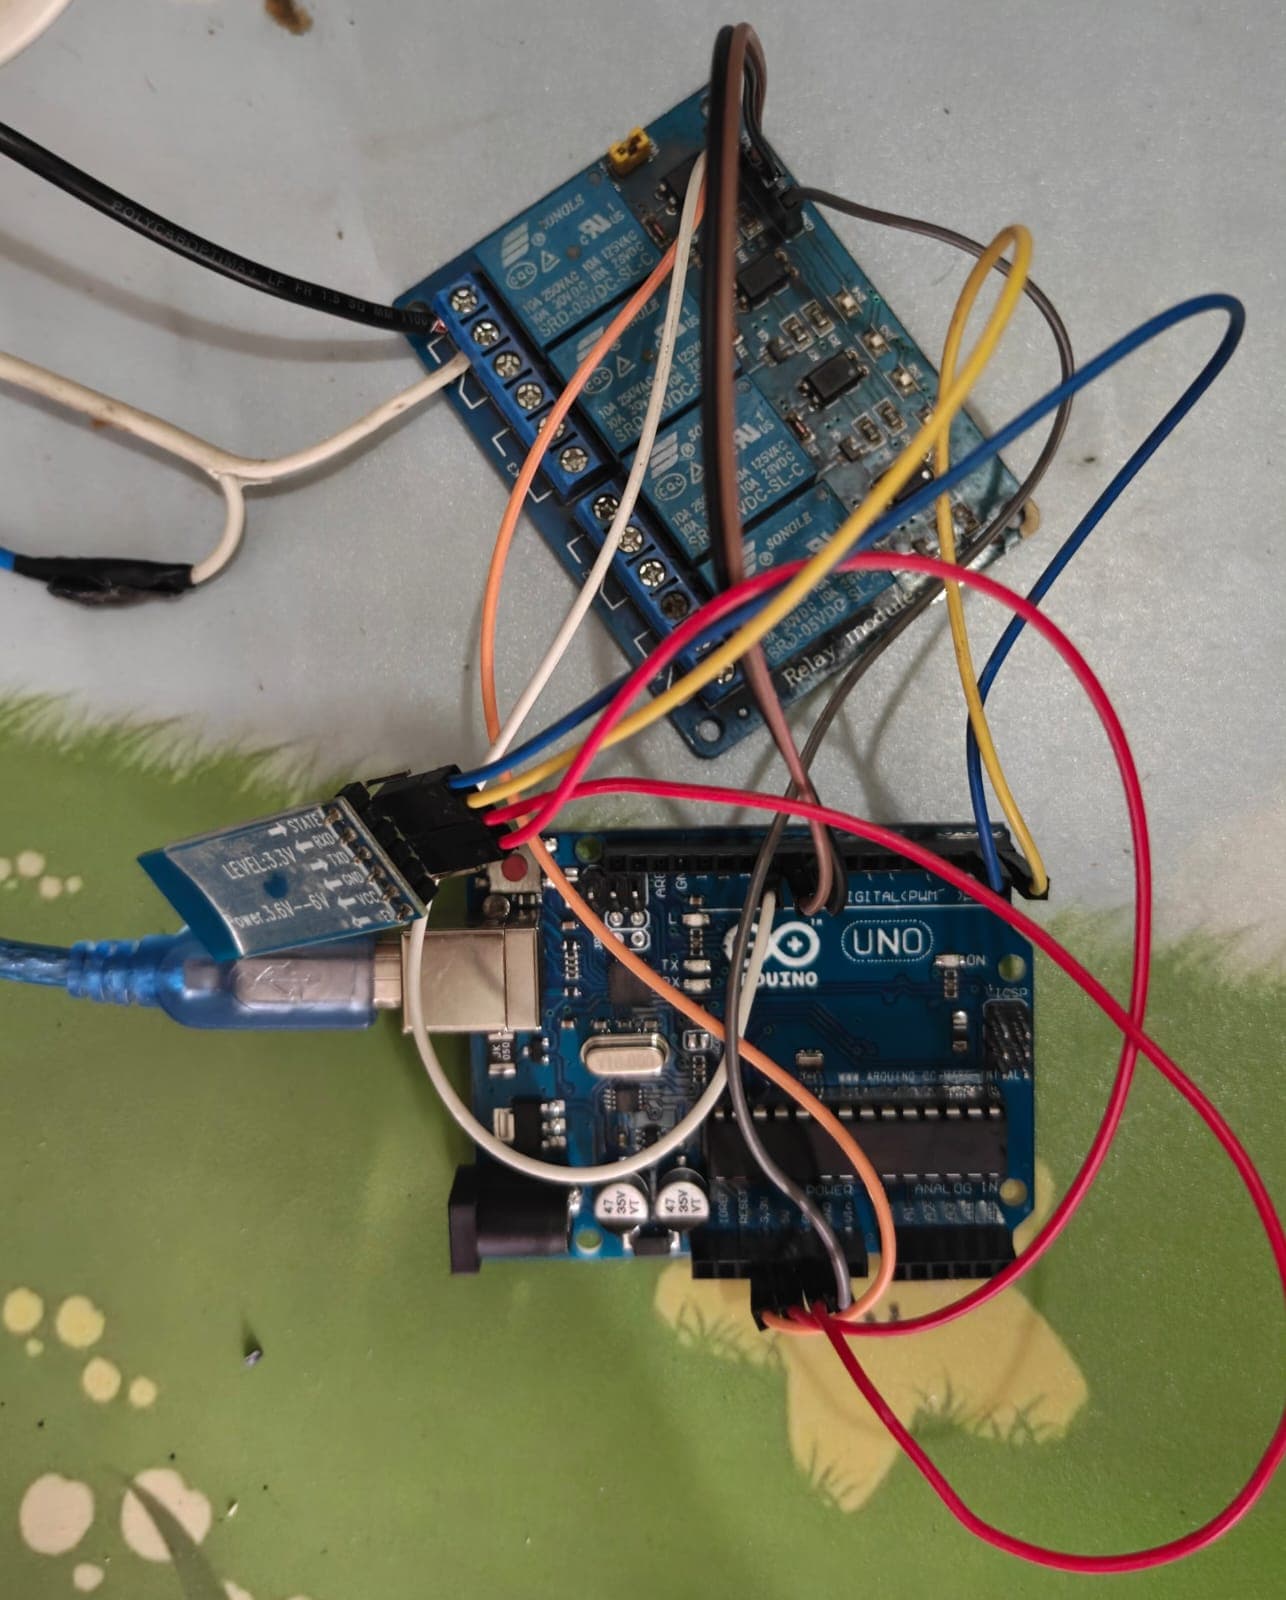
A modular ESP32-powered home automation controller supporting multi-channel relay switching, MQTT telemetry, local web dashboard, and physical wall switch overrides.
Why we built this
Proprietary home-automation hubs are often expensive; we engineered a low-cost, open-hardware controller with fallback physical wall switches.
Free technical report & Drive guide available
 Competitive Robotics
2026
High-Impact Combat BattleBot
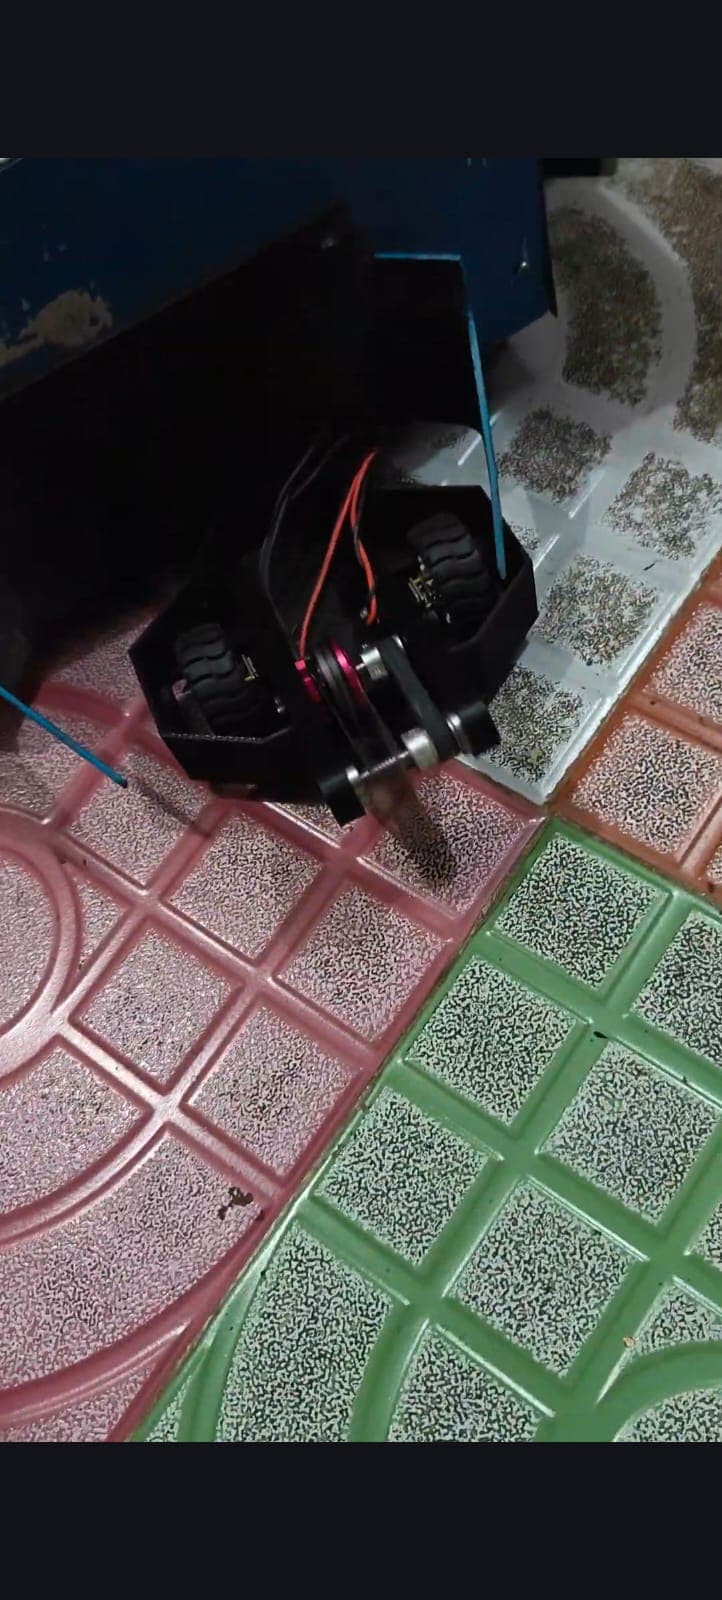
A heavy-duty combat robot with an armor-plated chassis, high-torque dual H-bridge differential drive, and high-RPM active kinetic weapon spinner.
Why we built this
Combat robotics teaches extreme mechanical stress tolerance, impact dynamics, and high-current electrical safety under competition conditions.
Free technical report & Drive guide available