All Projects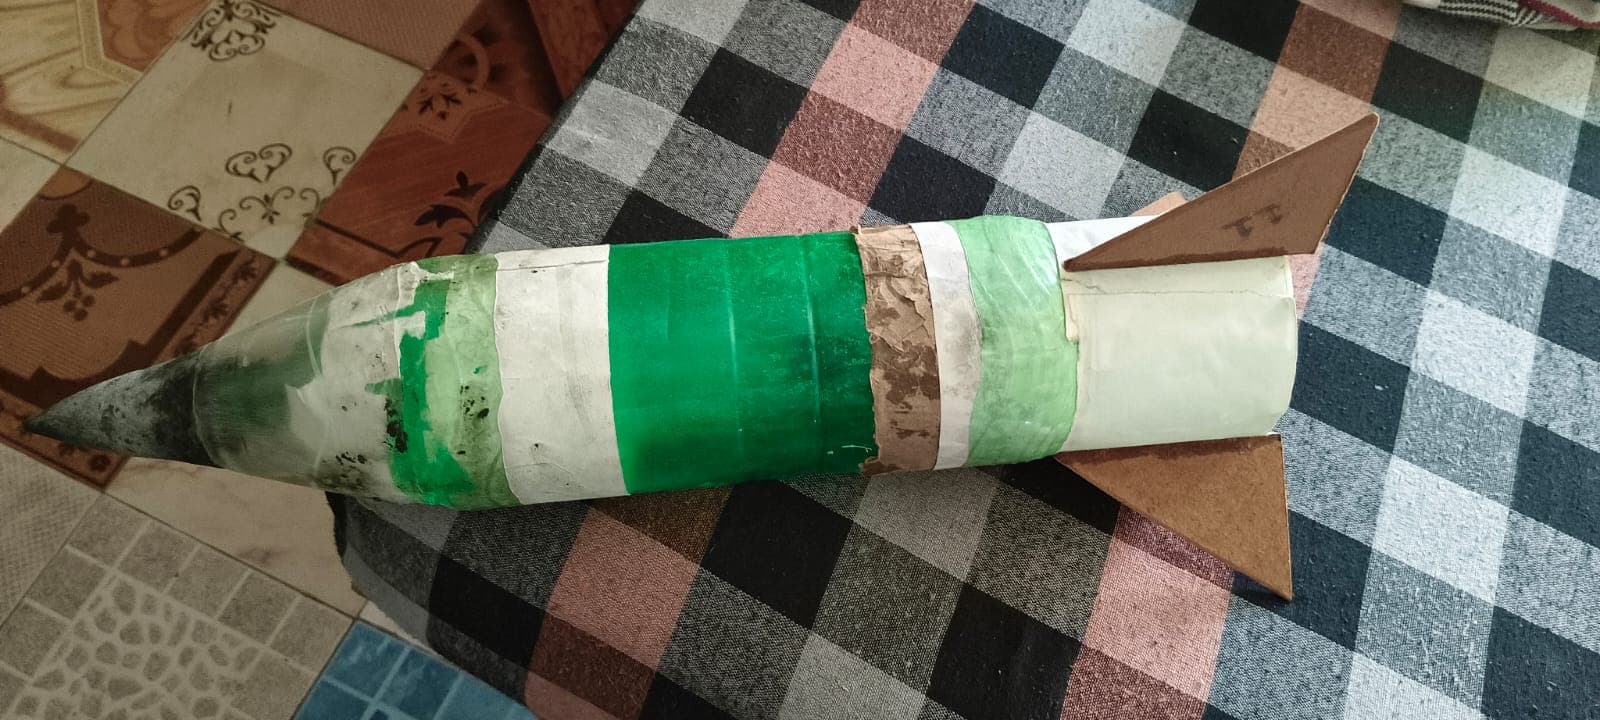
AerospaceYear 2026
Water Rocket
A pressurised water-and-air rocket engineered for maximum altitude and a clean recovery.
AerodynamicsPressure SystemsPrototyping
Water rocket on the launch pad
Overview
A hands-on introduction to thrust, pressure, and aerodynamics, our water rocket uses compressed air to expel water and launch skyward.
Highlights
- Optimised water-to-air pressure ratio
- Aerodynamic fins for a straight ascent
- Reinforced pressure bottle
- Reusable launch pad with remote release
The Challenge
Maximising altitude while keeping the flight straight required tuning fin placement.
The Outcome
Reached impressive heights in test launches and became a staple demo for younger students.
Project Media & Build Gallery
[1 PHOTOS]Water rocket on the launch pad
More Projects
 Autonomous Systems
2026
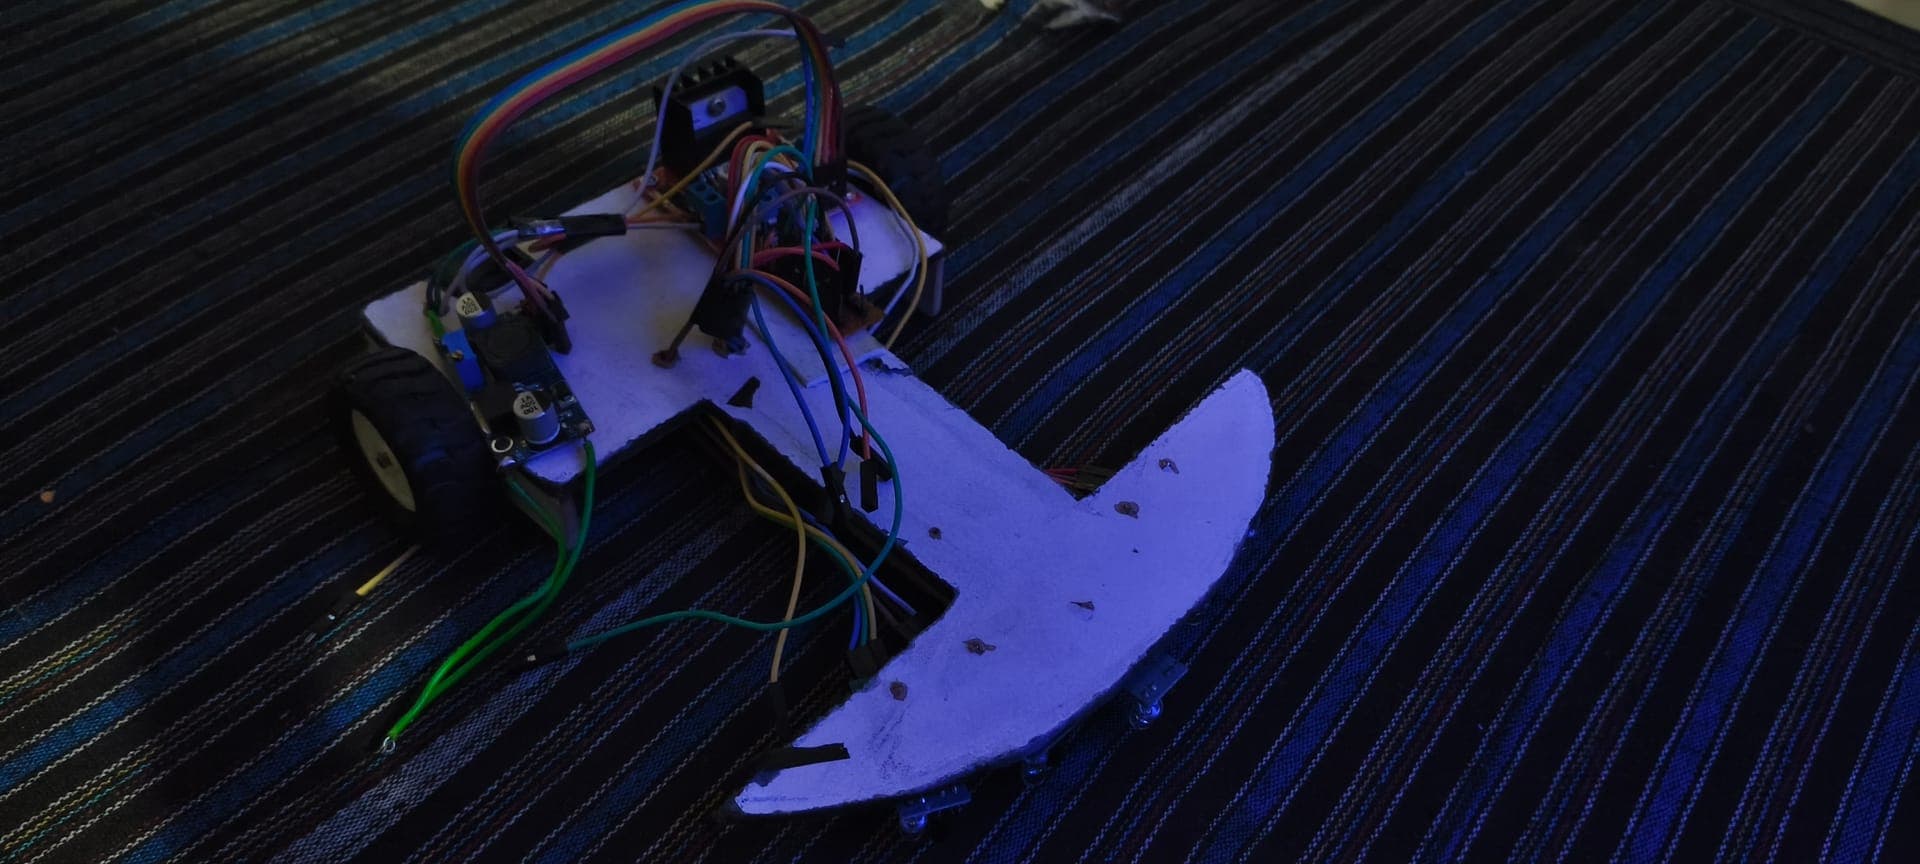
Autonomous 5-Channel IR Line Follower Robot
An autonomous line follower robot with a 5-channel TCRT5000 IR sensor array, L298N differential drive, and PID weighted error logic for smooth trajectory execution.
Why we built this
Standard 2-IR followers produce harsh, jerky turns. We engineered this 5-IR system so students could master proportional-derivative (PID) feedback control on affordable hardware.
Free technical report & Drive guide available
 Human-Machine Interface
2026
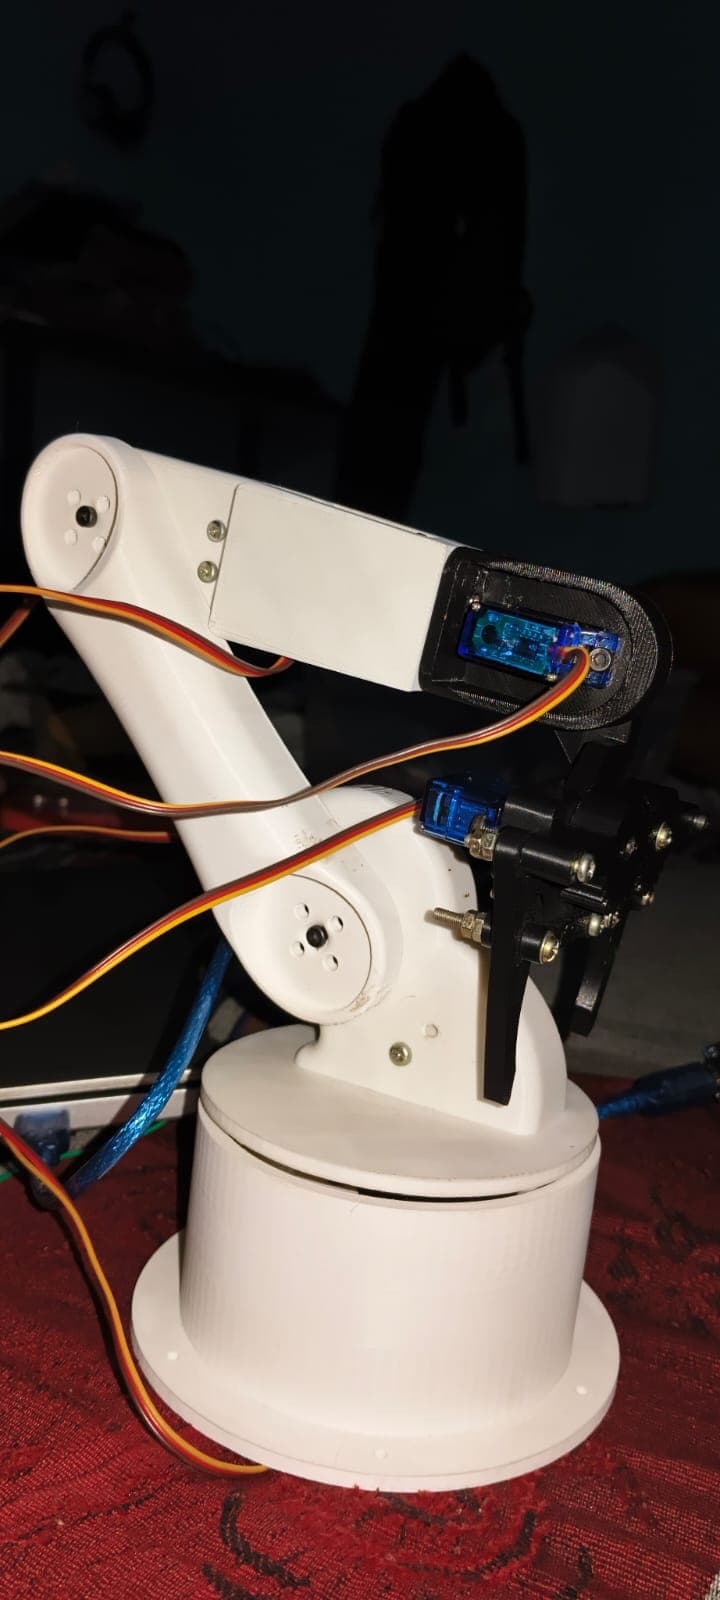
6-DOF CyberDeck & 5-DOF Teach-Repeat Robotic Arm
Industrial-grade 6-DOF & 5-DOF robotic manipulation systems featuring OpenCV AI vision hand tracking, Flask-SocketIO web control, and teach-repeat trajectory playback.
Why we built this
Industrial robot arms are typically locked behind proprietary software; we designed an open hardware ecosystem combining AI computer vision, web dashboards, and manual potentiometer teach modes.
Free technical report & Drive guide available
 Renewable Energy Systems
2026
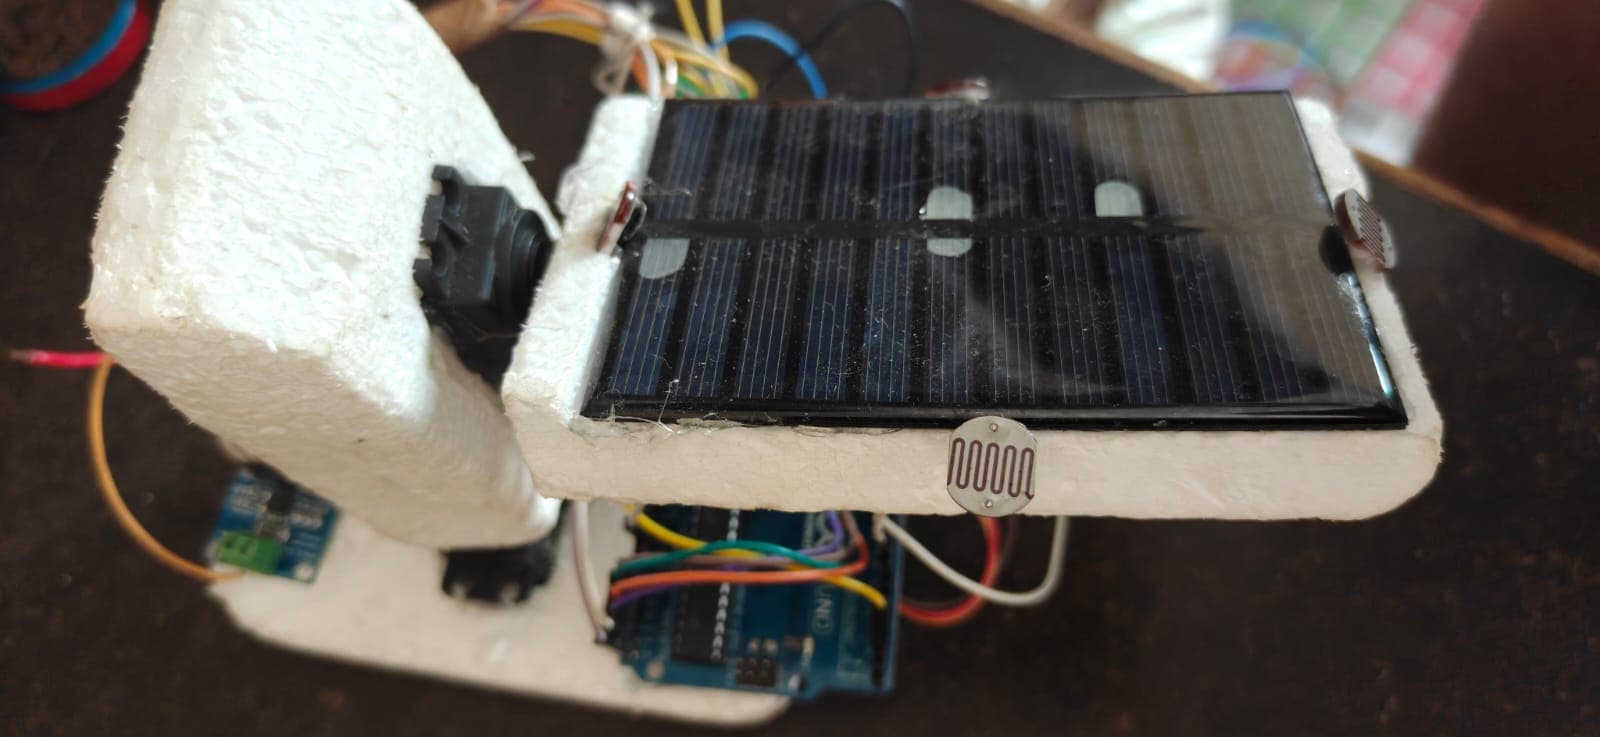
Dual-Axis Solar Tracking & Energy Management System
A dual-axis (Yaw & Pitch) photovoltaic tracking system equipped with high-side INA219 I2C current/voltage telemetry, DHT22 climate sensors, and closed-loop battery charging.
Why we built this
Stationary solar panels suffer significant efficiency drops; we built an intelligent dual-axis tracker that maximizes energy capture while monitoring real-time power metrics.
Free technical report & Drive guide available